
Sine–Cosine Track for a Swinging Spring Pendulum
Loading the math board and drawing, please wait…
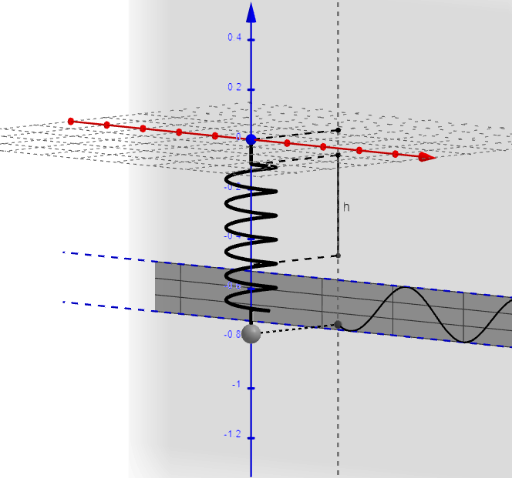
This example visualizes a swinging spring pendulum as a dynamic, time-parameterized geometric construction, emphasizing the periodic nature of its motion and the resulting track/trajectory. It centers on sine and cosine relationships (amplitude and phase), coordinate geometry with parameterized points and Cartesian curves, and the way the path evolves as the time variable t changes. The construction uses GeoGebra commands such as Point (to define key moving and fixed points like D, P_1, P_2), If (to switch or clamp behavior under conditions), CurveCartesian (to generate the main trajectory curve in the coordinate plane, including forms like spiral-related paths), Segment (to draw connecting mechanical links), Sphere (for 3D geometric components), IntersectPath and Surface (to form intersections/trimmed geometric sets related to the moving configuration), plus Text objects for labeling parameters. The resulting interactive model is suitable for high school and early university learners studying trigonometry, analytic/coordinate geometry, and visual math modeling of periodic motion, especially in math–physics crossovers.
GeoGebra Commands & Parameters
Point(zAxis) → P_1If(m ≠ 0, h + x_1 + (Ampl * sin((ω * t))), h + x_1) → h_1CurveCartesian((r * cos((s * ((12 * pi)) / h_1))), (r * sin((s * ((12 * pi)) / h_1))), z(P_2) - s, s, 0, h_1) → spiralSegment(P_3, P_2) → iSegment(P_2, P_1) → jSegment(P_5, P_4) → gSphere(P_6, (0.05 * cbrt(m))) → aSegment(P_5, P_6) → lIntersectPath(e_1, b) → nSegment(P_6, A) → pIntersectPath(b, e) → qIntersectPath(e_2, b) → f_1IntersectPath(e_3, b) → g_1CurveCartesian(tt, 0.5, (-h) - x_1 - 0.2 + (Ampl * sin((ω * (tt - t)))), tt, 0, (4 * pi)) → SchwSurface(u + t, 0.5, (-h) - x_1 - 0.2 + (v * Ampl), u, -20, 20, v, -1, 1) → streifSegment(P_1, D) → sSegment(B, C) → dSegment(P_2, B) → i_1Segment(P_2 - (0, 0, h), C) → j_1
AI Drawing Prompt Reference
Draw a dynamic swinging spring pendulum with a fixed suspension point, a spring link, and a bob that moves in 3D space leaving a spiral trajectory. The spiral curve should have radius and height modulated by sine functions of time. Include connecting segments for the spring and rods, a sphere for the bob, and several intersection curves between auxiliary planes and surfaces. Add a horizontal sine wave reference line. Show the periodic nature of motion with labeled parameters.
The prompt above was compiled from the original drawing commands and is for reference only.