
Shearer Dynamic Geometry Demo
Loading the math board and drawing, please wait…
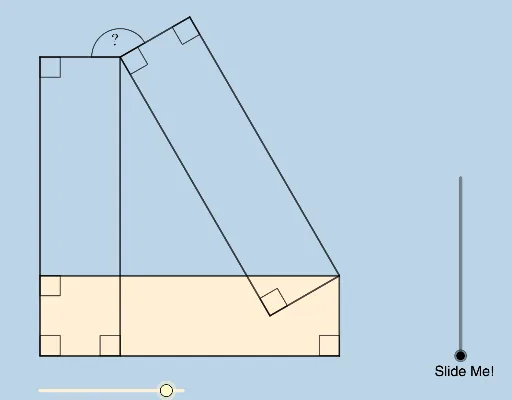
This example dynamically illustrates a geometric transformation problem posted by Catriona Shearer, involving core math concepts like rectangles, algebra, binomial distribution, LCM and GCD, quadrilaterals, and combinatorics. It is constructed using GeoGebra commands such as Intersect, Rotate, Ray, OrthogonalLine, Polygon, Distance, Circle, Segment, Angle, Dilate, Vector, Translate, and CircleSector, making it suitable for high school and above learners to explore complex geometric constructions and dynamic changes.
GeoGebra Commands & Parameters
Intersect(xAxis, yAxis) → ARotate(F, (-(15°)), A) → F'_1Ray(A, F'_1) → fOrthogonalLine(F'_1, yAxis) → gIntersect(g, yAxis) → HOrthogonalLine(D, yAxis) → hIntersect(h, yAxis) → IPolygon(A, B, D, I) → q1, a_1, b_1, d, iDistance(A, F'_1) → cCircle(D, Distance[D, B]) → eSegment(H, A) → qSegment(A, B) → rSegment(H, F'_1) → sSegment(F'_1, E) → tSegment(I, D) → f_1Segment(D, B) → g_1Segment(A, D) → jPolygon(A, D, 3) → poly1, k, l, m, CCircle(D, s) → pRotate(D, (-(15°)), C) → D'Rotate(D, 75°, C) → D'_1Segment(F'_1, D'_1) → nRay(F'_1, D') → bOrthogonalLine(D, b) → h_1Intersect(h_1, b) → JOrthogonalLine(D, h_1) → i_1Intersect(i_1, n) → KSegment(F'_1, J) → j_1Segment(J, D) → k_1Segment(D, K) → l_1Segment(K, F'_1) → m_1Angle(K, F'_1, H) → αAngle(j_1, f_1) → βRotate(A, If[0 < o ≤ 1, ((-o) * π / 3), ((-π)) / 3], D) → A'Rotate(B, If[0 < o ≤ 1, ((-o) * π / 3), ((-π)) / 3], D) → B'Rotate(D, If[0 < o ≤ 1, ((-o) * π / 3), ((-π)) / 3], D) → D'_2Rotate(I, If[0 < o ≤ 1, ((-o) * π / 3), ((-π)) / 3], D) → I'Polygon(A', B', D'_2, I') → q1', a', b', d'_2, i'Dilate(J, If[2 < o ≤ 3, 3 - o, 0], A) → J'Vector(J, J') → uTranslate(A', u) → A''Translate(B', u) → B''Translate(D'_2, u) → GTranslate(I', u) → I''Polygon(A'', B'', G, I'') → q1'', a'', b'', g_2, i''Rotate(A'', If[2 < o ≤ 3, ((-(o - 2)) * π / 6), ((-π)) / 6], B'') → A'''Rotate(B'', If[2 < o ≤ 3, ((-(o - 2)) * π / 6), ((-π)) / 6], B'') → B'''Rotate(G, If[2 < o ≤ 3, ((-(o - 2)) * π / 6), ((-π)) / 6], B'') → G'Rotate(I'', If[2 < o ≤ 3, ((-(o - 2)) * π / 6), ((-π)) / 6], B'') → I'''Polygon(A''', B''', G', I''') → q1''', a''', b''', g', i'''Angle(B, A, H) → γAngle(A, I, D) → δAngle(J, F'_1, K) → εAngle(I, H, F'_1) → ζAngle(F'_1, K, D) → ηAngle(D, B, A) → θAngle(D, J, F'_1) → ιIntersect(f_1, j_1) → LIntersect(t, f_1) → MCircle(L, Distance[M, L] / 2) → c_1Angle(F'_1, E, A) → κIntersect(c_1, f_1, 1) → NRotate(N, ((-π)) / 6, L) → N'Ray(L, N') → n_1Circle(L, (2 * Radius[c_1])) → d_1Intersect(d_1, n_1, 1) → ODilate(L, If[4 < o ≤ 5, 5 - o, 0], O) → L'Rotate(N, If[4 < o ≤ 5, ((-(o - 4)) * π / 6), ((-π)) / 6], L) → N'_1Segment(L, L') → p_1CircleSector(L, N'_1, N) → e_1Rotate(e_1, If[6 < o ≤ 7, ((-(o - 6)) * π / 6), ((-π)) / 6], L) → q_1Dilate(L, If[8 < o ≤ 9, 9 - o, 0], C) → L'_1Vector(L, L'_1) → vTranslate(q_1, v) → r_1Rotate(r_1, If[8 < o ≤ 9, (((o - 8) * 5) * π / 6), (5 * π / 6)], L'_1) → s_1