
Rotation and Similar Triangles Animation
Loading the math board and drawing, please wait…
In collections
Congruence (CO) Cluster
Congruence (Vol 2)
CCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
Gail LeBlancCCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
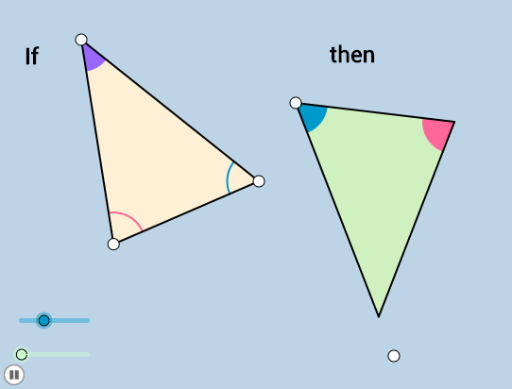
This example demonstrates the application of rotation transformations in similar triangles. Key mathematical concepts include the properties of similar triangles and rotation transformations. Using GeoGebra commands such as Rotate, Polygon, and Dilate, the animation dynamically shows the similarity relationship between the pre- and post-rotation triangles. Suitable for students at the junior high school level and above to learn about the properties and transformations of similar triangles.
GeoGebra Commands & Parameters
Ray(E, L) → lPoint(l) → MRotate(M, α, E) → M'Ray(E, M') → mPoint(y = 0) → ASegment(A, C) → jRotate(C, α, A) → C'Ray(A, C') → gPoint(g) → DSegment(A, D) → iSegment(D, C) → hRay(A, C) → fAngle(C, A, C') → βPolygon(A, C, D) → poly1, d, a, cAngle(M, E, M') → γCircle(E, i) → eCircle(E, j) → kIntersect(k, l, 1) → FIntersect(e, m, 1) → GCircle(G, 1) → pCircle(F, 1) → qCircle(G, h) → rIntersect(r, l) → H, UDilate(G, b, E) → G'Dilate(H, b, E) → H'Segment(G', H') → nPolygon(E, H', G') → poly2, g', e_1, h'Angle(poly2) → δ, ε, ζAngle(poly1) → η, θ, ιSegment(E, H') → sSegment(E, G') → tMin({j, i, h}) → oCircle(A, (0.2 * o)) → c_1Circle(D, (0.2 * o)) → d_1Circle(C, (0.2 * o)) → f_1Intersect(c_1, j, 1) → IIntersect(c_1, i, 1) → JIntersect(d_1, i, 1) → KIntersect(d_1, h, 1) → NIntersect(f_1, h, 1) → OIntersect(j, xAxis) → PIntersect(f_1, j, 1) → QCircleSector(A, I, J) → g_1CircleSector(D, K, N) → h_1CircleSector(C, O, Q) → k_1Dilate(A, If[0 < u ≤ 1, 1 - u, 0], E) → A'Vector(A, A') → vTranslate(g_1, v) → p_1Line(A, t) → i_1Point(i_1) → RAngle(D, A, R) → κRotate(p_1, If[1 < u ≤ 2, ((u - 1) * κ), κ], E) → q_1Dilate(D, If[2 < u ≤ 3, 3 - u, 0], G') → D'Vector(D, D') → wTranslate(h_1, w) → r_1Line(D, n) → j_1Point(j_1) → SAngle(N, D, S) → λRotate(r_1, If[3 < u ≤ 4, ((u - 3) * λ), λ], G') → s_1Dilate(C, If[6 < u ≤ 7, 7 - u, 0], H') → C'_1Vector(C, C'_1) → u_1Translate(k_1, u_1) → t_1Line(C, s) → l_1Point(l_1) → TAngle(A, C, T) → μRotate(t_1, If[7 < u ≤ 8, ((u - 7) * μ), μ], H') → c_2CircleArc(A, I, J) → d_2CircleArc(D, K, N) → e_2CircleArc(C, O, Q) → f_2