
Exploring Quadrilateral Angle Sums by Tim Brzezinski
Loading the math board and drawing, please wait…
In collections
Unit 7: Polygons and Quadrilaterals
Quadrilaterals
Polygons & Angles
Polygons & Angles
Polygons & Angles ( s n attar)
Polygons & Angles
Polygons & Angles
Polygons & Angles
Geometry: Polygons & Angles
Polygons & Angles
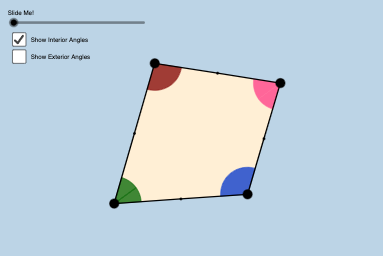
This applet demonstrates how students can discover the sum of the interior and exterior angles of a quadrilateral using transformations. Key math concepts include quadrilaterals, angle measurement, and geometric transformations. It utilizes commands like Ray, Point, Circle, Intersect, Segment, Angle, CircleSector, Vector, Translate, Dilate, If, Line, Polygon, Rotate, Mirror, Midpoint, CircleArc. Suitable for middle school and above to understand quadrilateral angle properties and enhance spatial reasoning.
GeoGebra Commands & Parameters
Ray(P, A) → h_1Point(h_1) → RRay(A, R) → j_1Ray(A, B) → aCircle(A, 1.5) → gIntersect(g, j_1) → I_1,Intersect(g, a, 1) → HSegment(P, A) → l_1Intersect(g, l_1, 1) → H_1Segment(P, C) → k_1Circle(C, 1.5) → kIntersect(k, k_1) → Z,Ray(B, C) → bIntersect(k, b) → M, NPoint(a) → D_1Point(b) → E_1Ray(B, D_1) → eRay(C, E_1) → fPoint(e) → DPoint(f) → EAngle(A, C, B) → γAngle(D, B, C) → εAngle(E, C, A) → ζCircle(B, 1.5) → hIntersect(h, b, 1) → JIntersect(h, a, 1) → KIntersect(h, a, 2) → LCircleSector(B, J, K) → qCircleSector(B, L, J) → tVector(B, C) → uCircleSector(A, I_1, H) → c_1Vector(A, C) → vTranslate(q, u) → q'Segment(B, C) → lDilate(C, If[0 < j ≤ 1, j, 0], B) → C'Vector(B, C') → wTranslate(q, w) → q'_1Dilate(A, If[1 < j ≤ 2, 2 - j, 0], C) → C'_1Vector(A, C'_1) → mDilate(C, If[0 < n ≤ 1, n, 0], B) → C'_2Dilate(A, If[1 < n ≤ 2, 2 - n, 0], C) → A'Vector(B, C'_2) → u_1Vector(A, A') → v_1If(0 < n ≤ 1, Translate[t, u_1], Translate[t, u]) → e_1If(1 < n ≤ 2, Translate[c_1, v_1], Translate[c_1, v]) → f_1Ray(C, P) → g_1Point(g_1) → QRay(P, Q) → i_1Point(i_1) → SPoint(j_1) → TCircle(P, 1.5) → p_1Intersect(p_1, l_1) → U,Intersect(p_1, i_1) → V,Intersect(p_1, k_1) → W,CircleSector(P, U, W) → q_1Intersect(k, b, 2) → A_1Line(P, b) → b_1Intersect(p_1, b_1) → C_1, G_1Angle(B, A, P) → αVector(P, C) → iDilate(P, If[2 < j ≤ 3, 3 - j, 0], C) → P'Vector(P, P') → w_1Translate(q_1, w_1) → r_1CircleSector(C, N, Z) → sCircleSector(P, V, U) → t_1Dilate(P, If[2 < n ≤ 3, 3 - n, 0], C) → P'_1Vector(P, P'_1) → m_1If(2 < n ≤ 3, Translate[t_1, m_1], Translate[t_1, w_1]) → e_2Angle(H, A, I_1) → δAngle(V, P, U) → ηAngle(U, P, W) → θPolygon(A, B, C, P) → poly1, a_2, b_2, c_2, p_2Segment(A, C) → n_1Intersect(g, n_1) → F,Intersect(k, n_1) → G,Line(P, n_1) → cLine(B, n_1) → dCircleSector(C, Z, G) → d_1CircleSector(C, G, M) → s_1CircleSector(A, H, F) → d_2If(0 < j ≤ 1, Dilate[C, 1 - j, B]) → IIf(1 < j ≤ 2, Dilate[A, 2 - j, P]) → OIf(1 < j ≤ 2, Dilate[C, 2 - j, P]) → B_1Vector(C, I) → rVector(A, O) → u_2Translate(s_1, r) → h_2Rotate(d_2, 180°, A) → k_2Vector(A, B) → v_2Vector(C, B) → w_2Translate(s_1, w_2) → s_2Mirror(s_2, B) → t_2Vector(A, P) → i_2Vector(C, P) → j_2CircleSector(A, F, H_1) → f_2Translate(f_2, i_2) → d_3Vector(C, B_1) → l_2Translate(d_1, j_2) → f_3Mirror(f_3, P) → g_3Translate(f_2, u_2) → h_3Translate(d_1, l_2) → k_3Segment(A, B) → m_2Polygon(A, B, C) → poly2, c_4, a_3, b_3Polygon(A, C, P) → poly3, p_4, a_4, c_5Midpoint(m_2) → M_4Midpoint(l) → J_1Midpoint(k_1) → M_2Midpoint(l_1) → M_3Segment(J, C) → n_2Segment(J_1, C) → i_3Rotate(J_1, If[0 < j ≤ 1, ((-j) * 180°), -180°], J_1) → M_1Rotate(C, If[0 < j ≤ 1, ((-j) * 180°), -180°], J_1) → C'_3Segment(M_1, C'_3) → j_3Rotate(s_1, If[0 < j ≤ 1, ((-j) * 180°), -180°], J_1) → r_3Segment(J_1, B) → r_2Rotate(d_2, If[0 < j ≤ 1, (j * 180°), 180°], M_4) → pRotate(A, If[0 < j ≤ 1, (j * 180°), 180°], M_4) → A'_1Segment(M_4, A'_1) → g_2Rotate(C, If[1 < j ≤ 2, ((j - 1) * 180°), 180°], M_2) → C'_4Segment(M_2, C'_4) → q_2Rotate(d_1, If[1 < j ≤ 2, ((j - 1) * 180°), 180°], M_2) → c_3Rotate(A, If[1 < j ≤ 2, ((-(j - 1)) * 180°), 180°], M_3) → A'_2Segment(M_3, A'_2) → e_3Rotate(f_2, If[1 < j ≤ 2, ((-(j - 1)) * 180°), 180°], M_3) → p_3CircleArc(C, G, M) → q_3CircleArc(A, H, F) → s_3CircleArc(C, Z, G) → t_3CircleArc(A, F, H_1) → d_4Segment(M_2, C) → l_3Segment(M_2, P) → m_3Segment(P, M_3) → n_3Segment(M_3, A) → b_4Segment(A, M_4) → e_4Segment(M_4, B) → f_4