
Dandelin Sphere Demonstration
Loading the math board and drawing, please wait…
In collections
GeoGebra 3D & AR: PreCalc & Calculus Resources
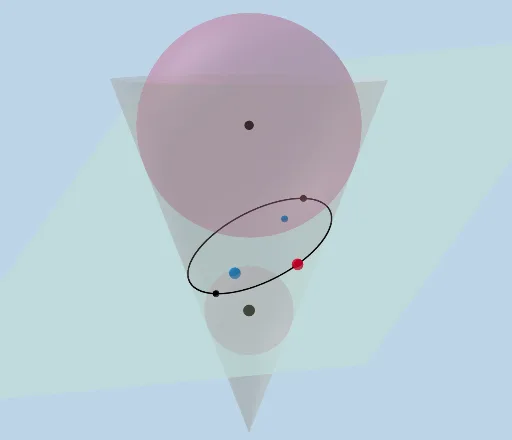
This example demonstrates the dynamic process of Dandelin spheres. Key mathematical concepts include the intersection of cones and spheres in solid geometry. Using various GeoGebra commands such as constructing cones, spheres, and rotations, it visually illustrates how Dandelin spheres help understand the properties of conic sections. Suitable for high school geometry and solid geometry courses.
GeoGebra Commands & Parameters
Cone(B_2, A_2, r) → a, c, bSegment((0, 0, 0), (0, 0, 10)) → fPoint(f) → ASegment(A, (0, 0, 10)) → gLine(A_2, C) → iDistance(A, i) → dSphere(A, d) → ePointIn(e) → HLine(A, H) → jVector(A, H) → uOrthogonalLine(H, u, xOyPlane) → kRotate(k, π / 2, j) → k'Sphere(H, 2) → lIntersect(k', l) → I, JIntersect(k, l) → K, LPlane(J, L, K) → mIntersectPath(m, a) → pFocus(p) → O, POrthogonalLine(P, m) → qLine((0, 0, 0), (0, 0, 1)) → sIntersect(s, q) → BSphere(B, P) → oPoint(p) → MVertex(p) → N, R, S, TIntersectPath(t, o) → c_1IntersectPath(v, e) → d_1Line(A_2, M) → f_1Intersect(f_1, e) → U, VIntersect(f_1, o) → W, ZDilate(A_2, If[0 < w ≤ 1, 1 - w, 0], U) → A'Segment(A_2, A') → g_1Dilate(U, If[1 < w ≤ 2, 2 - w, 0], M) → U'Segment(U, U') → h_1Dilate(M, If[2 < w ≤ 3, 3 - w, 0], W) → M'Segment(M, M') → i_1Angle(H, M, U) → αRotate(U, If[4 < w ≤ 5, ((w - 4) * α), α], M, Plane[M, U, H]) → U'_1Rotate(U', If[4 < w ≤ 5, ((w - 4) * α), α], M, Plane[M, U, H]) → U''Segment(U'_1, U'') → j_1Angle(P, M, W) → βRotate(M, If[5 < w ≤ 6, ((-(w - 5)) * β), (-β)], M, Plane[P, W, M]) → M'_1Rotate(M', If[5 < w ≤ 6, ((-(w - 5)) * β), (-β)], M, Plane[P, W, M]) → M''Segment(M'_1, M'') → k_1Line(N, R) → l_1Sphere(N, j_1) → a_1Intersect(l_1, a_1) → A_1, B_1Dilate(H, If[7 < w ≤ 8, 8 - w, 0], N) → H'Vector(H, H') → u_1Translate(U'_1, u_1) → C_1Translate(U'', u_1) → U'''Segment(C_1, U''') → m_1Angle(M, H, R) → γRotate(C_1, If[7 < w ≤ 8, ((-(w - 7)) * γ), (-γ)], H', Plane[H', R, M]) → D_1Rotate(U''', If[7 < w ≤ 8, ((-(w - 7)) * γ), (-γ)], H', Plane[H', R, M]) → E_1Segment(D_1, E_1) → n_1Dilate(P, If[8 < w ≤ 9, 9 - w, 0], R) → P'Vector(P, P') → v_1Translate(M'_1, v_1) → F_1Translate(M'', v_1) → M'''Segment(F_1, M''') → p_1Angle(N, P, M) → δRotate(F_1, If[8 < w ≤ 9, ((w - 8) * δ), δ], P', Plane[N, R, M]) → G_1Rotate(M''', If[8 < w ≤ 9, ((w - 8) * δ), δ], P', Plane[N, R, M]) → H_1Segment(G_1, H_1) → q_1
AI Drawing Prompt Reference
Create a 3D geometric demonstration showing a cone intersected by a plane, with two spheres (Dandelin spheres) tangent to the cone and the plane. The cone has a vertical axis, and the plane cuts through it forming an ellipse. The two spheres are placed inside the cone, each tangent to the cone's lateral surface and to the plane, with their tangency points on the plane being the foci of the ellipse. Include auxiliary lines, segments, and dynamic elements such as rotating points and moving segments to illustrate the construction. Show the cone, spheres, plane, ellipse, and relevant points, lines, and angles in a clear spatial arrangement.
The prompt above was compiled from the original drawing commands and is for reference only.