
9-Point Circle Action (Part 2): Circumradius is Double the Nine-Point Radius
Loading the math board and drawing, please wait…
In collections
CCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
CCSS High School: Geometry (Congruence) Volume 2
Triangle Theorems
Triangles: Points of Concurrency
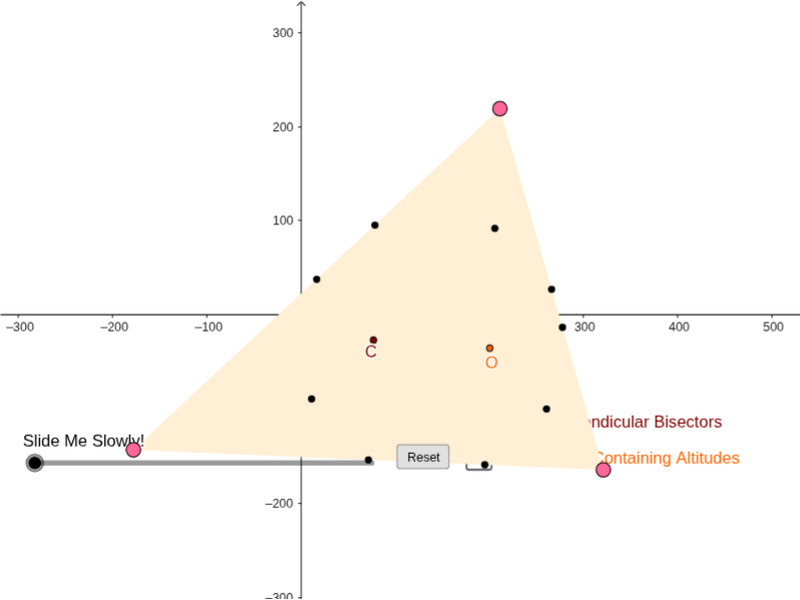
This dynamic geometry example visually demonstrates a fundamental theorem: the radius of a triangle's circumcircle is exactly twice the radius of its nine-point circle. The nine-point circle passes through the midpoints of the three sides, the feet of the three altitudes, and the midpoints of the segments from the orthocenter to each vertex. The construction uses GeoGebra commands including Line, Segment, Midpoint, OrthogonalLine, Intersect, Circle, Dilate, Rotate, Polygon, Point, Ray, CircleSector, Angle, CircleArc, Vector, and Translate to build the triangle, its circumcircle, the nine-point circle, and related points. This example is ideal for high school and college students and teachers exploring triangle geometry, circle properties, and visual proofs without words. It helps learners grasp the radius ratio and the relationship between the circumcenter, orthocenter, and nine-point center.
GeoGebra Commands & Parameters
Line(C, B) → l_1Segment(B, C) → gMidpoint(g) → F_3OrthogonalLine(F_3, l_1) → j_3Line(A, C) → f_1Segment(C, A) → hMidpoint(h) → E_3OrthogonalLine(E_3, f_1) → k_3Intersect(k_3, j_3) → I_2Midpoint(I_2, C) → I_3Segment(A, B) → fMidpoint(f) → D_3Min(list1) → aCircle(D_3, (0.15 * a)) → cCircle(E_3, (0.15 * a)) → dCircle(F_3, (0.15 * a)) → eIntersect(c, f, 2) → HIntersect(d, h, 2) → KIntersect(e, g, 2) → MDilate(A, If[0 < b ≤ 1, 1 - b, 0], D_3) → A'Dilate(B, If[2 < b ≤ 3, 3 - b, 0], F_3) → B'Dilate(C, If[4 < b ≤ 5, 5 - b, 0], E_3) → C'Segment(A, A') → lSegment(B, B') → mSegment(C, C') → nRotate(A, If[1 < b ≤ 2, ((b - 1) * π), π], D_3) → A'_1Rotate(A', If[1 < b ≤ 2, ((b - 1) * π), π], D_3) → A''Segment(A'_1, A'') → l'Rotate(B, If[3 < b ≤ 4, ((b - 3) * π), π], F_3) → B'_1Rotate(B', If[3 < b ≤ 4, ((b - 3) * π), π], F_3) → B''Segment(B'_1, B'') → m'Rotate(C, If[5 < b ≤ 6, ((b - 5) * π), π], E_3) → C'_1Rotate(C', If[5 < b ≤ 6, ((b - 5) * π), π], E_3) → C''Segment(C'_1, C'') → n'Polygon(A, B, C) → poly1, c_1, a_1, b_1Line(A, B) → iPoint(i) → C_3Point(i) → GOrthogonalLine(C, i) → jIntersect(i, j) → IRay(A, G) → kRay(B, C_3) → pPoint(k) → JPoint(p) → LCircle(I, (0.15 * a)) → sIntersect(s, i, 2) → NIntersect(s, j, 2) → O_3CircleSector(I, N, O_3) → tAngle(C, B, A) → αAngle(B, A, C) → βAngle(A, C, B) → γPoint(f_1) → PPoint(f_1) → QRay(A, P) → g_1Ray(C, Q) → h_1Point(g_1) → RPoint(h_1) → SOrthogonalLine(B, f_1) → k_1Intersect(f_1, k_1) → TCircle(T, (0.15 * a)) → d_1Intersect(d_1, f_1, 1) → UIntersect(d_1, k_1, 1) → VCircleSector(T, U, V) → e_1OrthogonalLine(A, l_1) → m_1Intersect(l_1, m_1) → WCircle(W, (0.15 * a)) → p_1Intersect(p_1, l_1, 1) → ZIntersect(p_1, m_1, 1) → A_1Point(l_1) → B_1Point(l_1) → D_1CircleSector(W, Z, A_1) → q_1Ray(C, B_1) → n_1Ray(B, D_1) → r_1Point(n_1) → E_1Point(r_1) → F_1Dilate(C, If[6 < b ≤ 7, 7 - b, 0], I) → G_1Segment(C, G_1) → f_2Dilate(B, If[7 < b ≤ 8, 8 - b, 0], T) → B'_2Segment(B, B'_2) → g_2Dilate(A, If[8 < b ≤ 9, 9 - b, 0], W) → A'_2Segment(A, A'_2) → h_2Intersect(k_1, m_1) → ODilate(I, If[12 < b ≤ 13, 13 - b, 0], O) → I'Dilate(A, If[12 < b ≤ 13, 13 - b, 0], O) → A'_3Dilate(T, If[12 < b ≤ 13, 13 - b, 0], O) → T'Segment(I, I') → i_2Segment(A, A'_3) → j_2Segment(T, T') → k_2Dilate(C, If[12 < b ≤ 13, 13 - b, 0], O) → I_1Dilate(W, If[12 < b ≤ 13, 13 - b, 0], O) → W'Dilate(T, If[12 < b ≤ 13, 13 - b, 0], O) → T'_1Segment(W, W') → l_2Segment(C, I_1) → m_2Segment(T, T'_1) → n_2Dilate(I, If[12 < b ≤ 13, 13 - b, 0], O) → I'_1Dilate(B, If[12 < b ≤ 13, 13 - b, 0], O) → B'_3Dilate(W, If[12 < b ≤ 13, 13 - b, 0], O) → W'_1Segment(B, B'_3) → p_2Segment(W, W'_1) → q_2Segment(I, I'_1) → r_2Midpoint(O, C) → FMidpoint(O, A) → DMidpoint(O, B) → EDilate(O, If[14 < b ≤ 15, 15 - b, 0], F) → M_1Dilate(F, If[15 < b ≤ 16, 16 - b, 0], C) → N_1Segment(F, N_1) → t_2Rotate(O, If[16 < b ≤ 17, ((b - 16) * π), π], F) → O_1Rotate(M_1, If[16 < b ≤ 17, ((b - 16) * π), π], F) → P_1Dilate(O, If[17 < b ≤ 18, 18 - b, 0], E) → Q_1Dilate(E, If[18 < b ≤ 19, 19 - b, 0], B) → R_1Segment(E, R_1) → e_2Rotate(O, If[19 < b ≤ 20, ((b - 19) * π), π], E) → S_1Rotate(Q_1, If[19 < b ≤ 20, ((b - 19) * π), π], E) → T_1Dilate(O, If[20 < b ≤ 21, 21 - b, 0], D) → U_1Dilate(D, If[21 < b ≤ 22, 22 - b, 0], A) → V_1Segment(D, V_1) → h_3Rotate(O, If[22 < b ≤ 23, ((b - 22) * π), π], D) → W_1Rotate(U_1, If[22 < b ≤ 23, ((b - 22) * π), π], D) → Z_1Intersect(e, l_1) → A_2, B_2Intersect(e, j_3) → C_2, D_2CircleSector(F_3, A_2, C_2) → c_3Circle(E_3, (0.15 * a)) → d_3Intersect(d_3, k_3) → E_2, F_2Intersect(d_3, f_1) → G_2, H_2CircleSector(E_3, G_2, E_2) → e_3Midpoint(O, I_2) → J_2Dilate(O, If[28 < b ≤ 29, 29 - b, 0], J_2) → K_2Dilate(J_2, If[29 < b ≤ 30, 30 - b, 0], I_2) → L_2Rotate(O, If[30 < b ≤ 31, ((b - 30) * π), π], J_2) → M_2Rotate(K_2, If[30 < b ≤ 31, ((b - 30) * π), π], J_2) → N_2Dilate(J_2, If[31 < b ≤ 32, 32 - b, 0], D_3) → O_2Rotate(J_2, If[32 < b ≤ 34, ((b - 32) * π), (2 * π)], J_2) → P_2Rotate(O_2, If[32 < b ≤ 34, ((b - 32) * π), (2 * π)], J_2) → Q_2Segment(P_2, Q_2) → s_3CircleArc(J_2, D_3, Q_2) → t_3Circle(J_2, D_3) → c_4Point(j) → R_2Point(j) → S_2Ray(C, R_2) → j_4Ray(I, S_2) → k_4Point(j_4) → T_2Point(k_4) → U_2Angle(B, T, C) → δAngle(C, I, A) → εAngle(A, W, B) → ζAngle(I_2, E_3, C) → ηAngle(I_2, D_3, A) → θAngle(I_2, F_3, B) → ιLine(I_2, D_3) → s_2Line(A, W) → a_2Line(C, I) → b_2Line(B, T) → c_2Dilate(I_2, If[0 < v ≤ 1, 1 - v, 0], J_2) → C_1Segment(I_2, C_1) → d_2Dilate(J_2, If[1 < v ≤ 2, 2 - v, 0], O) → H_1Segment(J_2, H_1) → f_3Rotate(I_2, If[2 < v ≤ 3, ((v - 2) * π), π], J_2) → K_1Rotate(C_1, If[2 < v ≤ 3, ((v - 2) * π), π], J_2) → V_2Segment(K_1, V_2) → g_3Dilate(J_2, If[3 < v ≤ 4, 4 - v, 0], D_3) → W_2Segment(J_2, W_2) → i_3Rotate(J_2, If[4 < v ≤ 6, ((v - 4) * π), (2 * π)], J_2) → Z_2Rotate(W_2, If[4 < v ≤ 6, ((v - 4) * π), (2 * π)], J_2) → A_3Segment(Z_2, A_3) → l_3CircleArc(J_2, D_3, A_3) → p_3Dilate(I_2, If[6 < v ≤ 7, 7 - v, 0], I_3) → L_1Dilate(I_3, If[7 < v ≤ 8, 8 - v, 0], C) → B_3Segment(I_2, L_1) → m_3Segment(I_3, B_3) → n_3Dilate(J_2, If[8 < v ≤ 9, 9 - v, 0], I_2) → G_3Vector(J_2, G_3) → wTranslate(Z_2, w) → H_3Translate(A_3, w) → J_3Segment(H_3, J_3) → q_3Rotate(H_3, If[9 < v ≤ 10, ((v - 9) * π), π], I_2) → K_3Rotate(J_3, If[9 < v ≤ 10, ((v - 9) * π), π], I_2) → L_3Segment(K_3, L_3) → r_3Rotate(K_3, If[10 < v ≤ 11, ((v - 10) * π), π], I_3) → M_3Rotate(L_3, If[10 < v ≤ 11, ((v - 10) * π), π], I_3) → N_3Segment(M_3, N_3) → g_4Midpoint(I_2, A) → R_3Midpoint(I_2, B) → S_3Dilate(I_2, If[6 < v ≤ 7, 7 - v, 0], R_3) → U_3Dilate(I_2, If[6 < v ≤ 7, 7 - v, 0], S_3) → W_3Segment(I_2, U_3) → a_3Segment(I_2, W_3) → b_3Dilate(R_3, If[7 < v ≤ 8, 8 - v, 0], A) → J_1Dilate(S_3, If[7 < v ≤ 8, 8 - v, 0], B) → B_4Segment(R_3, J_1) → f_4Segment(S_3, B_4) → h_4Line(J_2, a_3) → i_4Dilate(J_2, If[11 < v ≤ 12, 12 - v, 0], I_2) → D_4Vector(J_2, D_4) → u_1Translate(Z_2, u_1) → G_4Translate(A_3, u_1) → H_4Segment(G_4, H_4) → l_4Angle(D, J_2, D_3) → μRotate(G_4, If[12 < v ≤ 13, ((-(v - 12)) * μ), (-μ)], I_2) → P_3Rotate(H_4, If[12 < v ≤ 13, ((-(v - 12)) * μ), (-μ)], I_2) → Q_3Segment(P_3, Q_3) → m_4Rotate(P_3, If[13 < v ≤ 14, ((-(v - 13)) * π), (-π)], R_3) → T_3Rotate(Q_3, If[13 < v ≤ 14, ((-(v - 13)) * π), (-π)], R_3) → V_3Segment(T_3, V_3) → n_4Dilate(J_2, If[14 < v ≤ 15, 15 - v, 0], I_2) → Z_3Vector(J_2, Z_3) → v_1Translate(Z_2, v_1) → A_4Translate(A_3, v_1) → C_4Segment(A_4, C_4) → p_4Line(J_2, b_3) → q_4Angle(D_3, J_2, E) → κRotate(A_4, If[15 < v ≤ 16, ((v - 15) * κ), κ], I_2) → E_4Rotate(C_4, If[15 < v ≤ 16, ((v - 15) * κ), κ], I_2) → F_4Segment(E_4, F_4) → r_4Rotate(E_4, If[16 < v ≤ 17, ((v - 16) * π), π], S_3) → I_4Rotate(F_4, If[16 < v ≤ 17, ((v - 16) * π), π], S_3) → J_4Segment(I_4, J_4) → s_4Circle(I_2, C) → d_4Rotate(B, If[17 < v ≤ 19, ((v - 17) * π), (2 * π)], I_2) → B'_4CircleArc(I_2, B, B'_4) → e_4Line(B, C) → qLine(A, C) → rLine(B, A) → i_1