
三维自行车模型
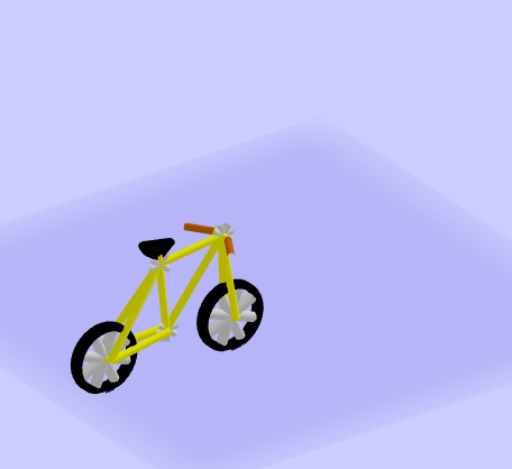
几何画板及绘图内容加载中,请稍等……
①本范例演示了如何在三维空间中构建自行车模型,灵感来源于四维框架操作工具;②涉及的核心数学概念包括向量、三角函数、解析几何和立体几何;③作图要点提炼自构造摘要,使用了Line(线)、Vector(向量)、Circle(圆)、Translate(平移)、Rotate(旋转)等GeoGebra命令和对象;④适合高中及以上学生学习和教师教学使用。
GeoGebra 命令及参数
Line(D, yAxis) → iOrthogonalLine(D, yAxis, space) → bIntersect(i, b) → SCircle(I, (0.3 * r), yAxis) → ePlane(e) → jLine(I, G) → cOrthogonalLine(I, c, j) → lIntersect(l, e) → O, PLine(I, O) → q_1Intersect(xAxis, q_1) → TVector(T, I) → u_1Circle(I, r, u_1) → p_2Vector(S, T) → vCircle(D, (0.25 * r), zAxis) → hIntersect(i, h) → B, FTranslate(F, v) → F'_1Translate(F'_1, u_1) → E_2Midpoint(I, E_2) → G_2Circle(D, E, space) → fCircle(D, (0.8 * r), yAxis) → gIntersect(xAxis, zAxis) → CPolygon(F, G, A) → poly1, a_1, f_1, g_1Polygon(A, H, G) → poly2, g_2, a_2, h_1Polygon(I, A, G) → poly3, g_3, i_1, a_3Intersect(i, g_1) → JPlane(F, G, A) → dPlane(e) → kIntersect(c, e) → K, LAngularBisector(l, c) → m, nIntersect(m, e) → M, NIntersect(n, e) → Q, RSegment(R, Q) → pSegment(P, O) → qSegment(M, N) → sSegment(K, L) → tSegment(K, L) → b_1Line(G, q_1) → c_1Line(I, M) → d_1Vector(S, A) → uSegment(B, F) → e_1Translate(g, v) → g'Translate(B, u) → B'Translate(F, u) → F'Segment(B', F') → j_1Midpoint(A, F') → UMidpoint(B', A) → VSegment(F, U) → k_1Segment(V, B) → l_1Plane(A, G, F) → oCircle(G, (0.3 * r), o) → p_1Intersect(a_1, p_1) → W, ZIntersect(c_1, f_1) → A_1Intersect(c_1, f_1) → B_1Intersect(c_1, f_1) → C_1Intersect(c_1, p_1) → D_1, E_1Rotate(E_1, 45°, G, o) → F_1Rotate(F_1, 45°, G, o) → G_1Rotate(D_1, 45°, G, o) → H_1Rotate(H_1, 45°, G, o) → I_1Rotate(I_1, 45°, G, o) → J_1Segment(F_1, H_1) → m_1Segment(E_1, D_1) → n_1Segment(G_1, G) → r_1Segment(J_1, Z) → s_1Translate(B, v) → B'_1Segment(B'_1, F'_1) → b_2Segment(I, B'_1) → t_1Segment(I, F'_1) → c_2Plane(B'_1, I, K) → wCircle(I, (0.3 * r), w) → d_2Point(t) → K_1Point(t) → L_1Intersect(t_1, d_2) → O_1,Intersect(a_3, d_2) → P_1, Q_1Rotate(O_1, (-(45°)), I, w) → R_1Rotate(Q_1, (-(45°)), I, w) → S_1Rotate(S_1, (-(45°)), I, w) → T_1Rotate(T_1, (-(45°)), I, w) → U_1Rotate(U_1, (-(45°)), I, w) → V_1Rotate(V_1, (-(45°)), I, w) → W_1Segment(W_1, S_1) → e_2Segment(T_1, O_1) → f_2Segment(U_1, I) → h_2Segment(V_1, Q_1) → i_2Plane(F'_1, I, K) → o_1Circle(I, (0.3 * r), o_1) → k_2Rotate(K, 45°, I, o_1) → K'Rotate(K', 45°, I, o_1) → K''Rotate(K'', 45°, I, o_1) → K'''Rotate(K''', 45°, I, o_1) → Z_1Rotate(Z_1, 45°, I, o_1) → A_2Rotate(A_2, 45°, I, o_1) → B_2Rotate(B_2, 45°, I, o_1) → C_2Segment(C_2, K''') → j_2Segment(I, A_2) → l_2Segment(B_2, K'') → m_2Translate(B'_1, u_1) → D_2Segment(D_2, E_2) → n_2Midpoint(n_2) → F_2Intersect(i_2, j_2) → I_2Mirror(G_2, a_3) → M_2Segment(E_2, I) → q_2Segment(I, D_2) → r_2Mirror(G, i_2) → G'Mirror(I, i_2) → I'Segment(G', I') → b_3Point(zAxis) → R_2Sphere(R_2, (0.8 * r)) → v_1Intersect(zAxis, v_1) → S_2, T_2OrthogonalPlane(S_2, zAxis) → w_1Ray(E, S) → d_3Intersect(d_3, g) → U_2, V_2Segment(U_2, E) → e_3Rotate(U_2, 45°, e_1) → W_2Rotate(E, 45°, e_1) → E'Segment(W_2, E') → f_3Rotate(W_2, 45°, e_1) → Z_2Rotate(E', 45°, e_1) → E''Segment(Z_2, E'') → h_3Rotate(Z_2, 45°, e_1) → A_3Rotate(E'', 45°, e_1) → E'''Segment(A_3, E''') → i_3Translate(U_2, v) → B_3Translate(E, v) → E'_1Segment(B_3, E'_1) → j_3Translate(W_2, v) → C_3Translate(E', v) → E''_1Segment(C_3, E''_1) → k_3Translate(Z_2, v) → D_3Translate(E'', v) → E'''_1Segment(D_3, E'''_1) → l_3Translate(A_3, v) → E_3Translate(E''', v) → F_3Segment(E_3, F_3) → m_3Cylinder(g, (-((0.08 * r)))) → o_2, p_3, u_2Cylinder(g, (-((-0.08 * r)))) → v_2, q_3, w_2Cylinder(g', (-((0.08 * r)))) → n_3, r_3, o_3Cylinder(g', (0.08 * r)) → s_3, t_3, u_3Plane(B, G, A) → v_3Circle(G, (0.3 * r), v_3) → c_4Intersect(f_1, h_1) → G_3Intersect(n_1, c_4) → H_3, I_3Rotate(H_3, 45°, G, v_3) → J_3Rotate(J_3, 45°, G, v_3) → K_3Rotate(K_3, 45°, G, v_3) → L_3Rotate(I_3, 45°, G, v_3) → M_3Rotate(M_3, 45°, G, v_3) → N_3Rotate(N_3, 45°, G, v_3) → O_3Segment(M_3, J_3) → a_4Segment(G, K_3) → b_4Segment(O_3, L_3) → d_4Mirror(G, E_1) → G'_1Midpoint(G'_1, E_1) → P_3Segment(P_3, G) → e_4OrthogonalPlane(P_3, e_4) → w_3Circle(P_3, (0.4 * r), w_3) → f_4Line(P_3, a_3) → g_4Intersect(g_4, f_4, 1) → Q_3Mirror(Q_3, P_3) → R_3Rotate(R_3, (-(60°)), P_3, w_3) → S_3Mirror(S_3, g_4) → T_3CircleSector(Q_3, S_3, T_3, w_3) → h_4Line(D_2, E_2) → s_2Intersect(s_2, p_2) → M_1, N_1Rotate(N_1, 30°, D_2, p_2) → H_2Ray(D_2, H_2) → t_2Intersect(t_2, p_2) → J_2,Segment(J_2, D_2) → c_3Mirror(J_2, b_3) → K_2Mirror(D_2, b_3) → L_2Segment(K_2, L_2) → i_4Circle(A, (0.3 * r), j_1) → k_4Intersect(f_1, k_4) → N_2, O_2Rotate(O_2, (-(45°)), A, k_4) → P_2Rotate(P_2, (-(45°)), A, k_4) → U_3Rotate(U_3, (-(45°)), A, k_4) → Q_2Rotate(Q_2, (-(45°)), A, k_4) → V_3Rotate(V_3, (-(45°)), A, k_4) → W_3Rotate(W_3, (-(45°)), A, k_4) → Z_3Rotate(Z_3, (-(45°)), A, k_4) → A_4Segment(A_4, Q_2) → j_4Segment(O_2, V_3) → l_4Segment(U_3, Z_3) → m_4Segment(P_2, W_3) → n_4Segment(V, U) → p_4
AI 绘图提示语参考
在三维空间中绘制一个自行车模型,包含多个圆柱体、球体和长方体,通过旋转和平移操作组合成车架、车轮和车座等部件。先绘制基本几何体,再通过直线和圆的相交确定关键点,最后用多边形和线段连接各部件,形成完整的自行车结构。
以上提示语为根据原始绘图命令整理而来,仅供参考。