
Rigid Body Rotation Animation
Loading the math board and drawing, please wait…
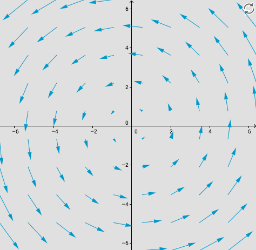
This GeoGebra example demonstrates the rotation of a rigid body around a fixed point, visualizing how multiple labeled points (A1-A19, B1-B16) move synchronously while maintaining their relative positions. The core mathematical concept is rigid body motion, specifically rotation transformations, involving rotation matrices, angular velocity, and the invariance of distances between points. The construction uses the Corner command to define reference points and the Sequence command to generate point arrays, with a time slider controlling the rotation angle for smooth animation. Suitable for high school or university courses in physics and mathematics to illustrate rigid body dynamics, rotational symmetry, or geometric transformations in computer graphics. It serves as an interactive tool for students to explore the mathematical representation of rotation.
GeoGebra Commands & Parameters
Corner(1) → C01Corner(2) → C02Corner(3) → C03Corner(4) → C04Sequence(Sequence[Vector[(j, k), (j + (scale * f(j, k)), k + (scale * g(j, k)))], j, xmin, xmax, xstep], k, ymin, ymax, ystep) → fieldSequence(Segment[Rotate[C1 - (0.6, 0), k + curlAngle, C1], Rotate[C1 + (0.6, 0), k + curlAngle, C1]], k, 0, 2.0944, 1.0472) → E1Sequence(Segment[Rotate[C2 - (0.600000000000002, 0), k + curlAngle, C2], Rotate[C2 + (0.600000000000002, 0), k + curlAngle, C2]], k, 0, 2.0944, 1.0472) → E2Sequence(Segment[Rotate[C3 - (0.600000000000002, 0), k + curlAngle, C3], Rotate[C3 + (0.600000000000002, 0), k + curlAngle, C3]], k, 0, 2.0944, 1.0472) → E3Sequence(Segment[Rotate[C4 - (0.600000000000002, 0), k + curlAngle, C4], Rotate[C4 + (0.600000000000002, 0), k + curlAngle, C4]], k, 0, 2.0944, 1.0472) → E4Sequence(Segment[Rotate[C5 - (0.600000000000002, 0), k + curlAngle, C5], Rotate[C5 + (0.600000000000002, 0), k + curlAngle, C5]], k, 0, 2.0944, 1.0472) → E5Sequence(Segment[Rotate[C6 - (0.600000000000002, 0), k + curlAngle, C6], Rotate[C6 + (0.600000000000002, 0), k + curlAngle, C6]], k, 0, 2.0944, 1.0472) → E6Sequence(Segment[Rotate[C7 - (0.600000000000002, 0), k + curlAngle, C7], Rotate[C7 + (0.600000000000002, 0), k + curlAngle, C7]], k, 0, 2.0944, 1.0472) → E7Sequence(Segment[Rotate[C8 - (0.600000000000002, 0), k + curlAngle, C8], Rotate[C8 + (0.600000000000002, 0), k + curlAngle, C8]], k, 0, 2.0944, 1.0472) → E8Sequence(Segment[Rotate[C9 - (0.600000000000002, 0), k + curlAngle, C9], Rotate[C9 + (0.600000000000002, 0), k + curlAngle, C9]], k, 0, 2.0944, 1.0472) → E9Sequence(Segment[Rotate[C10 - (0.600000000000002, 0), k + curlAngle, C10], Rotate[C10 + (0.600000000000002, 0), k + curlAngle, C10]], k, 0, 2.0944, 1.0472) → E10Sequence(Segment[Rotate[C11 - (0.600000000000002, 0), k + curlAngle, C11], Rotate[C11 + (0.600000000000002, 0), k + curlAngle, C11]], k, 0, 2.0944, 1.0472) → E11Sequence(Segment[Rotate[C12 - (0.600000000000002, 0), k + curlAngle, C12], Rotate[C12 + (0.600000000000002, 0), k + curlAngle, C12]], k, 0, 2.0944, 1.0472) → E12Sequence(Segment[Rotate[C13 - (0.600000000000002, 0), k + curlAngle, C13], Rotate[C13 + (0.600000000000002, 0), k + curlAngle, C13]], k, 0, 2.0944, 1.0472) → E13Sequence(Segment[Rotate[C14 - (0.600000000000002, 0), k + curlAngle, C14], Rotate[C14 + (0.600000000000002, 0), k + curlAngle, C14]], k, 0, 2.0944, 1.0472) → E14Sequence(Segment[Rotate[C15 - (0.600000000000002, 0), k + curlAngle, C15], Rotate[C15 + (0.600000000000002, 0), k + curlAngle, C15]], k, 0, 2.0944, 1.0472) → E15Sequence(Segment[Rotate[C16 - (0.600000000000002, 0), k + curlAngle, C16], Rotate[C16 + (0.600000000000002, 0), k + curlAngle, C16]], k, 0, 2.0944, 1.0472) → E16Sequence(Segment[Rotate[C17 - (0.600000000000002, 0), k + curlAngle, C17], Rotate[C17 + (0.600000000000002, 0), k + curlAngle, C17]], k, 0, 2.0944, 1.0472) → E17Sequence(Segment[Rotate[C18 - (0.600000000000002, 0), k + curlAngle, C18], Rotate[C18 + (0.600000000000002, 0), k + curlAngle, C18]], k, 0, 2.0944, 1.0472) → E18Sequence(Segment[Rotate[C19 - (0.600000000000002, 0), k + curlAngle, C19], Rotate[C19 + (0.600000000000002, 0), k + curlAngle, C19]], k, 0, 2.0944, 1.0472) → E19Sequence(Segment[Rotate[C20 - (0.600000000000002, 0), k + curlAngle, C20], Rotate[C20 + (0.600000000000002, 0), k + curlAngle, C20]], k, 0, 2.0944, 1.0472) → E20