
Logarithmic Property Dynamic Demonstration
Loading the math board and drawing, please wait…
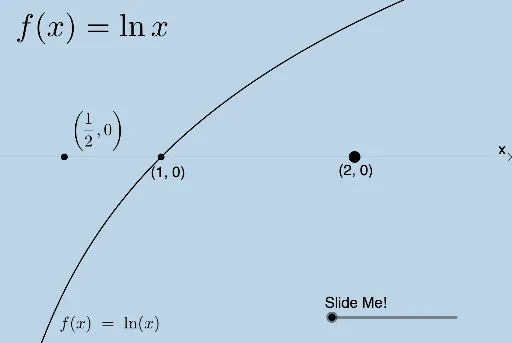
This example dynamically demonstrates the reciprocal property of logarithms through interactive graphics, showcasing the characteristics of logarithmic functions. Core mathematical concepts include logarithmic functions, geometric transformations, and vector operations. It utilizes commands and objects like Textfield, Intersect, Dilate, Segment, Vector, Translate, Rotate, Distance in GeoGebra. Suitable for high school mathematics education to enhance understanding of logarithmic properties and geometric transformations.
GeoGebra Commands & Parameters
Textfield(a) → InputBox1Textfield(f_1) → InputBox2Textfield(f) → InputBox3Intersect(f, h, 1) → EDilate(F, If[0 < d ≤ 1, 1 - d, 0], A) → F'Dilate(A, If[1 < d ≤ 2, 2 - d, 0], B) → A'Segment(A, A') → jDilate(B, If[2 < d ≤ 3, 3 - d, 0], G) → B'Vector(B, B') → uTranslate(A, u) → A'_1Translate(A', u) → A''Segment(A'_1, A'') → j'Rotate(A'_1, If[3 < d ≤ 4, ((-(d - 3)) * π / 2), ((-π)) / 2], F) → HRotate(A'', If[3 < d ≤ 4, ((-(d - 3)) * π / 2), ((-π)) / 2], F) → A'''Segment(H, A''') → j''Rotate(A'_1, If[3 < d ≤ 4, ((d - 3) * π / 2), π / 2], F) → IRotate(A'', If[3 < d ≤ 4, ((d - 3) * π / 2), π / 2], F) → A'''_1Dilate(D, If[4 < d ≤ 5, 5 - d, 0], E) → D'Segment(D, D') → lDilate(A, If[1 < d ≤ 2, 2 - d, 0], C) → A'_2Segment(A, A'_2) → mDilate(A, If[2 < d ≤ 3, 3 - d, 0], R) → C'Vector(C, C') → vIntersect(f, p, 1) → NRotate(F, If[5 < d ≤ 6, ((d - 5) * π / 2), π / 2], F) → F'_1Rotate(F', If[5 < d ≤ 6, ((d - 5) * π / 2), π / 2], F) → F''Dilate(F, If[6 < d ≤ 7, 7 - d, 0], M) → F'_2Vector(F, F'_2) → wTranslate(F'_1, w) → PTranslate(F'', w) → F'''Distance(A, C) → distanceACVector(A, A'_2) → iVector(A, C') → b_1Translate(i, b_1) → i'Dilate(W, If[6 < d ≤ 7, 7 - d, 0], L) → W'Vector(W, W') → w_1Distance(W, L) → distanceWLDilate(T, If[2 < d ≤ 3, 3 - d, 0], U) → T'Vector(T, T') → eDistance(T, U) → distanceTURotate(C, If[3 < d ≤ 4, ((-(d - 3)) * π), (-π)], A) → C'_1Vector(A, C'_1) → qDilate(A, If[4 < d ≤ 5, 5 - d, 0], T) → A'_3Vector(A, A'_3) → u_1Translate(C'_1, u_1) → QVector(A'_3, Q) → v_1