
Kite Diagonals Animation
Loading the math board and drawing, please wait…
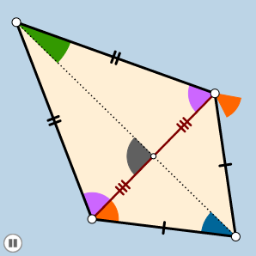
This example demonstrates the diagonals of a kite and their properties through animation. Key math concepts include perpendicular bisectors, angle bisectors, reflections, and vectors. Construction involves commands like Segment, Midpoint, OrthogonalLine, Point, and transformations such as Dilate and Rotate. Suitable for high school geometry instruction to visualize kite properties and transformations.
GeoGebra Commands & Parameters
Segment(A, B) → aMidpoint(a) → COrthogonalLine(C, a) → bPoint(b) → EPoint(b) → G_1Ray(E, G_1) → h_2Point(h_2) → DSegment(C, D) → iCircle(D, (0.3 * i)) → qIntersect(q, h_2, 1) → H_1Segment(A, D) → cIntersect(q, c, 1) → KSegment(D, B) → dSegment(B, E) → eSegment(E, A) → fSegment(A, C) → gCircle(A, (0.3 * g)) → hCircle(B, (0.3 * g)) → kSegment(C, E) → jCircle(E, (0.3 * j)) → pCircle(C, (0.3 * g)) → rIntersect(h, f, 1) → FIntersect(h, c, 1) → GIntersect(k, e, 1) → HIntersect(k, d, 1) → IIntersect(q, d, 1) → JIntersect(p, e, 1) → LIntersect(b, j) → MIntersect(b, j) → NIntersect(b, j) → OIntersect(b, j) → PIntersect(b, j) → QIntersect(p, b, 2) → RIntersect(b, i) → SIntersect(q, b, 1) → TIntersect(p, f, 1) → UCircleSector(B, I, H) → sAngle(A, D, B) → αAngle(U, E, L) → βCircleSector(B, H, I) → tDilate(D, If[0 < l ≤ 1, 1 - l, 0], A) → D'Segment(D, D') → mRotate(D, If[1 < l ≤ 2, ((l - 1) * α), α], D) → D'_1Rotate(D', If[1 < l ≤ 2, ((l - 1) * α), α], D) → D''Segment(D'_1, D'') → m'Dilate(A, If[2 < l ≤ 3, 3 - l, 0], E) → A'Segment(A, A') → nRotate(A, If[3 < l ≤ 4, ((-(l - 3)) * ((2 * π) - β)), (-((2 * π) - β))], E) → A'_1Rotate(A', If[3 < l ≤ 4, ((-(l - 3)) * ((2 * π) - β)), (-((2 * π) - β))], E) → A''Segment(A'_1, A'') → n'Polygon(E, B, D, A) → poly1, e_1, b_1, d_1, a_1CircleSector(E, L, R) → f_1Dilate(D, If[4 < l ≤ 5, 5 - l, 0], E) → D'_2Segment(D, D'_2) → g_1Dilate(B, If[5 < l ≤ 6, 6 - l, 0], A) → B'Vector(B, B') → uTranslate(s, u) → s'Line(A, e) → h_1Intersect(h, h_1, 2) → VIntersect(h, g, 1) → WAngle(V, A, G) → γRotate(s', If[6 < l ≤ 7, ((l - 6) * γ), γ], A) → s''CircleSector(D, K, H_1) → c_1Rotate(f_1, If[8 < l ≤ 9, ((l - 8) * ((2 * π) - β) / 2), ((2 * π) - β) / 2], E) → p_1Dilate(A, If[9 < l ≤ 10, 10 - l, 0], C) → A'_2Segment(A, A'_2) → i_1Dilate(C, If[10 < l ≤ 11, 11 - l, 0], B) → D'_3Segment(C, D'_3) → j_1Segment(B, C) → l_1Intersect(k, l_1, 1) → ZCircleSector(B, I, Z) → q_1CircleSector(A, F, W) → r_1Rotate(C, If[11.5 < l ≤ 12.5, ((l - 11.5) * π), 3.141592653589793], C) → C'Rotate(D'_3, If[11.5 < l ≤ 12.5, ((l - 11.5) * π), 3.141592653589793], C) → A_1Segment(C', A_1) → m_1Dilate(A, If[12.5 < l ≤ 13.5, 13.5 - l, 0], B) → A'_3Vector(A, A'_3) → vTranslate(r_1, v) → s_1Line(B, n) → n_1Point(n_1) → B_1Ray(B, B_1) → t_1Point(t_1) → C_1Angle(H, B, C_1) → δAngle(Z, B, H) → εRotate(s_1, If[13.5 < l ≤ 14.5, ((-(l - 13.5)) * (ε + δ)), (-(ε + δ))], B) → c_2Dilate(B, If[14.5 < l ≤ 15.5, 15.5 - l, 0], A) → B'_1Vector(B, B'_1) → wTranslate(q_1, w) → d_2Translate(I, w) → I'Angle(G, A, I') → ζAngle(D, B, C) → ηRotate(d_2, If[15.5 < l ≤ 16.5, ((-(l - 15.5)) * (ζ + η)), (-(ζ + η))], A) → e_2Midpoint(A, B) → D_1Segment(D, E) → a_2Segment(A, B) → b_2Intersect(r, a_2, 2) → E_1Intersect(r, b_2, 2) → F_1CircleSector(C, E_1, F_1) → f_2Rotate(f_2, If[16.5 < l ≤ 17.5, ((-(l - 16.5)) * π / 2), -1.5707963267948966], D_1) → g_2Rotate(c_1, If[7 < l ≤ 8, ((l - 7) * α / 2), α / 2], D) → k_1