
Inscribed Angle Theorem Dynamic Demonstration
Loading the math board and drawing, please wait…
In collections
Circles (Theorems)
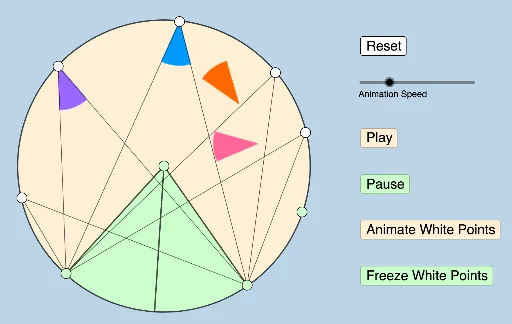
This example dynamically demonstrates the Inscribed Angle Theorem, visually showing the relationship between inscribed angles and their corresponding central angles through rotation and intersection changes. Core mathematical concepts include the Inscribed Angle Theorem, central angles, rotation, similar triangles, etc. Construction highlights involve GeoGebra commands/objects like Circle, Point, CircleArc, Angle, Rotate, Ray, Dilate, Segment, Intersect, CircleSector, Vector, Translate, and Line. Suitable for high school mathematics teaching to enhance understanding and application of the theorem.
GeoGebra Commands & Parameters
Circle(A, B) → cPoint(c) → CPoint(c) → DCircleArc(A, D, C) → dPoint(d) → EPoint(d) → FPoint(d) → GPoint(d) → HPoint(d) → ICircleArc(A, C, D) → eAngle(C, A, D) → αRotate(C, α / 2, A) → C'Angle(C, A, C') → βRay(A, C') → hDilate(A, If[0 < a ≤ 1, 1 - a, 0], C) → A'Dilate(A, If[0 < a ≤ 1, 1 - a, 0], D) → A'_1Segment(A, A') → fSegment(A, A'_1) → gSegment(A, B) → iSegment(A, C) → jCircle(A, (0.3 * i)) → kIntersect(k, j) → K,Dilate(E, If[1 < a ≤ 2, 2 - a, 0], C) → E'Dilate(E, If[1 < a ≤ 2, 2 - a, 0], D) → E'_1Dilate(F, If[1 < a ≤ 2, 2 - a, 0], D) → F'Dilate(G, If[1 < a ≤ 2, 2 - a, 0], D) → G'Dilate(H, If[1 < a ≤ 2, 2 - a, 0], D) → H'Dilate(I, If[1 < a ≤ 2, 2 - a, 0], D) → I'Dilate(F, If[1 < a ≤ 2, 2 - a, 0], C) → F'_1Dilate(G, If[1 < a ≤ 2, 2 - a, 0], C) → G'_1Dilate(H, If[1 < a ≤ 2, 2 - a, 0], C) → H'_1Dilate(I, If[1 < a ≤ 2, 2 - a, 0], C) → I'_1Segment(E, E') → lSegment(E, E'_1) → mSegment(F, F'_1) → nSegment(F, F') → pSegment(G, G'_1) → qSegment(G, G') → rSegment(H, H'_1) → sSegment(H, H') → tSegment(I, I'_1) → bSegment(I, I') → f_1Dilate(A, If[0 < a ≤ 1, 1 - a, 0], C') → A'_2Segment(A, A'_2) → i_1Rotate(K, If[1 < a ≤ 2, ((a - 1) * α), α], A) → K'CircleSector(A, K, K') → c_1CircleSector(A, D, C) → d_1CircleSector(A, C, D) → e_1Rotate(K, If[0 < a ≤ 1, (a * α / 2), α / 2], A) → K'_1CircleSector(A, K, K'_1) → k_1Ray(E, C) → j_1Ray(F, C) → l_1Ray(G, C) → m_1Ray(H, C) → n_1Ray(I, C) → p_1Circle(E, (0.3 * i)) → r_1Circle(F, (0.3 * i)) → s_1Circle(G, (0.3 * i)) → t_1Circle(H, (0.3 * i)) → c_2Circle(I, (0.3 * i)) → d_2Intersect(r_1, j_1) → L,Intersect(n, l_1) → MIntersect(s_1, l_1) → N,Intersect(t_1, m_1) → O,Intersect(c_2, n_1) → P,Intersect(d_2, p_1) → Q,Rotate(Q, If[1 < a ≤ 2, ((a - 1) * α / 2), α / 2], I) → Q'CircleSector(I, Q, Q') → f_2Rotate(k_1, If[2 < a ≤ 3, ((a - 2) * α / 2), α / 2], A) → g_2Dilate(I, If[3 < a ≤ 4, 4 - a, 0], F) → I'_2Vector(I, I'_2) → uTranslate(f_2, u) → h_2Line(I, n) → a_1Point(a_1) → SAngle(Q, I, S) → γRotate(h_2, If[3 < a ≤ 4, ((-(a - 3)) * ((2 * π) - γ)), γ - (2 * π)], I'_2) → k_2Dilate(A, If[3.5 < a ≤ 4.5, 4.5 - a, 0], I) → A'_3Vector(A, A'_3) → vTranslate(g_2, v) → p_2Rotate(K, If[3.5 < a ≤ 4.5, ((a - 3.5) * α / 2), α / 2], A) → K'_2CircleSector(A, K, K'_2) → q_2Line(I, i_1) → b_1Point(b_1) → TAngle(Q, I, T) → δRotate(p_2, If[3.5 < a ≤ 4.5, ((a - 3.5) * ((2 * π) - δ)), (2 * π) - δ], A'_3) → r_2Dilate(F, If[4.5 < a ≤ 5.5, 5.5 - a, 0], G) → F'_2Vector(F, F'_2) → wTranslate(k_2, w) → s_2Line(G, n) → i_2Point(i_2) → UAngle(O, G, U) → εRotate(s_2, If[4.5 < a ≤ 5.5, ((-(a - 4.5)) * ε), (-ε)], F'_2) → t_2Rotate(L, If[3 < a ≤ 4, ((a - 3) * α / 2), α / 2], E) → L'CircleSector(E, L, L') → c_3Dilate(E, If[5 < a ≤ 6, 6 - a, 0], H) → E'_2Vector(E, E'_2) → u_1Translate(c_3, u_1) → d_3Line(H, l) → j_2Point(j_2) → VAngle(P, H, V) → ζRotate(d_3, If[5 < a ≤ 6, ((a - 5) * ((2 * π) - ζ)), (2 * π) - ζ], E'_2) → e_3Dilate(A, If[5.5 < a ≤ 6.5, 6.5 - a, 0], E) → A'_4Vector(A, A'_4) → v_1Translate(q_2, v_1) → f_3Line(E, f) → l_2Point(l_2) → WAngle(W, E, C) → ηRotate(f_3, If[5.5 < a ≤ 6.5, ((a - 5.5) * η), η], A'_4) → g_3Dilate(I, If[6 < a ≤ 7, 7 - a, 0], F) → I'_3Vector(I, I'_3) → w_1Translate(r_2, w_1) → g_1Line(F, b) → h_1Point(h_1) → JAngle(J, F, N) → θRotate(g_1, If[6 < a ≤ 7, ((-(a - 6)) * ((2 * π) - θ)), θ - (2 * π)], I'_3) → q_1Rotate(K, If[6.5 < a ≤ 7.5, ((a - 6.5) * β), β], A) → K'_3CircleSector(A, K, K'_3) → e_2Dilate(H, If[7 < a ≤ 8, 8 - a, 0], I) → H'_2Vector(H, H'_2) → u_2Translate(e_3, u_2) → h_3Line(I, s) → m_2Point(m_2) → RAngle(R, I, Q) → κRotate(h_3, If[8 < a ≤ 9, ((a - 8) * κ), κ], I) → k_3Dilate(A, If[8 < a ≤ 9, 9 - a, 0], H) → A'_5Vector(A, A'_5) → v_2Translate(e_2, v_2) → p_3Line(H, f) → n_2Point(n_2) → ZAngle(Z, H, P) → λRotate(p_3, If[8 < a ≤ 9, ((a - 8) * λ), λ], A'_5) → q_3