
Dynamic Geometry Problem Example
Loading the math board and drawing, please wait…
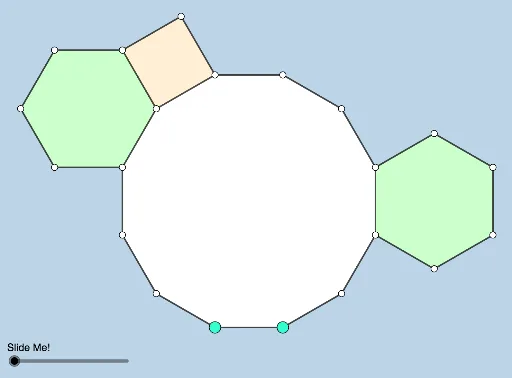
This is a dynamic and modifiable geometry problem example based on a problem posted by Ed Southall on Twitter. The example demonstrates key mathematical concepts such as angles and geometry. Using GeoGebra commands like Polygon, Ray, Segment, etc., the geometry can be dynamically adjusted to help understand geometric transformations and construction points. Suitable for students and teachers at the middle school level and above.
GeoGebra Commands & Parameters
Polygon(A, B, 12) → poly1, f, p, q, r, C, D, E, F, G, H, I, g, J, K, L, h, i, j, k, l, m, nPolygon(J, I, 6) → poly2, s, P, t, a, b, c, d, M, N, OPolygon(I, H, 4) → poly3, e, f_1, g_1, h_1, Q, RPolygon(E, D, 6) → poly4, i_1, V, j_1, k_1, l_1, m_1, n_1, S, T, URay(Q, N) → p_1Ray(Q, S) → q_1Segment(A, B) → r_1Segment(B, C) → s_1Segment(C, D) → t_1Segment(D, E) → a_1Segment(E, F) → b_1Segment(F, G) → c_1Segment(G, H) → d_1Segment(H, I) → e_1Segment(I, J) → f_2Segment(J, K) → g_2Segment(K, L) → h_2Segment(L, A) → i_2Segment(H, Q) → j_2Segment(Q, R) → k_2Segment(R, I) → l_2Segment(R, N) → m_2Segment(N, O) → n_2Segment(O, P) → p_2Segment(P, J) → q_2Segment(D, S) → r_2Segment(S, T) → s_2Segment(T, U) → t_2Segment(U, V) → a_2Segment(V, E) → b_2Semicircle(U, Q) → c_2Dilate(Q, If[0 < o ≤ 1, 1 - o, 0], N) → Q'Dilate(Q, If[0 < o ≤ 1, 1 - o, 0], S) → Q'_1Segment(Q, Q') → d_2Segment(Q, Q'_1) → e_2Rotate(V, If[1 < o ≤ 2, (((o - 1) * 2) * π / 3), (2 * π / 3)], U) → V'Circle(U, (0.5 * a_2)) → c_3Ray(U, V') → f_3Intersect(c_3, f_3, 1) → WIntersect(c_3, a_2, 1) → ZCircleSector(U, Z, W) → d_3Rotate(U, If[2.5 < o ≤ 3.5, ((-(o - 2.5)) * π), (-π)], Midpoint[Q, U]) → U'Vector(U, U') → uLine(U, d_2) → g_3Point(g_3) → A_1Translate(d_3, u) → e_3Point(g_3) → B_1Rotate(e_3, If[2.5 < o ≤ 3.5, (((-(o - 2.5)) * 7) * π / 4), (-7 * π / 4)], U') → h_3