
Dynamic Geometry Illustration by Tim Brzezinski (7)
Loading the math board and drawing, please wait…
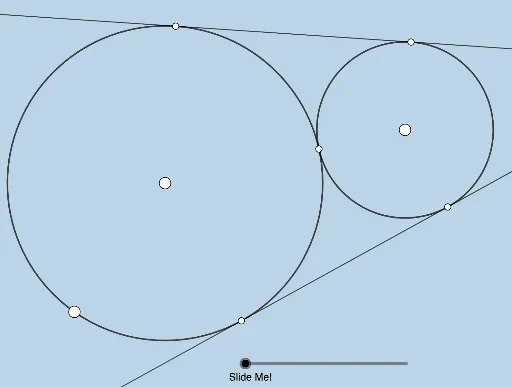
This example dynamically demonstrates the relationship between circles and vectors in 2D space, including geometric transformations like rotation, reflection, and translation. It involves core math concepts such as vector operations, coordinate geometry, and integral optimization. Construction highlights include commands like Circle, Vector, Rotate, Mirror, and Translate from GeoGebra. Suitable for high school and above, helping visualize vector, transformation, and optimization problems.
GeoGebra Commands & Parameters
Circle(A, B) → cPointIn(a) → CLine(A, C) → fIntersect(c, f, 2) → DCircle(C, D) → dTangent(c, d) → g, h, i, jIntersect(-6.398920282033919x² - 3.292519525505094x y + 0.6337072027875582y² + 100.00578631456865x + 27.07638245499153y = 371.2334325847297, c) → , , ,Intersect(c, h, 1) → EIntersect(c, g, 1) → FIntersect(d, g, 1) → GIntersect(d, h) → HLine(A, H) → kLine(C, E) → lIntersect(l, k) → ILine(A, G) → mLine(F, C) → nAngle(A, I, C) → αIntersect(m, n) → JSegment(A, C) → pAngle(F, J, G) → βAngle(C, J, A) → γDilate(A, If[0 < b ≤ 1, 1 - b, 0], H) → A'Segment(A, A') → qDilate(C, If[1 < b ≤ 2, 2 - b, 0], I) → C'Segment(C, C') → rDilate(I, If[2 < b ≤ 3, 3 - b, 0], E) → I'Segment(I, I') → sPolygon(I, H, E) → t1, e, i_1, h_1Dilate(A, If[0 < b ≤ 1, 1 - b, 0], G) → A'_1Segment(A, A'_1) → tDilate(C, If[1 < b ≤ 2, 2 - b, 0], J) → C'_1Segment(C, C'_1) → f_1Dilate(J, If[2 < b < 3, 3 - b, 0], F) → J'Segment(J, J') → g_1Polygon(F, J, G) → t2, g_2, f_2, j_1Dilate(J, If[4 < b < 5, 5 - b, 0], I) → J'_1Vector(J, J'_1) → uTranslate(F, u) → F'Translate(J, u) → J'_2Translate(G, u) → G'Mirror(J, g) → J'_3Dilate(J, If[4 < b < 5, 5 - b, 0], J'_3) → J'_4Polygon(F, J'_4, G) → t3, g_3, f_3, j'_4Angle(J'_3, F, J) → εAngle(J, G, J'_3) → ζRotate(J, If[5 < b ≤ 6, ((-(b - 5)) * ε), (-ε)], F) → J'_5Rotate(J, If[5 < b ≤ 6, ((b - 5) * ζ), ζ], G) → J'_6Segment(F, J'_5) → l_1Segment(G, J'_6) → m_1Dilate(J'_3, If[7 < b ≤ 8, 8 - b, 0], I) → MVector(J'_3, M) → vTranslate(F, v) → F'_1Translate(J'_4, v) → NTranslate(G, v) → G'_1Polygon(F'_1, N, G'_1) → t3', g'_1, f'_1, n_1Line(I, l_1) → k_1Point(k_1) → KAngle(E, I, K) → δRotate(F'_1, If[8 < b ≤ 9, ((-(b - 8)) * δ), (-δ)], I) → LRotate(N, If[8 < b ≤ 9, ((-(b - 8)) * δ), (-δ)], I) → N'Rotate(G'_1, If[8 < b ≤ 9, ((-(b - 8)) * δ), (-δ)], I) → OPolygon(L, N', O) → t3'', o, l_2, n'Distance(F, G) → distanceFGDistance(A, C) → distanceACDistance(C, I) → distanceCIDistance(G, J'_3) → distanceGJ'3Distance(J'_3, F) → distanceJ'3FDistance(I, A) → distanceIASegment(A, C) → p_1Angle(J, A, C) → ηAngle(A, C, J) → θSegment(F, G) → q_1