
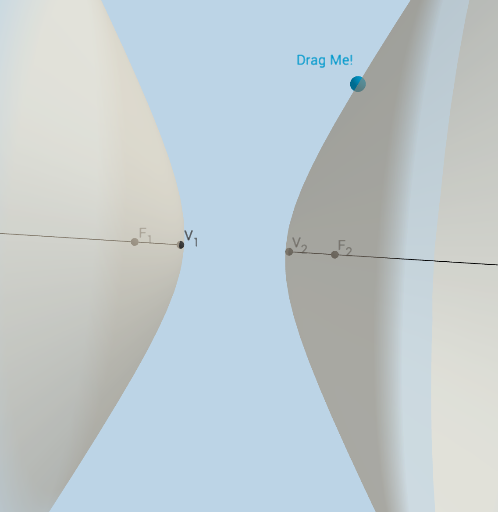
Demonstration of a Hyperboloid of Two Sheets as a Locus
Loading the math board and drawing, please wait…
In collections
GeoGebra 3D & AR: PreCalc & Calculus Resources
Multivariable Calculus
Quadratic Surfaces
This example dynamically illustrates a hyperboloid of two sheets as a locus. By adjusting parameters, you can observe the changes in the hyperboloid. The construction uses commands such as PointIn, Segment, Sphere, Intersect, Dilate, Angle, Plane, Rotate, Vector, Translate, Distance, Ray, etc., suitable for high school mathematics education.
GeoGebra Commands & Parameters
PointIn(c) → ASegment(F_1, A) → fSegment(A, F_2) → gSphere(F_1, e) → iIntersect(f, i) → F,Dilate(F_1, If[0 < h ≤ 1, 1 - h, 0], F) → C'Segment(F_1, C') → jDilate(F, If[1 < h ≤ 2, 2 - h, 0], A) → C'_1Segment(F, C'_1) → kDilate(F_2, If[2 < h ≤ 3, 3 - h, 0], A) → B'Segment(F_2, B') → lAngle(F_2, A, F_1) → αPlane(F_1, A, F_2) → mRotate(F_2, If[3 < h ≤ 4, ((h - 3) * α), α], A, m) → B'_1Rotate(B', If[3 < h ≤ 4, ((h - 3) * α), α], A, m) → B''Segment(B'_1, B'') → l'Segment(A, F) → nDilate(F_1, If[4 < h ≤ 5, 5 - h, 0], V_1) → C'_2Vector(F_1, C'_2) → uTranslate(F, u) → F'Angle(V_2, V_1, F') → βPlane(F', V_1, V_2) → oTranslate(F_1, u) → C'_3Translate(C', u) → C''Segment(C'_3, C'') → j'Rotate(C'_3, If[5 < h ≤ 6, ((-(h - 5)) * β), (-β)], V_1, o) → GRotate(C'', If[5 < h ≤ 6, ((-(h - 5)) * β), (-β)], V_1, o) → C'''Segment(G, C''') → j''Segment(F_2, A) → pSegment(F_1, A) → qSphere(F_2, e) → rDistance(V_1, V_2) → tSphere(F_2, s) → vIntersect(p, v) → Q, IDilate(F_2, If[0 < h ≤ 1, 1 - h, 0], I) → B'_2Segment(F_2, B'_2) → f_1Dilate(I, If[1 < h ≤ 2, 2 - h, 0], A) → I'Segment(I, I') → g_1Dilate(F_1, If[2 < h ≤ 3, 3 - h, 0], A) → C'_4Segment(F_1, C'_4) → h_1Angle(F_1, A, F_2) → γPlane(F_1, A, F_2) → wRotate(F_1, If[3 < h ≤ 4, h - 3]) → C'_5Rotate(C'_4, If[3 < h ≤ 4, h - 3]) → HSegment(C'_5, H) → i_1Rotate(C'_4, If[3 < h ≤ 4, h - 3]) → JRotate(F_1, If[3 < h ≤ 4, ((-(h - 3)) * γ), (-γ)], A, w) → C'_7Rotate(C'_4, If[3 < h ≤ 4, ((-(h - 3)) * γ), (-γ)], A, w) → KSegment(C'_7, K) → k_1Segment(I, A) → j_1Vector(F_2, V_2) → u_1Translate(I, u_1) → I'_1Dilate(F_2, If[4 < h ≤ 5, 5 - h, 0], V_2) → B'_3Vector(F_2, B'_3) → v_1Translate(F_2, v_1) → B'_4Translate(B'_2, v_1) → LSegment(B'_4, L) → l_1Angle(I'_1, V_2, V_1) → δRotate(B'_4, If[5 < h ≤ 6, h - 5]) → MRotate(L, If[5 < h ≤ 6, h - 5]) → L'Rotate(B'_4, If[5 < h ≤ 6, h - 5]) → NRotate(L, If[5 < h ≤ 6, h - 5]) → L'_1Rotate(B'_4, If[5 < h ≤ 6, h - 5]) → OPlane(I'_1, V_2, V_1) → a_1Rotate(B'_4, If[5 < h ≤ 6, ((-(h - 5)) * δ), (-δ)], V_2, a_1) → PRotate(L, If[5 < h ≤ 6, ((-(h - 5)) * δ), (-δ)], V_2, a_1) → L'_3Segment(P, L'_3) → q_1Ray(V_1, F_1) → m_1Ray(V_2, F_2) → n_1
AI Drawing Prompt Reference
Draw a hyperboloid of two sheets and observe its changes by adjusting parameter h. Start by constructing cones and cylinders with F1 and F2 as foci and A as the vertex, then use rotation and translation to generate the surface of the hyperboloid.
The prompt above was compiled from the original drawing commands and is for reference only.