
Cylinder Unwrapping Dynamic Demo
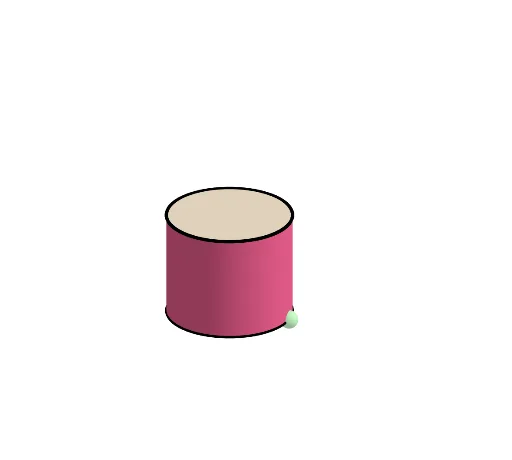
Loading the math board and drawing, please wait…
This example demonstrates the unfolding process of a cylinder, visually showing how the lateral surface transforms into a rectangle. It involves core mathematical concepts such as cylinder surface area calculation, the relationship between lateral and total surface area, and geometric transformations. Key GeoGebra commands and objects used in construction include Cylinder, Line, Intersect, Plane, Rotate, Dilate, Vector, Translate, Polygon, Segment, and CircleArc. Suitable for high school solid geometry and introductory calculus teaching, helping students understand the principles of area calculation.
GeoGebra Commands & Parameters
Cylinder(A, C, r) → a, c, d, bLine(D, E) → fIntersect(f, d, 1) → FSphere(F, r) → eIntersect(f, e) → G, HPlane(G, F, C) → gRotate(C, If[0 < i ≤ 1, (i * π / 2), π / 2], D, g) → C'Rotate(d, If[0 < i ≤ 1, (i * π / 2), π / 2], D, g) → d'Rotate(dd, If[0 < i ≤ 1, (i * π / 2), π / 2], D, g) → dd'Dilate(C, If[1 < i ≤ 2, 2 - i, 0], I) → C'_1Dilate(C, If[1 < i ≤ 2, 2 - i, 0], J) → C'_2Vector(C, C'_1) → uVector(C, C'_2) → vTranslate(dd, u) → dd'_1Translate(dd, v) → dd'_2Translate(K, u) → K'Translate(K, v) → K'_1Rotate(K', If[1 < i ≤ 2, ((i - 1) * π), π], C'_1) → K''Rotate(K'_1, If[1 < i ≤ 2, ((-(i - 1)) * π), (-π)], C'_2) → LTranslate(D, u) → D'Translate(D, v) → D'_1Polygon(D', D'_1, N, M) → poly1, d'_1, d'_2, n, mSegment(K'', Q) → jCircleArc(P, Q, M) → kSegment(L, S) → lCircleArc(R, N, S) → pCircleArc(C'_2, D'_1, L) → qCircleArc(C'_1, K'', D') → sPlane(T, A, B) → oRotate(C', If[2 < i ≤ 3, ((i - 2) * π / 2), π / 2], E, g) → C''Rotate(poly1, If[2 < i ≤ 3, ((i - 2) * π / 2), π / 2], E, g) → poly1'Rotate(d', If[2 < i ≤ 3, ((i - 2) * π / 2), π / 2], E, g) → d'_3Rotate(dd', If[2 < i ≤ 3, ((i - 2) * π / 2), π / 2], E, g) → dd'_3Rotate(K'', If[2 < i ≤ 3, ((i - 2) * π / 2), π / 2], E, g) → K'''Rotate(Q, If[2 < i ≤ 3, ((i - 2) * π / 2), π / 2], E, g) → Q'Segment(K''', Q') → j'Rotate(L, If[2 < i ≤ 3, ((i - 2) * π / 2), π / 2], E, g) → L'Rotate(S, If[2 < i ≤ 3, ((i - 2) * π / 2), π / 2], E, g) → S'Segment(L', S') → l'Dilate(C'', If[3 < i ≤ 4, 4 - i, 0], U) → C'''Vector(C'', C''') → wDilate(C'', If[3 < i ≤ 4, 4 - i, 0], V) → C'''_1Vector(C'', C'''_1) → tTranslate(Z, w) → Z'Translate(Z, t) → Z'_1Translate(W, w) → W'Translate(W, t) → W'_1Rotate(W', If[3 < i ≤ 4, ((-(i - 3)) * π), (-π)], C''') → W''CircleArc(C''', Z', W'') → c_1Segment(Z, Z') → f_1Rotate(W'_1, If[3 < i ≤ 4, ((i - 3) * π), π], C'''_1) → A_1CircleArc(C'''_1, Z'_1, A_1) → d_1Segment(Z, Z'_1) → g_1