
Animation 37: Comprehensive Geometric Transformations with Polygons and Circles
Loading the math board and drawing, please wait…
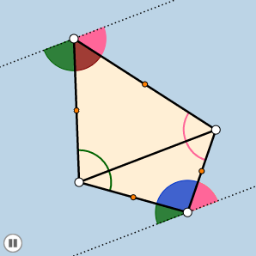
①This example presents a dynamic animation of a composite figure involving polygons, circles, angles, segments, and multiple geometric transformations, visually demonstrating the positional relationships and motion patterns among elements. ②Core mathematical concepts include angles, quadrilaterals, triangles, polygons, circles, vectors, translation, rotation, reflection (mirror), dilation (homothety), as well as optimization problems, equations, statistics, and arithmetic operations, showcasing an integrated application of diverse geometry topics. ③Construction highlights: Based on the construction summary, the GeoGebra commands used include Ray, Point, Circle, Intersect, Segment, Angle, CircleSector, Vector, Translate, Dilate, If, Line, Polygon, Rotate, Mirror, Midpoint, and CircleArc, involving numerous objects such as P, B, A, h_1, R, j_1, a, g, I_1, H, l_1, H_1, C, k_1, k, Z, b, M, N, D_1, E_1, e, f, D, E, γ, ε, ζ, h, J, K, L, q, t, u, c_1, v, j, q', and l, with conditional logic (If) and sliders driving the animation. ④This is suitable for upper secondary to early university students for exploring dynamic geometry, transformations, and mathematical modeling, and also serves as a reference for teachers creating interactive geometry lessons.
GeoGebra Commands & Parameters
Ray(P, A) → h_1Point(h_1) → RRay(A, R) → j_1Ray(A, B) → aCircle(A, 1.5) → gIntersect(g, j_1) → I_1,Intersect(g, a, 1) → HSegment(P, A) → l_1Intersect(g, l_1, 1) → H_1Segment(P, C) → k_1Circle(C, 1.5) → kIntersect(k, k_1) → Z,Ray(B, C) → bIntersect(k, b) → M, NPoint(a) → D_1Point(b) → E_1Ray(B, D_1) → eRay(C, E_1) → fPoint(e) → DPoint(f) → EAngle(A, C, B) → γAngle(D, B, C) → εAngle(E, C, A) → ζCircle(B, 1.5) → hIntersect(h, b, 1) → JIntersect(h, a, 1) → KIntersect(h, a, 2) → LCircleSector(B, J, K) → qCircleSector(B, L, J) → tVector(B, C) → uCircleSector(A, I_1, H) → c_1Vector(A, C) → vTranslate(q, u) → q'Segment(B, C) → lDilate(C, If[0 < j ≤ 1, j, 0], B) → C'Vector(B, C') → wTranslate(q, w) → q'_1Dilate(A, If[1 < j ≤ 2, 2 - j, 0], C) → C'_1Vector(A, C'_1) → mDilate(C, If[0 < n ≤ 1, n, 0], B) → C'_2Dilate(A, If[1 < n ≤ 2, 2 - n, 0], C) → A'Vector(B, C'_2) → u_1Vector(A, A') → v_1If(0 < n ≤ 1, Translate[t, u_1], Translate[t, u]) → e_1If(1 < n ≤ 2, Translate[c_1, v_1], Translate[c_1, v]) → f_1Ray(C, P) → g_1Point(g_1) → QRay(P, Q) → i_1Point(i_1) → SPoint(j_1) → TCircle(P, 1.5) → p_1Intersect(p_1, l_1) → U,Intersect(p_1, i_1) → V,Intersect(p_1, k_1) → W,CircleSector(P, U, W) → q_1Intersect(k, b, 2) → A_1Line(P, b) → b_1Intersect(p_1, b_1) → C_1, G_1Angle(B, A, P) → αVector(P, C) → iDilate(P, If[2 < j ≤ 3, 3 - j, 0], C) → P'Vector(P, P') → w_1Translate(q_1, w_1) → r_1CircleSector(C, N, Z) → sCircleSector(P, V, U) → t_1Dilate(P, If[2 < n ≤ 3, 3 - n, 0], C) → P'_1Vector(P, P'_1) → m_1If(2 < n ≤ 3, Translate[t_1, m_1], Translate[t_1, w_1]) → e_2Angle(H, A, I_1) → δAngle(V, P, U) → ηAngle(U, P, W) → θPolygon(A, B, C, P) → poly1, a_2, b_2, c_2, p_2Segment(A, C) → n_1Intersect(g, n_1) → F,Intersect(k, n_1) → G,Line(P, n_1) → cLine(B, n_1) → dCircleSector(C, Z, G) → d_1CircleSector(C, G, M) → s_1CircleSector(A, H, F) → d_2If(0 < j ≤ 1, Dilate[C, 1 - j, B]) → IIf(1 < j ≤ 2, Dilate[A, 2 - j, P]) → OIf(1 < j ≤ 2, Dilate[C, 2 - j, P]) → B_1Vector(C, I) → rVector(A, O) → u_2Translate(s_1, r) → h_2Rotate(d_2, 180°, A) → k_2Vector(A, B) → v_2Vector(C, B) → w_2Translate(s_1, w_2) → s_2Mirror(s_2, B) → t_2Vector(A, P) → i_2Vector(C, P) → j_2CircleSector(A, F, H_1) → f_2Translate(f_2, i_2) → d_3Vector(C, B_1) → l_2Translate(d_1, j_2) → f_3Mirror(f_3, P) → g_3Translate(f_2, u_2) → h_3Translate(d_1, l_2) → k_3Segment(A, B) → m_2Polygon(A, B, C) → poly2, c_4, a_3, b_3Polygon(A, C, P) → poly3, p_4, a_4, c_5Midpoint(m_2) → M_4Midpoint(l) → J_1Midpoint(k_1) → M_2Midpoint(l_1) → M_3Segment(J, C) → n_2Segment(J_1, C) → i_3Rotate(J_1, If[0 < j ≤ 1, (((-j) * 180))°, -180°], J_1) → M_1Rotate(C, If[0 < j ≤ 1, (((-j) * 180))°, -180°], J_1) → C'_3Segment(M_1, C'_3) → j_3Rotate(s_1, If[0 < j ≤ 1, (((-j) * 180))°, -180°], J_1) → r_3Segment(J_1, B) → r_2Rotate(d_2, If[0 < j ≤ 1, ((j * 180))°, 180°], M_4) → pRotate(A, If[0 < j ≤ 1, ((j * 180))°, 180°], M_4) → A'_1Segment(M_4, A'_1) → g_2Rotate(C, If[1 < j ≤ 2, (((j - 1) * 180))°, 180°], M_2) → C'_4Segment(M_2, C'_4) → q_2Rotate(d_1, If[1 < j ≤ 2, (((j - 1) * 180))°, 180°], M_2) → c_3Rotate(A, If[1 < j ≤ 2, (((-(j - 1)) * 180))°, 180°], M_3) → A'_2Segment(M_3, A'_2) → e_3Rotate(f_2, If[1 < j ≤ 2, (((-(j - 1)) * 180))°, 180°], M_3) → p_3CircleArc(C, G, M) → q_3CircleArc(A, H, F) → s_3CircleArc(C, Z, G) → t_3CircleArc(A, F, H_1) → d_4Segment(M_2, C) → l_3Segment(M_2, P) → m_3Segment(P, M_3) → n_3Segment(M_3, A) → b_4Segment(A, M_4) → e_4Segment(M_4, B) → f_4