
Visualizing Systems of Linear Equations
Loading the math board and drawing, please wait…
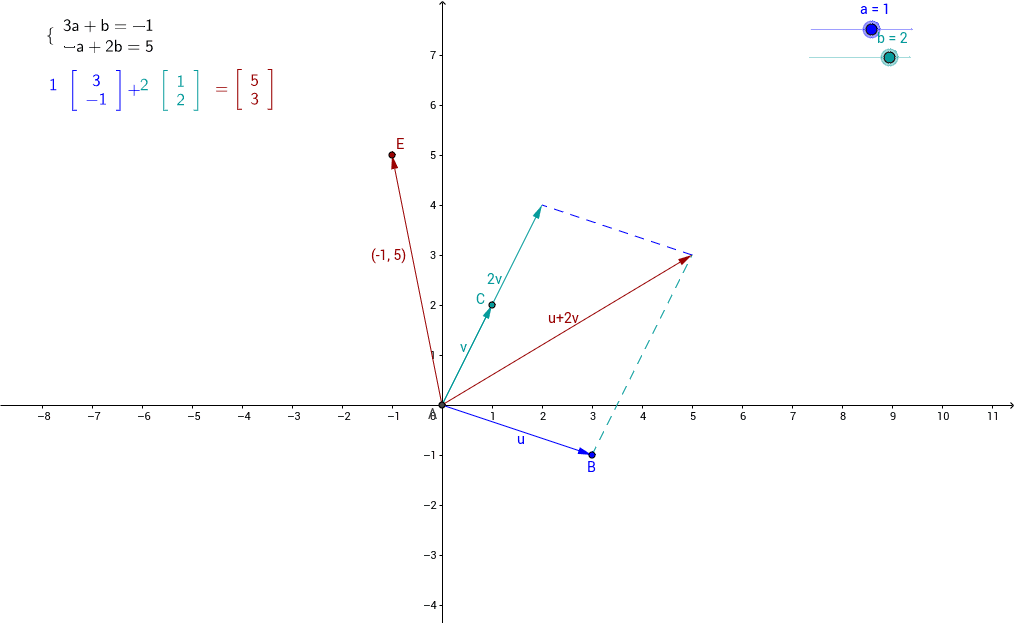
This example dynamically demonstrates the solution set of a system of linear equations, intuitively showing the geometric meaning of the equations. It involves core math concepts like linear equations, vectors, coordinate geometry, and geometric construction. GeoGebra commands used include Intersect (intersection), Line (line), Vector (vector), Mirror (reflection), and Segment (segment). Suitable for high school mathematics teaching to help students understand the solution methods and geometric representation of linear equations.
GeoGebra Commands & Parameters
Intersect(xAxis, yAxis) → ALine(A, K) → cVector(A, B) → uMirror(A, B) → A'_1Mirror(A, B) → A'_2Vector(A, A'_2) → vMirror(B, A'_2) → B'_1Vector(A, B'_1) → wMirror(B, A) → B'_2Mirror(A, B'_2) → A'_3Vector(A, B'_2) → zVector(A, A'_3) → dVector(A, C) → eMirror(A, C) → A'_4Mirror(C, A'_4) → C'_1Vector(A, A'_4) → fVector(A, C'_1) → gMirror(C, A) → C'_2Mirror(A, C'_2) → A'_5Vector(A, C'_2) → hVector(A, A'_5) → iLine(C, u) → jLine(C, u) → kLine(C, u) → lLine(B, e) → mIntersect(j, m) → DMirror(A, D) → A'_6Vector(A, D) → nSegment(B, D) → pSegment(C, D) → qVector(A, A'_6) → rSegment(A'_2, A'_6) → sSegment(A'_4, A'_6) → tMirror(D, A'_6) → D'_1Vector(A, D'_1) → u_1Segment(C'_1, D'_1) → a_1Segment(D'_1, B'_1) → b_1Mirror(D, A) → D'_2Mirror(A, D'_2) → A'Vector(A, D'_2) → v_1Segment(C'_2, D'_2) → c_1Segment(D'_2, B'_2) → d_1Vector(A, A') → w_1Segment(A'_3, A') → e_1Segment(A'_5, A') → f_1Vector(A, E) → z_1Mirror(B, D) → B'_3Vector(A, B'_3) → g_1Segment(B, B'_3) → h_1Segment(B'_3, A'_4) → i_1Mirror(D, B'_3) → D'_3Segment(C'_1, D'_3) → j_1Segment(B, D'_3) → k_1Vector(A, D'_3) → l_1Vector(A, C) → m_1Vector(A, B) → n_1Mirror(D, B) → D'_4Vector(A, D'_4) → p_1Segment(C'_2, D'_4) → q_1Segment(D'_4, B) → r_1Mirror(B, D'_4) → B'Segment(A'_5, B') → s_1Segment(B', B) → t_1Vector(A, B') → u_2Mirror(C, D) → C'_3Vector(A, C'_3) → v_2Segment(C, C'_3) → a_2Segment(C'_3, A'_2) → b_2Mirror(C'_3, A'_6) → C''_1Vector(A, C''_1) → w_2Segment(A'_2, C''_1) → c_2Segment(C''_1, C'_1) → d_2Mirror(C'_2, D'_4) → FSegment(C'_2, F) → e_2Segment(A'_2, F) → f_2Vector(A, F) → z_2Mirror(A'_5, B') → GVector(A, G) → g_2Segment(A'_5, G) → h_2Segment(G, A'_2) → i_2Mirror(B', G) → B''Segment(A'_5, B'') → j_2Segment(B'', B'_1) → k_2Vector(A, B'') → l_2Mirror(D'_4, F) → D''Vector(A, D'') → m_2Segment(C'_2, D'') → n_2Segment(D'', B'_1) → p_2Mirror(D, C'_3) → D'Segment(C, D') → q_2Segment(B'_1, D') → r_2Vector(A, D') → s_2Mirror(B'_3, A'_6) → HVector(A, H) → t_2Segment(A'_4, H) → a_3Segment(B'_1, H) → b_3Vector(A, B'_1) → u_3Vector(A, A'_2) → v_3Vector(A, B'_2) → w_3Vector(A, A'_3) → z_3Vector(A, A'_5) → c_3Vector(A, C'_2) → d_3Vector(A, A'_4) → e_3Vector(A, C'_1) → f_3Mirror(D'_4, A) → IVector(A, I) → g_3Segment(C, I) → h_3Segment(B'_2, I) → i_3Mirror(I, E) → I'Segment(I', C'_1) → j_3Segment(I', B'_2) → k_3Vector(A, I') → l_3Mirror(B'_2, D'_2) → JVector(A, J) → m_3Segment(B'_2, J) → n_3Segment(J, A'_5) → p_3Mirror(C'_2, D'_2) → LSegment(A'_3, L) → q_3Segment(L, C'_2) → r_3Vector(A, L) → s_3Mirror(C, I) → C'Vector(A, C') → t_3Segment(C, C') → a_4Segment(A'_3, C') → b_4Mirror(A'_3, C') → MSegment(A'_3, M) → c_4Segment(M, A'_4) → d_4Vector(A, M) → u_4Mirror(C', M) → C''Vector(A, C'') → v_4Segment(C'_1, C'') → e_4Segment(C'', A'_3) → f_4Segment(B'_2, E) → g_4Segment(E, A'_4) → h_4Vector(A, E) → w_4