
Visualizing Invariant Lines of Matrix {{-2,5},{6,-9}}
Loading the math board and drawing, please wait…
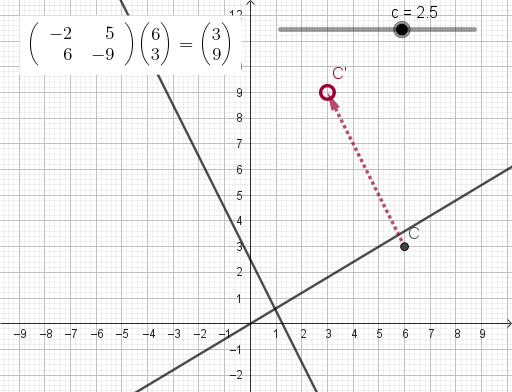
This GeoGebra example demonstrates which lines (invariant directions) remain unchanged under the 2D linear transformation defined by the matrix A = {{-2,5},{6,-9}}. In other words, it visualizes the geometric content of eigen-directions by showing directions whose points map onto the same line after applying the matrix. The key mathematics includes linear transformations, eigenvalues/eigenvectors (equivalently, invariant directions), and the mapping of vectors and points under matrix multiplication. Construction-wise, it uses commands such as ApplyMatrix to transform vectors/points by A, Vector to represent direction vectors (e.g., u, v, w), DynamicCoordinates to interactively place elements, ClosestPoint to locate/associate images with nearby candidate geometry, and If to conditionally select configurations. The scene includes objects like M, A, B, C, C' and a labeled text element (text2) to connect original and transformed geometry. Suitable for high-school advanced topics and early undergraduate linear algebra, especially for building intuition about eigenvectors as invariant lines.
GeoGebra Commands & Parameters
ClosestPoint({f, g}, P) → AIf(Distance[P, A] < 0.2, A, P) → BDynamicCoordinates(P, x(B), y(B)) → CApplyMatrix(M, C) → C'Vector(C, C') → uVector(C) → vVector(C') → w
AI Drawing Prompt Reference
Create a 2D linear transformation visualization showing invariant directions for the matrix A={{-2,5},{6,-9}}. Place an interactive point P in the plane, then determine a reference point B by comparing P to a nearby candidate point and choosing the closer one when appropriate. Define a movable point C using P’s coordinates relative to B. Apply the linear transformation defined by A to C to obtain its image C'. Draw the direction vector u from C to C', and also construct additional direction vectors v associated with C and w associated with C' to represent key eigen-direction candidates. Present the relationships among P, C, C', and the vectors u, v, and w clearly on the same plane.
The prompt above was compiled from the original drawing commands and is for reference only.