
Velocity and Acceleration Vectors on Parametric Curve
Loading the math board and drawing, please wait…
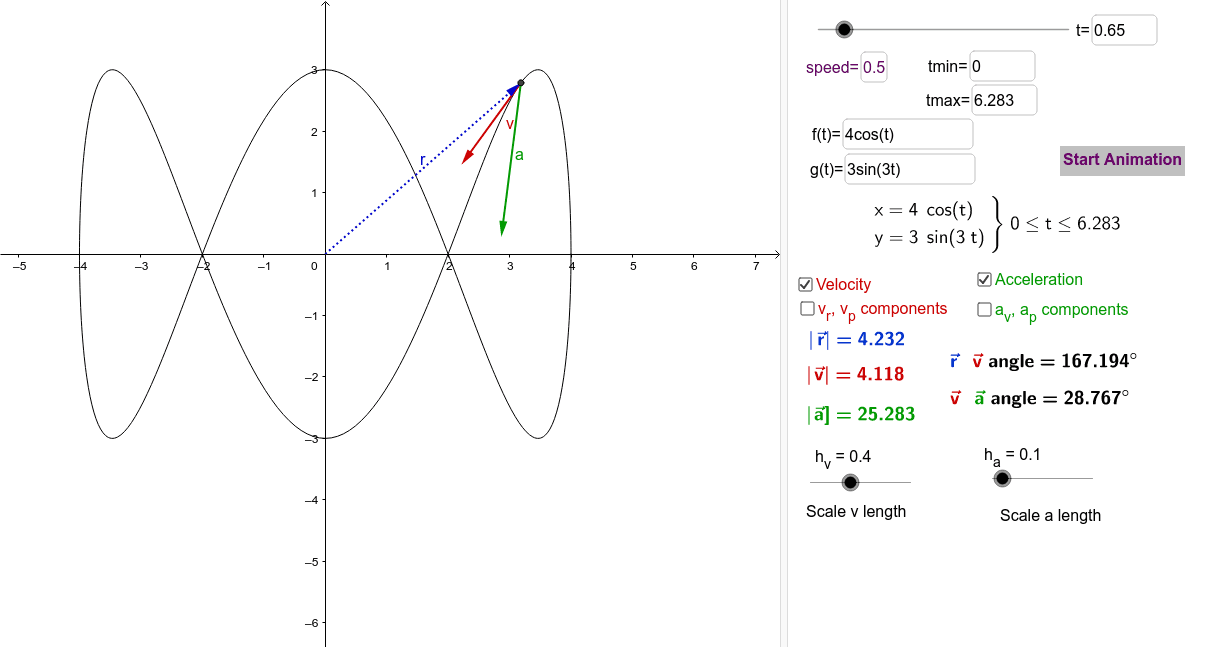
This example demonstrates the decomposition of velocity and acceleration vectors into components parallel and perpendicular to the position vector on a parametric curve. Key math concepts include vector decomposition, parametric equations, derivatives, and the geometric interpretation of velocity and acceleration vectors. It utilizes GeoGebra commands like Derivative, CurveCartesian, Textfield, and If, focusing on vector analysis and the application of calculus in geometry, suitable for high school and above.
GeoGebra Commands & Parameters
Derivative(g) → g'Derivative(g') → g''Derivative(f) → f'Derivative(f') → f''CurveCartesian(f(t), g(t), t, tmin, tmax) → cCurveCartesian(f'(t), g'(t), t, tmin, tmax) → cdotCurveCartesian(f''(t), g''(t), t, tmin, tmax) → cddotTextfield(tmin) → TminTextfield(tmax) → TmaxTextfield(f) → FofTTextfield(g) → GofTIf(togA ≟ 1, "Stop Animation", "Start Animation") → AnimateTextfield(speed) → SPDTextfield(t) → tEq