
Systems of Inequalities Demo
Loading the math board and drawing, please wait…
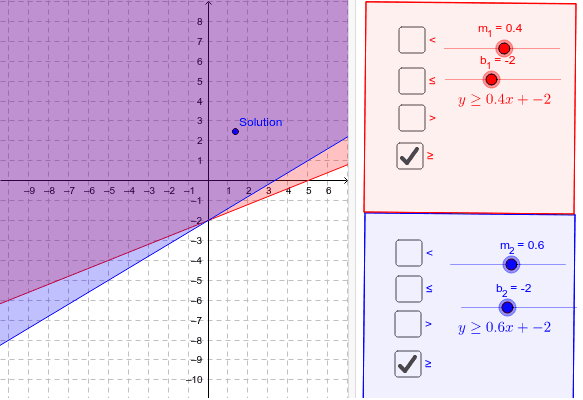
This example demonstrates the solution regions of systems of inequalities in a 2D plane. It involves core mathematical concepts such as inequalities, region representation, linear function graphs, and polygon boundaries. The construction summary utilizes commands like DynamicCoordinates and Polygon, along with objects like m_1, b_1, a, b, c, d, e, f, g, h, text elements, and coordinate points for dynamic coordinate plotting and polygon creation. It is suitable for high school mathematics teaching, particularly in analytical geometry, to understand the relationship between inequality sets and geometric shapes, as well as dynamic changes.
GeoGebra Commands & Parameters
DynamicCoordinates(A, x(A), y(A)) → BDynamicCoordinates(A, x(A), y(A)) → CDynamicCoordinates(A, x(A), y(A)) → DDynamicCoordinates(A, x(A), y(A)) → EDynamicCoordinates(A, x(A), y(A)) → FDynamicCoordinates(A, x(A), y(A)) → GDynamicCoordinates(A, x(A), y(A)) → HDynamicCoordinates(A, x(A), y(A)) → IDynamicCoordinates(A, x(A), y(A)) → JDynamicCoordinates(A, x(A), y(A)) → KDynamicCoordinates(A, x(A), y(A)) → LDynamicCoordinates(A, x(A), y(A)) → MDynamicCoordinates(A, x(A), y(A)) → NDynamicCoordinates(A, x(A), y(A)) → ODynamicCoordinates(A, x(A), y(A)) → PPolygon(Q, R, 4) → poly1, q, r, s, t, S, TPolygon(Q_1, R_1, 4) → poly1_1, q_1, r_1, s_1, t_1, S_1, T_1