
Systems of Inequalities Demo by Ansley
Loading the math board and drawing, please wait…
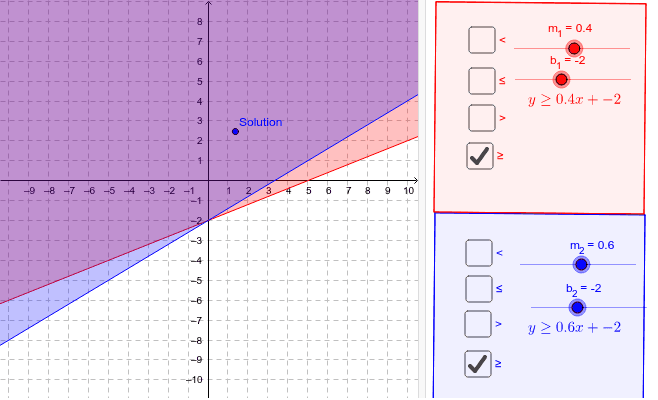
This example demonstrates how to visualize systems of inequalities using dynamic coordinates and polygon constructions. It involves core math concepts like inequalities, transformations, coordinate geometry, and probability & statistics. The construction utilizes GeoGebra commands such as DynamicCoordinates and Polygon. Ideal for high school mathematics teaching and geometric constructions.
GeoGebra Commands & Parameters
DynamicCoordinates(A, x(A), y(A)) → BDynamicCoordinates(A, x(A), y(A)) → CDynamicCoordinates(A, x(A), y(A)) → DDynamicCoordinates(A, x(A), y(A)) → EDynamicCoordinates(A, x(A), y(A)) → FDynamicCoordinates(A, x(A), y(A)) → GDynamicCoordinates(A, x(A), y(A)) → HDynamicCoordinates(A, x(A), y(A)) → IDynamicCoordinates(A, x(A), y(A)) → JDynamicCoordinates(A, x(A), y(A)) → KDynamicCoordinates(A, x(A), y(A)) → LDynamicCoordinates(A, x(A), y(A)) → MDynamicCoordinates(A, x(A), y(A)) → NDynamicCoordinates(A, x(A), y(A)) → ODynamicCoordinates(A, x(A), y(A)) → PPolygon(Q, R, 4) → poly1, q, r, s, t, S, TPolygon(Q_1, R_1, 4) → poly1_1, q_1, r_1, s_1, t_1, S_1, T_1