
SSS Congruence of Triangles
Loading the math board and drawing, please wait…
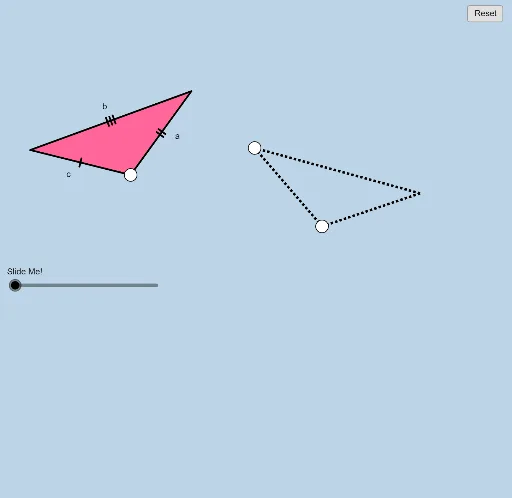
This example demonstrates the SSS (Side-Side-Side) congruence of triangles using GeoGebra. It covers key concepts like triangle congruence, geometric construction, and transformations. The construction involves commands such as Circle, Intersect, Segment, and Polygon to create and verify congruent triangles. Suitable for middle school students learning geometry congruence or for educational demonstrations.
GeoGebra Commands & Parameters
Circle(A, a) → d_1Intersect(d_1, e) → B, CCircle(C, b) → fSegment(A, C) → gCircle(A, c) → kIntersect(k, f) → F, G, ,Segment(C, F) → hSegment(F, A) → iPolygon(A, C, F) → poly1, f_1, a_1, c_1Circle(D, i) → pPoint(p) → ESegment(D, E) → nCircle(D, g) → qCircle(E, h) → rIntersect(q, r, 2) → HSegment(D, H) → sSegment(H, E) → tLine(A, n) → g_1Point(g_1) → IAngle(I, A, F) → αDilate(A, If[0 < o ≤ 1, 1 - o, 0], D) → A'Vector(A, A') → uTranslate(F, u) → F'Translate(A, u) → A'_1Segment(F', A'_1) → i'Rotate(F', If[1 < o ≤ 2, ((-(o - 1)) * α), (-α)], D) → F''Rotate(A'_1, If[1 < o ≤ 2, ((-(o - 1)) * α), (-α)], D) → JSegment(F'', J) → i''Dilate(A, If[2 < o ≤ 3, 3 - o, 0], D) → A'_2Vector(A, A'_2) → vTranslate(A, v) → A'_3Translate(C, v) → C'Segment(A'_3, C') → g'Line(D, g) → h_1Point(h_1) → KAngle(H, D, K) → βRotate(A'_3, If[3 < o ≤ 4, ((-(o - 3)) * β), (-β)], D) → LRotate(C', If[3 < o ≤ 4, ((-(o - 3)) * β), (-β)], D) → C''Segment(L, C'') → g''Line(C, t) → i_1Point(i_1) → MAngle(M, C, F) → γDilate(C, If[4 < o ≤ 5, 5 - o, 0], C'') → C'_1Vector(C, C'_1) → wTranslate(C, w) → C'_2Translate(F, w) → F'_1Segment(C'_2, F'_1) → h'Rotate(C'_2, If[5 < o ≤ 6, ((-(o - 5)) * γ), (-γ)], C'') → NRotate(F'_1, If[5 < o ≤ 6, ((-(o - 5)) * γ), (-γ)], C'') → OSegment(N, O) → h''Line(F, C) → j_1Mirror(A, j_1) → A'_6Mirror(C, j_1) → C'_4Mirror(F, j_1) → F'_3Polygon(A'_6, C'_4, F'_3) → poly1'_1, f'_3, a'_6, c'_4Point(j_1) → SPoint(j_1) → TRay(C'_4, T) → k_1Ray(F'_3, S) → l_1Segment(A'_6, F'_3) → m_1Segment(A'_6, C'_4) → n_1Dilate(F, If[0 < d ≤ 1, 1 - d, 0], E) → F'_2Vector(F, F'_2) → u_1Translate(A'_6, u_1) → PTranslate(C'_4, u_1) → QTranslate(F'_3, u_1) → RPolygon(P, Q, R) → poly2, r_1, p_1, q_1Translate(A'_6, u_1) → UTranslate(C'_4, u_1) → VSegment(U, V) → s_1Translate(A'_6, u_1) → WTranslate(F'_3, u_1) → ZSegment(W, Z) → t_1Translate(C, u_1) → C'_3Translate(F, u_1) → F'_4Segment(C'_3, F'_4) → h'_1Translate(A'_6, u_1) → A_1Translate(F'_3, u_1) → B_1Segment(A_1, B_1) → e_1Line(E, k_1) → f_2Point(f_2) → C_1Angle(C'', E, C_1) → δRotate(P, If[1 < d ≤ 2, ((-(d - 1)) * δ), (-δ)], E) → P'Rotate(Q, If[1 < d ≤ 2, ((-(d - 1)) * δ), (-δ)], E) → Q'Rotate(R, If[1 < d ≤ 2, ((-(d - 1)) * δ), (-δ)], E) → R'Polygon(P', Q', R') → poly2', r', p', q'Rotate(A_1, If[1 < d ≤ 2, ((-(d - 1)) * δ), (-δ)], E) → D_1Rotate(B_1, If[1 < d ≤ 2, ((-(d - 1)) * δ), (-δ)], E) → E_1Segment(D_1, E_1) → g_2Rotate(U, If[1 < d ≤ 2, ((-(d - 1)) * δ), (-δ)], E) → U'Rotate(V, If[1 < d ≤ 2, ((-(d - 1)) * δ), (-δ)], E) → V'Segment(U', V') → h_2Rotate(C'_3, If[1 < d ≤ 2, ((-(d - 1)) * δ), (-δ)], E) → F_1Rotate(F'_4, If[1 < d ≤ 2, ((-(d - 1)) * δ), (-δ)], E) → G_1Segment(F_1, G_1) → i_2Polygon(D, C'', E) → poly3, e_2, d_2, c''Dilate(D, If[2.5 < d ≤ 3.5, 3.5 - d, 0], D_1) → D'Segment(D, D') → j_2Segment(E, C'') → k_2Min(c, k_2 / 2) → o_1Circle(D, (0.3 * o_1)) → c_2Intersect(c_2, i'') → H_1,Intersect(c_2, j_2) → I_1,CircleSector(D, I_1, H_1) → p_2Intersect(j_2, k_2) → J_1Polygon(D, D_1, E) → poly4, e_3, d_3, d_4Dilate(D, If[3.5 < d ≤ 4.5, 4.5 - d, 0], D_1) → D'_1Vector(D, D'_1) → v_1Translate(p_2, v_1) → q_2Angle(E, D_1, D) → εRotate(q_2, If[4.5 < d ≤ 5.5, ((d - 4.5) * (π - ε)), π - ε], D_1) → r_2Intersect(c_2, g'') → K_1, L_1CircleSector(D, K_1, I_1) → s_2Polygon(D, C'', D_1) → poly5, d_5, d_6, c''_1Dilate(D, If[6 < d ≤ 7, 7 - d, 0], D_1) → D'_2Vector(D, D'_2) → w_1Translate(s_2, w_1) → t_2Angle(D, D_1, C'') → ζRotate(t_2, If[7 < d ≤ 8, ((-(d - 7)) * (π - ζ)), (-(π - ζ))], D_1) → c_3Dilate(E, If[8.5 < d ≤ 9.5, 9.5 - d, 0], C'') → E'Segment(E, E') → l_2Segment(E, C'') → m_2Polygon(A, C, F) → poly6, f_3, a_2, c_4Polygon(D, C'', E) → poly7, e_4, d_7, c''_2