
Shortest Path on a Sphere
Loading the math board and drawing, please wait…
In collections
GeoGebra 3D & AR: PreCalc & Calculus Resources
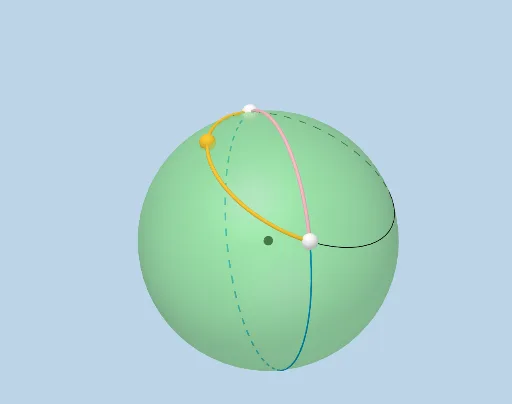
This example demonstrates the dynamic interactive investigation of the shortest path between two points on a sphere. Key mathematical concepts include spherical geometry and trigonometry. Using GeoGebra commands such as PointIn, CircleArc, and Sphere, the construction process is visually explained. Suitable for high school and above students or teachers.
GeoGebra Commands & Parameters
PointIn(b) → APointIn(b) → BCircleArc(C, B, A) → cPointIn(b) → DCircle(A, D, B) → dPlane(A, D, B) → eCenter(d) → EOrthogonalLine(E, e) → fCircleArc(E, A, B) → gLine(B, C) → hIntersect(h, b) → F, GCircle(B, A, G) → kPlane(A, B, C) → iDilate(B, If[0 < j ≤ 1, 1 - j, 0], C) → B'Vector(B, B') → uSphere(B, c) → lPlane((0, 0, 0), (1, 0, 0), (3, 2, 0)) → mIntersect(h, l) → H, ITranslate(B, u) → B'_1Rotate(i, π / 2, Line[H, I]) → i'OrthogonalLine(B, i') → nIntersect(n, l) → J, KDilate(B, If[0 < j ≤ 1, 1 - j, 0], J) → B'_2Vector(B, B'_2) → vTranslate(k, v) → k'Translate(C, v) → C'Translate(A, v) → A'Angle(A, C, B) → αRotate(A', If[0 < j ≤ 1, (j * α), α], C', i) → A''Segment(B, B'_2) → pCircleArc(C', A'', B'_2) → qSphere(B, g) → oRotate(A, π / 2, B, e) → C'_1Line(B, C'_1) → rIntersect(r, o) → L, MDilate(B, If[2 < j ≤ 3, 3 - j, 0], M) → B'_3Vector(B, B'_3) → wTranslate(d, w) → d'Translate(E, w) → E'Translate(A, w) → A'_1Angle(A'_1, E', B'_3) → βRotate(A'_1, If[2 < j ≤ 3, ((j - 2) * β), β], E', e) → NSegment(B, B'_3) → sCircleArc(E', N, B'_3) → tPlane(B, J, M) → a_1Angle(M, B, J) → γRotate(J, If[4 < j ≤ 5, ((j - 4) * γ), γ], B, a_1) → J'Segment(B, J') → f_1Angle(A, D, B) → δSphere(B, f_1) → b_1Intersect(s, b_1) → P, OSegment(O, M) → g_1IntersectPath(m, b) → c_1Plane(B, E, A) → d_1Line(A, B) → h_1OrthogonalLine(B, d_1) → i_1Point(i_1) → QPlane(A, B, Q) → e_1Mirror(B, e_1) → B'_4Mirror(B'_3, e_1) → RMirror(B, e_1) → B'_5Segment(P, M) → j_1
AI Drawing Prompt Reference
Draw two points on a sphere and then illustrate the shortest path between them. Start by defining the initial part of the path using circular arcs and circles on the sphere's surface. Then, construct the path by utilizing points and planes on the sphere. Finally, extend and adjust the path through rotation and translation operations to ensure it adheres to spherical geometry principles.
The prompt above was compiled from the original drawing commands and is for reference only.