
Short Sunderland Flying Boat Simulation: Rotation, Similarity & Circumcircle
Loading the math board and drawing, please wait…
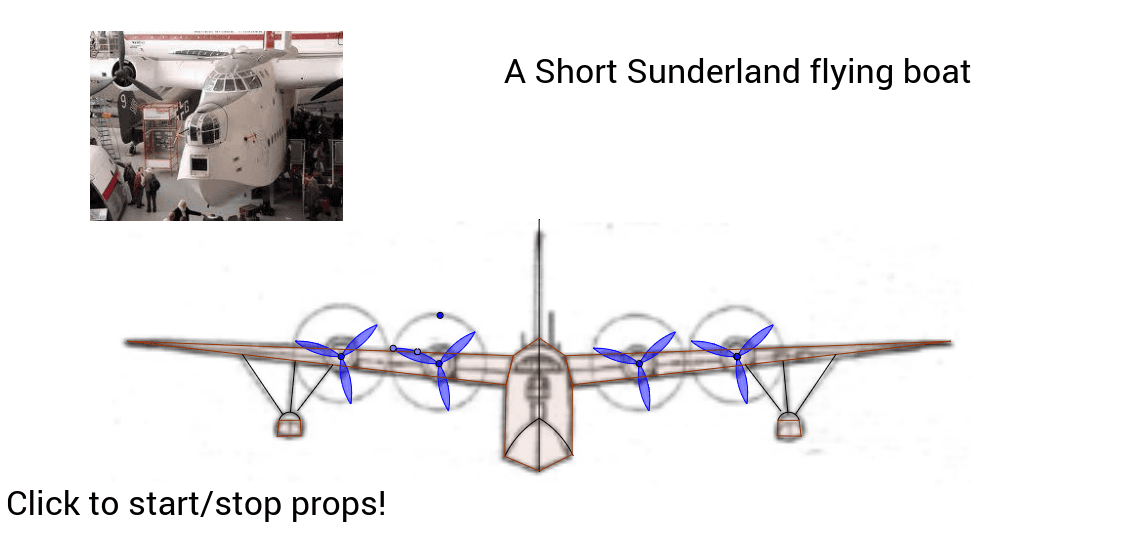
① This example builds a dynamic model of a Short Sunderland flying boat, demonstrating its rotation, translation, and similarity transformations in space. ② Core mathematical concepts include rotation transformations, similarity transformations, circumcircles, centroids (barycenters), and the use of random variables. ③ Construction highlights: the model employs GeoGebra commands such as Polygon, Segment, Mirror, Point, CircumcircleArc, Circle, LineBisector, Rotate, Vector, Translate, and Propellor, creating multiple points (A, B, C…), polygons (poly1, poly2), circles (c, c_1), vectors, and mirrored objects to animate the hull and propellers. ④ Suitable for high‑school geometry electives, university geometric modeling courses, and as a GeoGebra animation teaching resource.
GeoGebra Commands & Parameters
Polygon(C, D, E) → poly1, e, c, dSegment(F, G) → aMirror(C, a) → C'Mirror(D, a) → D'Mirror(E, a) → E'Polygon(C', D', E') → poly1', e', c', d'Point(a) → IPolygon(F, H, C, E, I, E', C', J) → poly2, f, h, c_1, e_1, i, e'_1, c'_1, jPoint(a) → KCircumcircleArc(H, L, K) → gMirror(H, a) → H'Mirror(L, a) → L'Mirror(K, a) → K'CircumcircleArc(H', L', K') → g'Polygon(M, N, O, P) → poly3, m, n, o, pCircumcircleArc(P, Q, O) → kMirror(M, a) → M'Mirror(N, a) → N'Mirror(O, a) → O'Mirror(P, a) → P'Polygon(M', N', O', P') → poly3', m', n', o', p'Mirror(P, a) → P'_1Mirror(Q, a) → Q'Mirror(O, a) → O'_1CircumcircleArc(P'_1, Q', O'_1) → k'Point(e) → RPoint(k) → SSegment(R, S) → bSegment(U, V) → lSegment(W, Z) → qMirror(F, l) → F'Mirror(R, a) → R'Mirror(S, a) → S'Segment(R', S') → b'Mirror(U, a) → U'Mirror(V, a) → V'Segment(U', V') → l'Mirror(W, a) → W'Mirror(Z, a) → Z'Segment(W', Z') → q'Circle(A_1, B_1) → rPoint(r) → C_1Segment(A_1, C_1) → sLineBisector(s) → tPoint(t) → D_1CircumcircleArc(C_1, D_1, A_1) → d_1Mirror(C_1, s) → E_1Mirror(D_1, s) → F_1Mirror(A_1, s) → G_1CircumcircleArc(E_1, F_1, G_1) → f_1Rotate(A_1, 240*°, A_1) → H_1Rotate(C_1, 240*°, A_1) → I_1Segment(H_1, I_1) → s'Rotate(H_1, 240*°, A_1) → J_1Rotate(I_1, 240*°, A_1) → K_1Segment(J_1, K_1) → s''Rotate(C_1, 240*°, A_1) → L_1Rotate(D_1, 240*°, A_1) → M_1Rotate(A_1, 240*°, A_1) → N_1CircumcircleArc(L_1, M_1, N_1) → g_1Rotate(E_1, 240*°, A_1) → O_1Rotate(F_1, 240*°, A_1) → P_1Rotate(G_1, 240*°, A_1) → Q_1CircumcircleArc(O_1, P_1, Q_1) → h_1Rotate(O_1, 240*°, A_1) → R_1Rotate(P_1, 240*°, A_1) → S_1Rotate(Q_1, 240*°, A_1) → T_1CircumcircleArc(R_1, S_1, T_1) → k_1Rotate(L_1, 240*°, A_1) → U_1Rotate(M_1, 240*°, A_1) → V_1Rotate(N_1, 240*°, A_1) → W_1CircumcircleArc(U_1, V_1, W_1) → p_1Vector(A_1, T) → uTranslate(B_1, u) → Z_1Translate(C_1, u) → A_2Translate(D_1, u) → B_2Propellor(T, Z_1, A_2, B_2) → q_1, r_1, s_1, t_1, c_2, d_2Mirror(A_1, a) → C_2Mirror(T, a) → T'Vector(A_1, C_2) → vVector(C_2, T') → wTranslate(B_1, v) → D_2Translate(C_1, v) → E_2Translate(D_1, v) → F_2Translate(C_1, v) → G_2Translate(D_1, v) → H_2Translate(A_1, v) → I_2CircumcircleArc(G_2, H_2, I_2) → e_2Translate(E_1, v) → J_2Translate(F_1, v) → K_2Translate(G_1, v) → L_2CircumcircleArc(J_2, K_2, L_2) → f_2Translate(R_1, v) → M_2Translate(S_1, v) → N_2Translate(T_1, v) → O_2CircumcircleArc(M_2, N_2, O_2) → g_2Translate(U_1, v) → P_2Translate(V_1, v) → Q_2Translate(W_1, v) → R_2CircumcircleArc(P_2, Q_2, R_2) → h_2Translate(L_1, v) → S_2Translate(M_1, v) → T_2Translate(N_1, v) → U_2CircumcircleArc(S_2, T_2, U_2) → k_2Translate(O_1, v) → V_2Translate(P_1, v) → W_2Translate(Q_1, v) → Z_2CircumcircleArc(V_2, W_2, Z_2) → p_2Translate(G_2, w) → A_3Translate(H_2, w) → B_3Translate(I_2, w) → C_3CircumcircleArc(A_3, B_3, C_3) → q_2Translate(J_2, w) → D_3Translate(K_2, w) → E_3Translate(L_2, w) → F_3CircumcircleArc(D_3, E_3, F_3) → r_2Translate(P_2, w) → G_3Translate(Q_2, w) → H_3Translate(R_2, w) → I_3CircumcircleArc(G_3, H_3, I_3) → s_2Translate(M_2, w) → J_3Translate(N_2, w) → K_3Translate(O_2, w) → L_3CircumcircleArc(J_3, K_3, L_3) → t_2Translate(S_2, w) → M_3Translate(T_2, w) → N_3Translate(U_2, w) → O_3CircumcircleArc(M_3, N_3, O_3) → c_3Translate(V_2, w) → P_3Translate(W_2, w) → Q_3Translate(Z_2, w) → R_3CircumcircleArc(P_3, Q_3, R_3) → d_3
AI Drawing Prompt Reference
Create a dynamic model of a Short Sunderland flying boat featuring a hull composed of polygonal shapes and their mirrored counterparts to show symmetry. Include propellers formed by multiple polygons and circular arcs, generated through rotation, translation, and similarity transformations. Add circumcircles and centroids to define key geometric points, and illustrate the relationship between the hull sections and propeller elements using arcs and circles. The drawing should convey the overall aircraft structure with its main body, twin floats, and rotating propellers, emphasizing the spatial transformations and geometric constructions that simulate the boat’s movement.
The prompt above was compiled from the original drawing commands and is for reference only.