
Pendulum Snake: Motion of Six Linked Pendulums
Loading the math board and drawing, please wait…
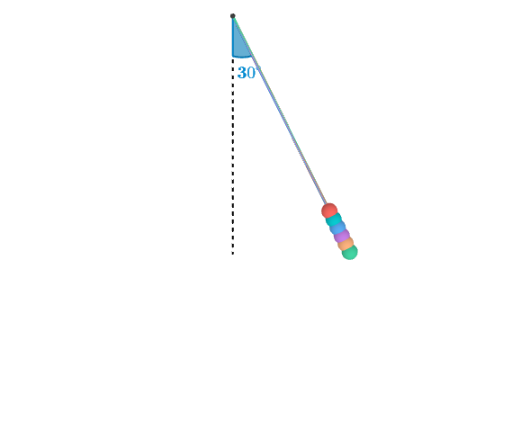
This example demonstrates how a chain of six linked pendulums evolves in time, producing a distinctive “snake-like” motion and the corresponding connected geometric trajectory of the joints/endpoints. The main mathematical ideas are angle parameterization (θ values across time), trigonometric relationships implied by the pendulum geometry, and visualization via successive geometric constructions. Construction highlights: it uses Intersect to compute joint/constraint intersection points, Rotate to swing each rod by its corresponding angle θ_i into the new configuration, and Segment to draw each pendulum bar; Max and Angle are used to determine key angle-related quantities. The model is built from objects such as pendulum lengths l1–l6, initial angle θ0, time parameter t, the sequence of angles θ1–θ6, and intermediate points like A and P10–P60 to locate each segment’s endpoint. Suitable for high-school to early university audiences for learning trigonometry-based modeling, parametric animation, and geometric construction techniques.
GeoGebra Commands & Parameters
Intersect(xAxis, yAxis) → ARotate(P_{10}, θ_{1}, A) → P_{1}Rotate(P_{20}, θ_{2}, A) → P_{2}Rotate(P_{30}, θ_{3}, A) → P_{3}Rotate(P_{40}, θ_{4}, A) → P_{4}Rotate(P_{50}, θ_{5}, A) → P_{5}Rotate(P_{60}, θ_{6}, A) → P_{6}Segment(A, P_{1}) → f_{1}Segment(A, P_{2}) → f_{2}Segment(A, P_{3}) → f_{3}Segment(A, P_{4}) → f_{4}Segment(A, P_{5}) → f_{5}Segment(A, P_{6}) → f_{6}Max({l_{1}, l_{2}, l_{3}, l_{4}, l_{5}, l_{6}}) → bigLSegment(A, A - (0, bigL)) → vertSegmAngle(A - (0, bigL), A, P_{5}) → startAng
AI Drawing Prompt Reference
Draw a chain of six connected pendulums radiating from a single fixed point, forming a snake-like structure with six joints. Each pendulum rod has a different length, and the entire configuration swings over time, demonstrating periodic angular changes and spatial motion trajectories that reveal the geometric relationships between the rods.
The prompt above was compiled from the original drawing commands and is for reference only.