
Parabolas in Sports: Tennis Service
Loading the math board and drawing, please wait…
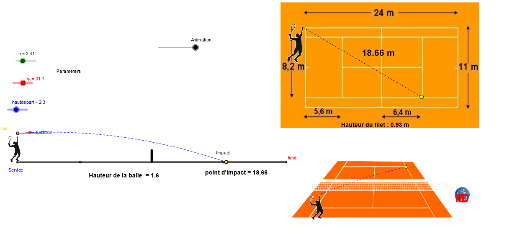
This example demonstrates the parabolic trajectory of a tennis ball during service, highlighting key mathematical concepts such as parabolas, coordinate geometry, vectors, and function graphing. It leverages GeoGebra commands like Line, Point, Segment, OrthogonalLine, Intersect, Polygon, Midpoint, Rotate, Angle, Function, Vector, Translate, If, Mirror, and CircumcircleArc to construct and analyze the parabolic path and related geometric elements. Suitable for high school students learning about parabolas and their applications in physical motion, or for mathematical modeling education.
GeoGebra Commands & Parameters
Line(S, xAxis) → n_1Line(F_1, xAxis) → mLine(M, m) → kPoint(m) → LLine(S, I_1) → tPoint(t) → D_1Line(I_1, xAxis) → sPoint(xAxis) → E_1Segment(Service, G) → aPoint(a) → FOrthogonalLine(F, a) → iPoint(i) → hautfiletSegment(F, hautfilet) → eLine(L, e) → nLine(F_1, n) → b_1Intersect(s, n) → C_1Polygon(D_1, E_1, C_1, I_1) → poly1, d_1, e_1, c_1, i_1Point(e_1) → K_1Midpoint(K_1, C_1) → S_1Midpoint(S_1, C_1) → U_1Line(U_1 + (0, 0.2), n_1) → q_1Line(K_1, q_1) → s_1Intersect(s_1, n) → A_2Line(K_1, k) → a_1Intersect(a_1, b_1) → P_1Intersect(n, k) → NIntersect(f, i) → Ballhaute, AIntersect(f, yAxis) → ballLine(ball, xAxis) → bIntersect(f, b) → B, EMidpoint(E, ball) → JMidpoint(ball, J) → HIntersect(f, xAxis) → C, ImpactRotate(E, α, ball) → E'Angle(E, ball, E') → βSegment(Service, G) → cPoint(xAxis) → fondSegment(G, fond) → dIntersect(e, xAxis) → DLine(hautfilet, D) → gFunction(f, 0, x(Impact)) → hRotate(H, α, ball) → J'Vector(ball, J') → uPoint(xAxis) → OSegment(fond, Service) → jSegment(W, Z) → lTranslate(W, (x(Impact) / 18.5 * Vector[W, Z])) → W'If(y(Ballhaute) ≟ y(hautfilet), 1, If[y(Ballhaute) < y(hautfilet), 2, 0]) → mmFunction(f, 0, x(hautfilet)) → pSegment(W, W') → qSegment(R, Q) → rLine(E_1, n) → f_1Intersect(f_1, a_1) → L_1Intersect(k, f_1) → M_1Intersect(f_1, m) → N_1Intersect(k, b_1) → O_1Polygon(N, A_2, P_1, M) → poly3, p_1, t_1, a_2, b_2Polygon(F_1, L, N, O_1) → poly2, g_1, h_1, j_1, k_1Polygon(N, A_2, P_1, M) → poly4, l_1, m_1, c_2, d_2Midpoint(d_1) → Q_1Midpoint(c_1) → R_1Midpoint(i_1) → T_1Midpoint(Q_1, R_1) → V_1Intersect(n_1, e_1) → W_1Midpoint(S, W_1) → Z_1Line(Q_1, R_1) → r_1Segment(Z_1, V_1) → e_2Intersect(r_1, q_1) → B_2Intersect(i_1, q_1) → C_2Line(B_2, xAxis) → f_2Intersect(e_1, f_2) → D_2Segment(C_2, D_2) → g_2Segment(V_1, B_2) → h_2Segment(W_1, S) → i_2Midpoint(Q_1, E_1) → E_2Midpoint(E_2, E_1) → F_2Midpoint(D_1, Q_1) → G_2Midpoint(D_1, G_2) → H_2Segment(H_2, J_1) → k_2Mirror(H_2, J_1) → I_2Mirror(J_1, J_1) → J_2Segment(I_2, J_2) → l_2Mirror(J_1, R_1) → K_2Segment(F_2, K_2) → j_2Intersect(g_2, k_2) → L_2Intersect(i_2, k_2) → M_2Intersect(j_2, i_2) → N_2Intersect(g_2, j_2) → O_2Segment(Z_1, N_2) → m_2Segment(Z_1, M_2) → n_2Segment(L_2, O_2) → p_2CircumcircleArc(Q, R, P_2) → q_2Segment(Q_2, R_2) → r_2Intersect(l, r_2) → S_2Segment(Q, P_2) → s_2Translate(Q, (x(Impact) / 18.5 * Vector[Q, P_2])) → Q'CircumcircleArc(Q', R, Q) → t_2Midpoint(q) → T_2Vector(W, W') → vVector(Q, Q') → wTranslate(W, (Animation / x(Impact) * v)) → W'_1Segment(W, W'_1) → a_3Translate(Q, (Animation / x(Impact) * w)) → Q'_1