
Net of a Square Pyramid by GeoGebra Materials Team
Loading the math board and drawing, please wait…
In collections
Area, Surface Area, Volume--Nets
Area and Surface Area
Area and Surface Area
Nets of Solids
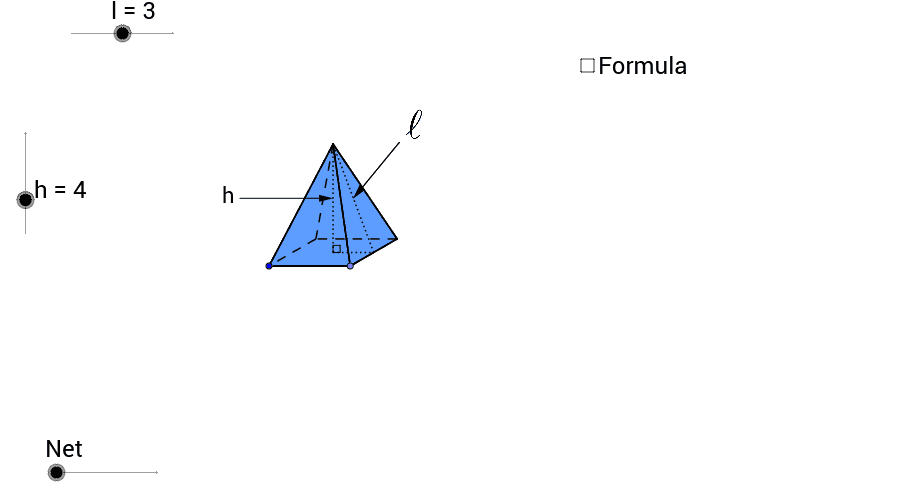
This example demonstrates the net of a square pyramid and shows its geometric transformations through animation. Key mathematical concepts include the net and rotation in solid geometry. It uses GeoGebra commands such as Point, Segment, Line, Circle, Intersect, Rotate, Polygon, etc. Suitable for middle school and above students learning solid geometry.
GeoGebra Commands & Parameters
Point(Circle[A, l]) → BSegment(A, B) → aLine(A, B) → b_2Circle(B, 3.0 * l / 4.5) → cIntersect(c, b_2, 2.0) → CRotate(C, 30.0*°, B) → C'Line(C', b_2) → dSegment(B, C') → eLine(A, e) → fIntersect(d, f) → DPolygon(A, B, C', D) → poly1, a_1, b_1, c', d_1Segment(A, C') → gSegment(D, B) → h_1Intersect(g, h_1) → EOrthogonalLine(E, a_1) → iCircle(E, h) → kIntersect(k, i, 2.0) → FSegment(B, F) → jSegment(C', F) → l_5Segment(F, D) → mSegment(F, A) → nSegment(E, F) → pSegment(A, D) → qMidpoint(b_1) → GSegment(G, F) → rAngle(G, E, F) → αSegment(E, G) → tLine(E, G) → c_1Circle(G, F) → f_1Intersect(f_1, c_1, 2.0) → HIntersect(c_1, d_1) → ICircle(I, F) → g_1Intersect(g_1, c_1, 1.0) → JVector(F, J) → uPoint(c') → LCircle(L, F) → q_1Vector(F, H) → wMidpoint(A, B) → KLine(K, E) → e_1Circle(K, h) → p_1Intersect(e_1, c') → MCircle(M, h) → r_1Intersect(r_1, e_1, 2.0) → NIntersect(p_1, e_1, 1.0) → OVector(F, N) → vVector(F, O) → zTranslate(F, Vector[z * o]) → F'_1Translate(F, Vector[u * (o - 1.0)]) → F'_2Translate(F, Vector[v * (o - 2.0)]) → F'_3Translate(F, Vector[w * (o - 3.0)]) → F'Segment(F, N) → sLineBisector(s) → a_2Intersect(a_2, c') → PCircleArc(P, N, F) → c_2Ray(P, F'_3) → d_2Intersect(c_2, d_2, 1.0) → QSegment(F, O) → e_2LineBisector(e_2) → f_2Intersect(f_2, a_1) → RCircleArc(R, F, O) → g_2Ray(R, F'_1) → h_2Intersect(g_2, h_2, 1.0) → SCircleArc(I, F, J) → k_2CircleArc(G, H, F) → p_2Ray(I, F'_2) → i_2Intersect(k_2, i_2, 1.0) → TRay(G, F') → j_2Intersect(p_2, j_2, 1.0) → UCircle(I, E) → s_1OrthogonalLine(I, a_1) → i_1Intersect(s_1, i_1, 2.0) → VIntersect(s_1, i_1, 1.0) → WOrthogonalLine(V, i_1) → j_1OrthogonalLine(W, i_1) → k_1OrthogonalLine(G, k_1) → l_1Intersect(j_1, l_1) → ZIntersect(k_1, l_1) → A_1Midpoint(V, Z) → B_1Midpoint(A_1, W) → C_1Circle(B_1, r) → t_1Circle(C_1, r) → q_2OrthogonalLine(B_1, k_1) → m_1Intersect(t_1, m_1, 1.0) → D_1Intersect(q_2, m_1, 2.0) → E_1Vector(C', Z) → u_1Vector(B, A_1) → v_1Vector(N, D_1) → w_1Vector(O, E_1) → z_1Translate(N, Vector[w_1 * (o - 4.0)]) → N'Translate(O, Vector[z_1 * (o - 4.0)]) → O'Translate(B, Vector[v_1 * (o - 4.0)]) → B'Translate(A, Vector[v_1 * (o - 4.0)]) → A'Translate(C', Vector[u_1 * (o - 4.0)]) → C''Translate(D, Vector[u_1 * (o - 4.0)]) → D'If(o < 1.0, S, If[o < 4.0, O, If[o < 5.0, O', E_1]]) → F_1If(o < 1.0, F, If[o < 2.0, T, J]) → G_1If(o < 3.0, F, If[o < 4.0, U, H]) → H_1If(o < 2.0, F, If[o < 3.0, Q, If[o < 4.0, N, If[o < 5.0, N', D_1]]]) → I_1If(o < 4.0, A, If[o < 5.0, A', W]) → J_1If(o < 4.0, B, If[o < 5.0, B', A_1]) → K_1If(o < 4.0, C', If[o < 5.0, C'', Z]) → L_1If(o < 4.0, D, If[o < 5.0, D', V]) → M_1Polygon(F_1, J_1, K_1) → poly2, k_3, f_3, j_3Polygon(L_1, H_1, K_1) → poly3, k_4, l_2, h_3Polygon(L_1, I_1, M_1) → poly4, m_2, l_3, i_3Polygon(M_1, G_1, J_1) → poly5, j_4, m_3, g_3Intersect(m, j_3) → N_1Segment(I_1, N_1) → n_1Intersect(j_3, i_3) → O_1Intersect(c', i_3) → Q_1Intersect(c', i_3) → R_1Intersect(c', i_3) → S_1Intersect(c', i_3) → U_1Intersect(c', i_3) → A_2Intersect(l_2, i_3) → B_2Segment(B_2, O_1) → n_2Segment(B_2, M_1) → r_2Midpoint(M_1, L_1) → C_2Midpoint(L_1, K_1) → D_2Midpoint(K_1, J_1) → E_2Midpoint(J_1, M_1) → F_2Segment(G_1, F_2) → s_2Segment(C_2, I_1) → t_2Segment(D_2, H_1) → a_3Segment(E_2, F_1) → b_3Polygon(J_1, M_1, L_1, K_1) → poly6, j_5, m_4, l_4, k_5Intersect(j_3, d_1) → P_1Segment(P_1, M_1) → c_3Midpoint(p) → V_1OrthogonalLine(V_1, p) → d_3Point(d_3) → W_1Vector(W_1, V_1) → u_2Midpoint(r) → T_1Midpoint(a_3) → Z_1Point(a_2) → G_2Vector(G_2, T_1) → v_2Vector(G_2, Z_1) → w_2Point(Circle[H_2, l]) → I_2Segment(H_2, I_2) → e_3Line(H_2, I_2) → bCircle(I_2, 3.0 * l / 4.5) → p_3Intersect(p_3, b, 2.0) → J_2Rotate(J_2, 30.0*°, I_2) → K_2Segment(I_2, K_2) → n_3Line(K_2, b) → q_3Line(H_2, n_3) → r_3Intersect(q_3, r_3) → L_2Segment(H_2, K_2) → s_3Segment(I_2, L_2) → t_3Intersect(s_3, t_3) → M_2Circle(M_2, h) → c_4OrthogonalLine(M_2, b) → a_4Intersect(c_4, a_4, 2.0) → N_2Polygon(H_2, N_2, I_2) → poly7, i_4, h_4, n_4Polygon(I_2, N_2, K_2) → poly8, k_6, i_5, n_5Polygon(H_2, L_2, K_2, I_2) → poly9, h_5, l_6, k_7, i_6Polygon(H_2, N_2, L_2) → poly10, l_7, h_6, n_6Polygon(L_2, N_2, K_2) → poly11, k_8, l_8, n_7Midpoint(k_7) → O_2Segment(M_2, O_2) → b_4Segment(M_2, N_2) → d_4Segment(N_2, O_2) → e_4Angle(O_2, M_2, N_2) → βMidpoint(N_2, M_2) → P_2Midpoint(O_2, N_2) → Q_2Line(P_2, Q_2) → f_4Circle(P_2, l) → g_4Intersect(g_4, f_4, 1.0) → R_2Intersect(g_4, f_4, 2.0) → S_2Vector(R_2, P_2) → z_2Vector(S_2, Q_2) → u_3Midpoint(b_3) → V_2