
Geometric Transformations Animation
Loading the math board and drawing, please wait…
In collections
CCSS High School: Geometry (Congruence) Volume 2
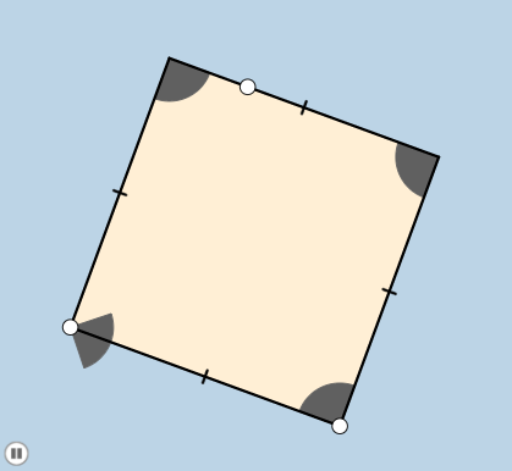
This example demonstrates geometric transformations involving squares, equilateral triangles, and circles through animation. Key math concepts include geometric constructions, similarity transformations, vector operations, and coordinate geometry. It utilizes commands like Polygon, Dilate, Rotate, Circle, Intersect, Vector, and Translate. Suitable for high school and above students learning transformations, vectors, and coordinate geometry, or for mathematical education demonstrations.
GeoGebra Commands & Parameters
Polygon(A, B, 4) → poly1, a, b, c, d, C, DDilate(A, If[0 < e ≤ 1, 1 - e, 0], B) → A'Segment(A, A') → fRotate(A, If[1 < e ≤ 2, ((-(e - 1)) * π / 2), -1.5707963267948966], B) → A'_1Rotate(A', If[1 < e ≤ 2, ((-(e - 1)) * π / 2), -1.5707963267948966], B) → A''Segment(A'_1, A'') → f'Segment(A, B) → gSegment(B, C) → hSegment(C, D) → iSegment(D, A) → jCircle(C, (0.15 * j)) → kCircle(B, (0.15 * j)) → pCircle(A, (0.15 * j)) → qCircle(D, (0.15 * j)) → rSegment(A, C) → lSegment(D, B) → mIntersect(r, j, 1) → FIntersect(r, m, 1) → GIntersect(r, i, 1) → HIntersect(k, i, 1) → IIntersect(k, l, 1) → JIntersect(k, h, 1) → KIntersect(p, h, 1) → LIntersect(p, m, 1) → MIntersect(p, g, 1) → NIntersect(q, g, 1) → OIntersect(q, l, 1) → PIntersect(q, j, 1) → QRotate(A'_1, If[2 < e ≤ 3, ((-(e - 2)) * π / 2), -1.5707963267948966], C) → RRotate(A'', If[2 < e ≤ 3, ((-(e - 2)) * π / 2), -1.5707963267948966], C) → A'''Segment(R, A''') → f''CircleSector(B, L, N) → sRotate(R, If[3 < e ≤ 4, ((-(e - 3)) * π / 2), -1.5707963267948966], D) → R'Rotate(A''', If[3 < e ≤ 4, ((-(e - 3)) * π / 2), -1.5707963267948966], D) → SSegment(R', S) → f'''Dilate(B, If[4 < e ≤ 5, 5 - e, 0], C) → B'Vector(B, B') → uTranslate(s, u) → s'Rotate(s', If[5 < e ≤ 6, ((e - 5) * π / 2), 1.5707963267948966], C) → s''Dilate(C, If[6 < e ≤ 7, 7 - e, 0], D) → C'Vector(C, C') → vTranslate(s'', v) → s'''Rotate(s''', If[7 < e ≤ 8, ((e - 7) * π / 2), 1.5707963267948966], D) → tDilate(D, If[8 < e ≤ 9, 9 - e, 0], A) → D'Vector(D, D') → wTranslate(t, w) → t'Rotate(t', If[9 < e ≤ 10, ((e - 9) * π / 2), 1.5707963267948966], A) → t''Dilate(B, If[18 < e ≤ 19, 19 - e, 0], C) → B'_1Dilate(B, If[18 < e ≤ 19, 19 - e, 0], A) → B'_2Dilate(B, If[18 < e ≤ 19, 19 - e, 0], D) → B'_3Vector(B, B'_1) → v_1Vector(B, B'_3) → w_1Vector(B, B'_2) → i_1Point(f'') → VSegment(A, V) → nAngle(B, A, V) → αRotate(B, α / 2, A) → B'_4Angle(B, A, B'_4) → βRay(A, B'_4) → j_1Intersect(f', j_1) → WSegment(A, W) → l_1Intersect(q, l_1) → A_1,Dilate(A, If[13 < e ≤ 14, 14 - e, 0], W) → A'_3Segment(A, A'_3) → m_1Segment(A''', V) → n_1Circle(V, n_1) → d_1Intersect(d_1, n, 1) → B_1Intersect(q, n, 1) → ECircleSector(A, A_1, E) → c_1Dilate(A, If[11 < e ≤ 12, 12 - e, 0], B_1) → A'_2Segment(A, A'_2) → f_1Dilate(B_1, If[12 < e ≤ 13, 13 - e, 0], V) → USegment(B_1, U) → g_1Rotate(c_1, If[14.5 < e ≤ 15.5, ((-(e - 14.5)) * β), (-β)], A) → e_1Dilate(A''', If[15.5 < e ≤ 16.5, 16.5 - e, 0], V) → TDilate(B, If[15.5 < e ≤ 16.5, 16.5 - e, 0], W) → B'_5Segment(A''', T) → a_1Segment(B, B'_5) → b_1Rotate(A''', If[17 < e ≤ 18, ((2 * (e - 17)) * β), (2 * β)], V) → ZRotate(T, If[17 < e ≤ 18, ((2 * (e - 17)) * β), (2 * β)], V) → T'Segment(Z, T') → h_1Line(B, f_1) → k_1Circle(B, W) → p_1Intersect(p_1, k_1, 2) → C_1Angle(C_1, B, W) → γRotate(B, If[18 < e ≤ 19, ((-(e - 18)) * γ), (-γ)], B) → B'_6Rotate(B'_5, If[18 < e ≤ 19, ((-(e - 18)) * γ), (-γ)], B) → D_1Segment(B'_6, D_1) → q_1Dilate(B, If[19 < e ≤ 20, 20 - e, 0], A) → B'_7Vector(B, B'_7) → u_1Translate(B'_6, u_1) → E_1Translate(D_1, u_1) → F_1Segment(E_1, F_1) → r_1