
Dynamic Geometry Exploration of 3D Vectors and Angles (Q5)
Loading the math board and drawing, please wait…
In collections
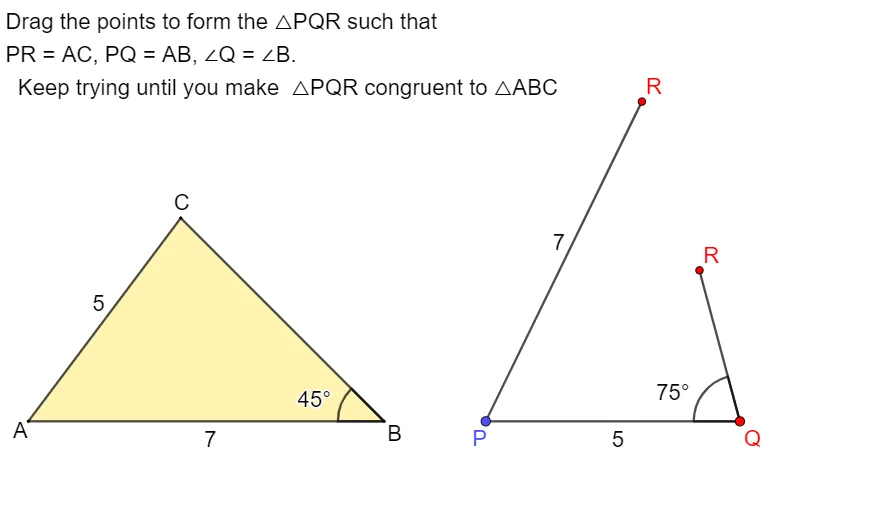
Exploring the Conditions for Congruence of 2 Triangles
This GeoGebra example constructs a comprehensive geometric model combining 3D vectors, 2D vectors, angles, roots, and calculus elements, demonstrating dynamic relationships in vector representation, translation, intersection, and angle calculation. Core mathematical concepts include vector operations (addition, translation), vector angles, closed polygonal paths, and generation of point sequences using dynamic coordinates. The construction uses commands such as Point, Vector, Sequence, DynamicCoordinates, Segment, Intersect, Polygon, If, and Angle, creating multiple points (A, B, C1, C, C', D, E, F), vectors (u, v, uCopy, vCopy), polygons (closed1, closed2), and angles (α, β) with interactive sliders or dynamic coordinates. Suitable for high school to undergraduate students studying 3D vectors, analytic geometry, and introductory calculus, and useful for teachers demonstrating vector operations and geometric intuition in the classroom.
GeoGebra Commands & Parameters
Point(Sequence[A + (i, 0), i, 1, 20, 1]) → BVector(A, C1) → uSequence(A + (i * UnitVector[Segment[A, C1]]), i, 1, 20, 1) → UPointsDynamicCoordinates(C1, x(ClosestPoint[UPoints, C1]), y(ClosestPoint[UPoints, C1])) → CVector(B, C2) → vSequence((x(B) + (Length[v] * cos(t°)), y(B) + (Length[v] * sin(t°))), t, 0, 355, 5) → VPointsDynamicCoordinates(C2, x(ClosestPoint[VPoints, C2]), y(ClosestPoint[VPoints, C2])) → C'Segment(A, C) → fIntersect(Circle[A, f], Line[B, C']) → G, G'Segment(A, B) → gSegment(C', B) → hPolygon(A, B, G) → t1, g_1, a, bPolygon(A, B, G') → t2, i, j, kIf(C ≟ G ∧ C' ≟ G, true, false) → closed1If(C ≟ G' ∧ C' ≟ G', true, false) → closed2Angle(C', B, A) → αIntersect(Circle[D, 5], Ray[E, Rotate[D, (-(45°)), E]], 2) → FPolygon(D, E, F) → t3, f_1, d_1, eAngle(F, E, D) → β
AI Drawing Prompt Reference
Draw a 3D vector model with points A and C1, vector u from A to C1, dynamically generate point C as the projection of C1 on u, vector v from B to C2, dynamically generate point C' as the trajectory of C2 on v, line segment AB and AC, intersection point G, polygons t1 and t2, angle α, points D, E, and F, and vector β.
The prompt above was compiled from the original drawing commands and is for reference only.