
Calculating Rotation Matrix using SVD
Loading the math board and drawing, please wait…
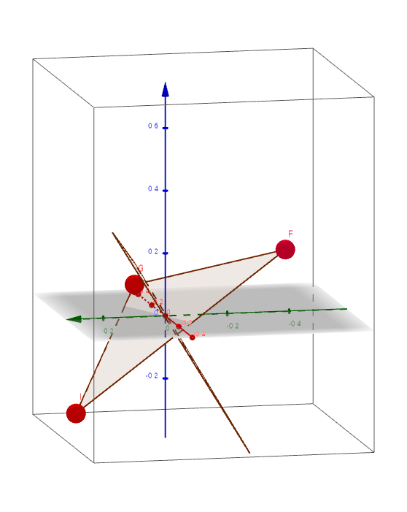
This example demonstrates how to calculate the rotation matrix for an unknown rigid body rotation using Singular Value Decomposition (SVD). It illustrates the relationship between the point set before and after rotation and the construction of the matrix. Key mathematical concepts include SVD, rotation matrix, vectors, and geometric transformations. GeoGebra commands and objects used in the construction include Rotate, SVD, Polygon, LaTeX, points A, B, C, their rotated versions A', B', C', related vectors, medians, norms, and matrices. Suitable for high school students and above to learn about the application of matrices in geometric transformations.
GeoGebra Commands & Parameters
Rotate(Rotate[Rotate[A, α, xAxis], β, yAxis], γ, zAxis) → A'Rotate(Rotate[Rotate[B, α, xAxis], β, yAxis], γ, zAxis) → B'Rotate(Rotate[Rotate[C, α, xAxis], β, yAxis], γ, zAxis) → C'SVD(H) → svdPolygon(Anorm, Bnorm, Cnorm) → poly1, cnorm, anorm, bnormPolygon(A'norm, B'norm, C'norm) → poly2, c'norm, a'norm, b'normLaTeX(R) → text4