
Animation Demonstrating Inequalities and Geometric Transformations
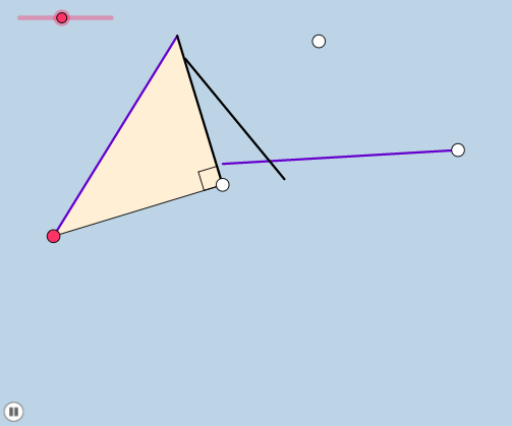
Loading the math board and drawing, please wait…
In collections
Congruence (CO) Cluster
Geometry Review
CCSS High School: Geometry (Congruence) Volume 1
Unit 5: Triangle Congruence
This example dynamically illustrates the application of inequalities and geometric transformations in plane figures. It involves core concepts like inequalities, straight lines, polygons, means, vectors, and transformations. Key GeoGebra commands used include Line, Segment, Circle, Intersect, Rotate, Angle, Polygon, Vector, and Translate to construct and manipulate shapes. Suitable for high school mathematics students and educators to understand the dynamic relationship between geometric transformations and inequalities.
GeoGebra Commands & Parameters
Line(A, B) → fSegment(A, B) → gOrthogonalLine(B, g) → hCircle(B, 1) → cIntersect(c, h, 2) → CRay(B, C) → iRotate(B, (a * π / 180), A) → B'Angle(B, A, B') → αRay(A, B') → jIntersect(h, j) → DSegment(A, D) → kSegment(D, B) → lAngle(D, B, A) → βCircle(E, g) → dPoint(d) → FSegment(E, F) → mOrthogonalLine(F, m) → nCircle(F, l) → eIntersect(e, n, 2) → GSegment(F, G) → pSegment(G, E) → qPolygon(A, B, D) → poly1, d_1, a_1, bDilate(A, If[0 < o ≤ 1, 1 - o, 0], D) → A'Segment(A, A') → rDilate(D, If[1 < o ≤ 2, 2 - o, 0], B) → D'Segment(D, D') → sLine(A, q) → tPoint(t) → HAngle(D, A, H) → γDilate(D, If[3 < o ≤ 4, 4 - o, 0], G) → D'_1Vector(D, D'_1) → uTranslate(A, u) → A'_1Translate(A', u) → A''Segment(A'_1, A'') → r'Rotate(A'_1, If[3 < o ≤ 4, ((o - 3) * γ), γ], A'') → IRotate(A'', If[3 < o ≤ 4, ((o - 3) * γ), γ], A'') → A'''Segment(I, A''') → r''Line(D, p) → f_1Point(f_1) → JAngle(B, D, J) → δDilate(D, If[4 < o ≤ 5, 5 - o, 0], G) → D'_2Vector(D, D'_2) → vTranslate(D, v) → D'_3Translate(D', v) → D''Segment(D'_3, D'') → s'Rotate(D'_3, If[4 < o ≤ 5, ((o - 4) * δ), δ], D'_3) → KRotate(D'', If[4 < o ≤ 5, ((o - 4) * δ), δ], D'_3) → D'''Segment(K, D''') → s''Segment(E, F) → g_1Angle(G, F, E) → εDilate(D, If[6 < o ≤ 7, 7 - o, 0], G) → D'_4Vector(D, D'_4) → wTranslate(A, w) → A'_2Translate(B, w) → B'_1Translate(D, w) → D'_5Polygon(A'_2, B'_1, D'_5) → poly1', d'_5, a'_2, b'_1Rotate(A'_2, If[7 < o ≤ 8, ((o - 7) * γ), γ], G) → LRotate(B'_1, If[7 < o ≤ 8, ((o - 7) * γ), γ], G) → MRotate(D'_5, If[7 < o ≤ 8, ((o - 7) * γ), γ], G) → NPolygon(L, M, N) → poly1'', n_1, l_1, m_1Segment(A, B) → h_1