
Animation 137: Geometric Transformations and Polygon Demonstration
Loading the math board and drawing, please wait…
In collections
Congruence (CO) Cluster
Congruence (Vol 1)
Geometry Review
Congruence (Vol 1) Over 80 Resources
Geometry (Congruence) Volume 1
CCSS High School: Geometry (Congruence) Volume 1 S N ATTAR
CCSS High School: Geometry (Congruence) Volume 1
CCSS High School: Geometry (Congruence) Volume 1
CCSS High School: Geometry (Congruence) Volume 1
CCSS High School: Geometry (Congruence) Volume 1
CCSS High School: Geometry (Congruence) Volume 1
CCSS High School: Geometry (Congruence) Volume 1
CCSS High School: Geometry (Congruence) Volume 1
CCSS High School: Geometry (Congruence) Volume 1
CCSS High School: Geometry (Congruence) Volume 1
CCSS High School: Geometry (Congruence) Volume 1
CCSS High School: Geometry (Congruence) Volume 1
Unit 5: Triangle Congruence
Triangle Congruence Theorems 1
Triangle Congruence Book 1
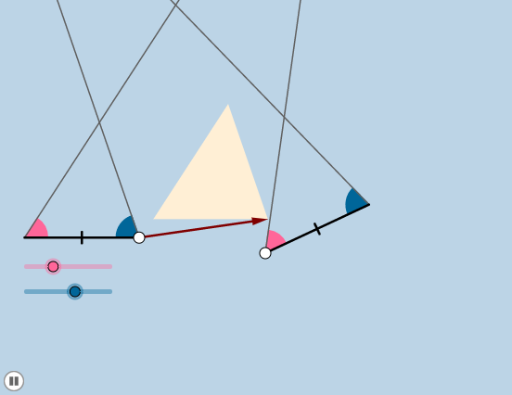
This example demonstrates transformations of a cuboid, polygons, and parabola graphs through animation. Core math concepts include vector translation, rotation, polygon construction, function graphing, and parametric equations. Key GeoGebra commands used are Rotate, Vector, Translate, Polygon, and Line as per the construction summary. Suitable for high school and above, ideal for teaching solid geometry, coordinate geometry, and function graphs.
GeoGebra Commands & Parameters
Rotate(B, α, A) → B'Angle(B, A, B') → βRay(A, B') → fPoint(f) → CRotate(A, (-γ), B) → A'Angle(A', B, A) → δRay(B, A') → gIntersect(f, g) → DPolygon(A, B, D) → poly1, d, a_1, bSegment(A, B) → hSegment(D, B) → iSegment(D, A) → jMin({h, i, j}) → cCircle(A, (0.2 * c)) → eCircle(B, (0.2 * c)) → kIntersect(e, h) → E,Intersect(e, j) → F, IIntersect(k, h) → G,Intersect(k, i) → H, JCircleSector(A, E, F) → pCircleSector(B, H, G) → qRotate(K, β, L) → K'Angle(K, L, K') → εCircle(L, h) → rRay(L, K) → mIntersect(r, m, 1) → MRay(L, K') → nRotate(L, (-γ), M) → L'Angle(L', M, L) → ζRay(M, L') → sIntersect(n, s) → NDilate(A, If[0 < l ≤ 1, 1 - l, 0], L) → A'_1Vector(A, A'_1) → uTranslate(p, u) → p'Line(L, h) → tTranslate(F, u) → F'Point(t) → OAngle(M, L, O) → ηRotate(p', If[1 < l ≤ 2, ((-(l - 1)) * η), (-η)], L) → p''Point(t) → PAngle(P, L, M) → θDilate(B, If[2 < l ≤ 3, 3 - l, 0], L) → B'_1Vector(B, B'_1) → vTranslate(A, v) → A'_2Translate(B, v) → B'_2Segment(A'_2, B'_2) → h'Rotate(A'_2, If[3 < l ≤ 4, ((l - 3) * θ), θ], L) → QRotate(B'_2, If[3 < l ≤ 4, ((l - 3) * θ), θ], L) → RSegment(Q, R) → h''Dilate(B, If[4 < l ≤ 5, 5 - l, 0], M) → B'_3Vector(B, B'_3) → wTranslate(q, w) → q'Line(M, g) → f_1Point(f_1) → SAngle(N, M, S) → τRotate(q', If[5 < l ≤ 6, ((l - 5) * ((2 * π) - τ)), (2 * π) - τ], M) → q''Dilate(B, If[6 < l ≤ 7, 7 - l, 0], M) → B'_4Vector(B, B'_4) → u_1Translate(A, u_1) → A'_3Translate(B, u_1) → B'_5Translate(D, u_1) → D'Polygon(A'_3, B'_5, D') → poly1', d', a'_3, b'_5Rotate(A'_3, If[7 < l ≤ 8, ((-(l - 7)) * τ), (-τ)], M) → TRotate(B'_5, If[7 < l ≤ 8, ((-(l - 7)) * τ), (-τ)], M) → URotate(D', If[7 < l ≤ 8, ((-(l - 7)) * τ), (-τ)], M) → D''Polygon(T, U, D'') → poly1'', d'', t_1, u_2