
3D Bike Model
Loading the math board and drawing, please wait…
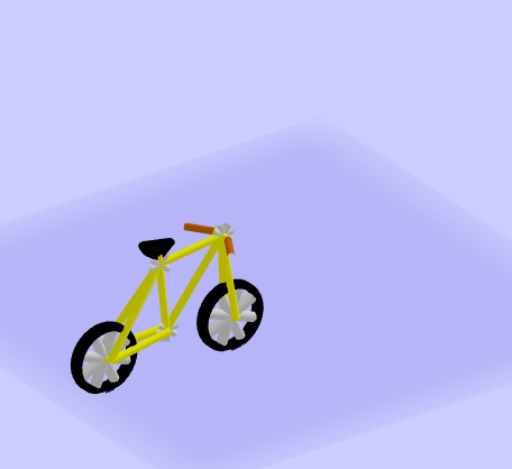
This example demonstrates the construction of a bike model in three-dimensional space, inspired by the 4D Frame manipulative. It involves core math concepts like vectors, trigonometry, coordinate geometry, and solid geometry. Construction highlights include commands like Line, Vector, Circle, Translate, and Rotate from GeoGebra. Suitable for high school students and educators.
GeoGebra Commands & Parameters
Line(D, yAxis) → iOrthogonalLine(D, yAxis, space) → bIntersect(i, b) → SCircle(I, (0.3 * r), yAxis) → ePlane(e) → jLine(I, G) → cOrthogonalLine(I, c, j) → lIntersect(l, e) → O, PLine(I, O) → q_1Intersect(xAxis, q_1) → TVector(T, I) → u_1Circle(I, r, u_1) → p_2Vector(S, T) → vCircle(D, (0.25 * r), zAxis) → hIntersect(i, h) → B, FTranslate(F, v) → F'_1Translate(F'_1, u_1) → E_2Midpoint(I, E_2) → G_2Circle(D, E, space) → fCircle(D, (0.8 * r), yAxis) → gIntersect(xAxis, zAxis) → CPolygon(F, G, A) → poly1, a_1, f_1, g_1Polygon(A, H, G) → poly2, g_2, a_2, h_1Polygon(I, A, G) → poly3, g_3, i_1, a_3Intersect(i, g_1) → JPlane(F, G, A) → dPlane(e) → kIntersect(c, e) → K, LAngularBisector(l, c) → m, nIntersect(m, e) → M, NIntersect(n, e) → Q, RSegment(R, Q) → pSegment(P, O) → qSegment(M, N) → sSegment(K, L) → tSegment(K, L) → b_1Line(G, q_1) → c_1Line(I, M) → d_1Vector(S, A) → uSegment(B, F) → e_1Translate(g, v) → g'Translate(B, u) → B'Translate(F, u) → F'Segment(B', F') → j_1Midpoint(A, F') → UMidpoint(B', A) → VSegment(F, U) → k_1Segment(V, B) → l_1Plane(A, G, F) → oCircle(G, (0.3 * r), o) → p_1Intersect(a_1, p_1) → W, ZIntersect(c_1, f_1) → A_1Intersect(c_1, f_1) → B_1Intersect(c_1, f_1) → C_1Intersect(c_1, p_1) → D_1, E_1Rotate(E_1, 45°, G, o) → F_1Rotate(F_1, 45°, G, o) → G_1Rotate(D_1, 45°, G, o) → H_1Rotate(H_1, 45°, G, o) → I_1Rotate(I_1, 45°, G, o) → J_1Segment(F_1, H_1) → m_1Segment(E_1, D_1) → n_1Segment(G_1, G) → r_1Segment(J_1, Z) → s_1Translate(B, v) → B'_1Segment(B'_1, F'_1) → b_2Segment(I, B'_1) → t_1Segment(I, F'_1) → c_2Plane(B'_1, I, K) → wCircle(I, (0.3 * r), w) → d_2Point(t) → K_1Point(t) → L_1Intersect(t_1, d_2) → O_1,Intersect(a_3, d_2) → P_1, Q_1Rotate(O_1, (-(45°)), I, w) → R_1Rotate(Q_1, (-(45°)), I, w) → S_1Rotate(S_1, (-(45°)), I, w) → T_1Rotate(T_1, (-(45°)), I, w) → U_1Rotate(U_1, (-(45°)), I, w) → V_1Rotate(V_1, (-(45°)), I, w) → W_1Segment(W_1, S_1) → e_2Segment(T_1, O_1) → f_2Segment(U_1, I) → h_2Segment(V_1, Q_1) → i_2Plane(F'_1, I, K) → o_1Circle(I, (0.3 * r), o_1) → k_2Rotate(K, 45°, I, o_1) → K'Rotate(K', 45°, I, o_1) → K''Rotate(K'', 45°, I, o_1) → K'''Rotate(K''', 45°, I, o_1) → Z_1Rotate(Z_1, 45°, I, o_1) → A_2Rotate(A_2, 45°, I, o_1) → B_2Rotate(B_2, 45°, I, o_1) → C_2Segment(C_2, K''') → j_2Segment(I, A_2) → l_2Segment(B_2, K'') → m_2Translate(B'_1, u_1) → D_2Segment(D_2, E_2) → n_2Midpoint(n_2) → F_2Intersect(i_2, j_2) → I_2Mirror(G_2, a_3) → M_2Segment(E_2, I) → q_2Segment(I, D_2) → r_2Mirror(G, i_2) → G'Mirror(I, i_2) → I'Segment(G', I') → b_3Point(zAxis) → R_2Sphere(R_2, (0.8 * r)) → v_1Intersect(zAxis, v_1) → S_2, T_2OrthogonalPlane(S_2, zAxis) → w_1Ray(E, S) → d_3Intersect(d_3, g) → U_2, V_2Segment(U_2, E) → e_3Rotate(U_2, 45°, e_1) → W_2Rotate(E, 45°, e_1) → E'Segment(W_2, E') → f_3Rotate(W_2, 45°, e_1) → Z_2Rotate(E', 45°, e_1) → E''Segment(Z_2, E'') → h_3Rotate(Z_2, 45°, e_1) → A_3Rotate(E'', 45°, e_1) → E'''Segment(A_3, E''') → i_3Translate(U_2, v) → B_3Translate(E, v) → E'_1Segment(B_3, E'_1) → j_3Translate(W_2, v) → C_3Translate(E', v) → E''_1Segment(C_3, E''_1) → k_3Translate(Z_2, v) → D_3Translate(E'', v) → E'''_1Segment(D_3, E'''_1) → l_3Translate(A_3, v) → E_3Translate(E''', v) → F_3Segment(E_3, F_3) → m_3Cylinder(g, (-((0.08 * r)))) → o_2, p_3, u_2Cylinder(g, (-((-0.08 * r)))) → v_2, q_3, w_2Cylinder(g', (-((0.08 * r)))) → n_3, r_3, o_3Cylinder(g', (0.08 * r)) → s_3, t_3, u_3Plane(B, G, A) → v_3Circle(G, (0.3 * r), v_3) → c_4Intersect(f_1, h_1) → G_3Intersect(n_1, c_4) → H_3, I_3Rotate(H_3, 45°, G, v_3) → J_3Rotate(J_3, 45°, G, v_3) → K_3Rotate(K_3, 45°, G, v_3) → L_3Rotate(I_3, 45°, G, v_3) → M_3Rotate(M_3, 45°, G, v_3) → N_3Rotate(N_3, 45°, G, v_3) → O_3Segment(M_3, J_3) → a_4Segment(G, K_3) → b_4Segment(O_3, L_3) → d_4Mirror(G, E_1) → G'_1Midpoint(G'_1, E_1) → P_3Segment(P_3, G) → e_4OrthogonalPlane(P_3, e_4) → w_3Circle(P_3, (0.4 * r), w_3) → f_4Line(P_3, a_3) → g_4Intersect(g_4, f_4, 1) → Q_3Mirror(Q_3, P_3) → R_3Rotate(R_3, (-(60°)), P_3, w_3) → S_3Mirror(S_3, g_4) → T_3CircleSector(Q_3, S_3, T_3, w_3) → h_4Line(D_2, E_2) → s_2Intersect(s_2, p_2) → M_1, N_1Rotate(N_1, 30°, D_2, p_2) → H_2Ray(D_2, H_2) → t_2Intersect(t_2, p_2) → J_2,Segment(J_2, D_2) → c_3Mirror(J_2, b_3) → K_2Mirror(D_2, b_3) → L_2Segment(K_2, L_2) → i_4Circle(A, (0.3 * r), j_1) → k_4Intersect(f_1, k_4) → N_2, O_2Rotate(O_2, (-(45°)), A, k_4) → P_2Rotate(P_2, (-(45°)), A, k_4) → U_3Rotate(U_3, (-(45°)), A, k_4) → Q_2Rotate(Q_2, (-(45°)), A, k_4) → V_3Rotate(V_3, (-(45°)), A, k_4) → W_3Rotate(W_3, (-(45°)), A, k_4) → Z_3Rotate(Z_3, (-(45°)), A, k_4) → A_4Segment(A_4, Q_2) → j_4Segment(O_2, V_3) → l_4Segment(U_3, Z_3) → m_4Segment(P_2, W_3) → n_4Segment(V, U) → p_4
AI Drawing Prompt Reference
Draw a 3D bike model in space, combining cylinders, spheres, and cuboids through rotation and translation to form the frame, wheels, and seat. Start by creating basic shapes, then determine key points by intersecting lines and circles, and finally connect the parts with polygons and lines to complete the bike structure.
The prompt above was compiled from the original drawing commands and is for reference only.