
三维球面截面
几何画板及绘图内容加载中,请稍等……
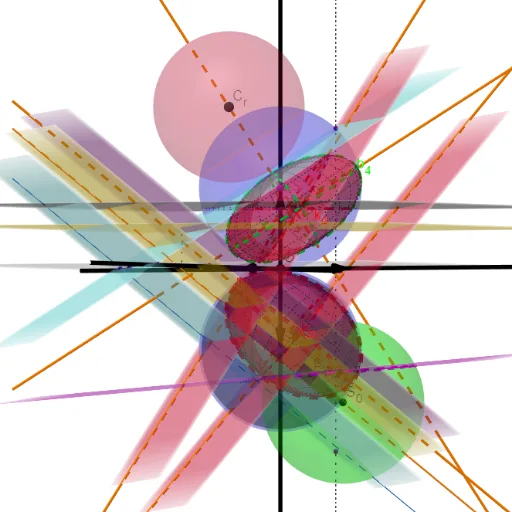
①本范例演示三维球面(3-Sphere)的截面图形及其变化;②涉及核心数学概念包括立体几何、球面几何、向量与坐标几何;③构造过程中运用了点、线、面、向量、旋转、平移等GeoGebra命令与对象,如Sphere, Line, Vector, Rotate, Translate等;④适合高中及以上学生及数学爱好者学习空间几何与参数化图形。
GeoGebra 命令及参数
Point(zAxis) → S_4Intersect(zAxis, yAxis) → OSphere(S_4, 1) → Σ_4Point(zAxis) → S_3Sphere(S_3, 1) → Σ_3Point(xAxis) → DLine(O, D) → fPoint(yAxis) → ELine(O, E) → gLine(O, S_4) → hVector(O, D) → xdirVector(O, E) → ydirVector(O, S_4) → wdirVector(O, S_3) → zdirPointIn(p) → APointIn(p) → BLine(A, B) → iPointIn(p) → COrthogonalLine(C, p) → jPoint(j) → FPoint(j) → GPlane(F, i) → qPlane(G, i) → rOrthogonalPlane(S_3, i) → p_1OrthogonalLine(S_3, r) → nIntersectPath(r, p_1) → kLine(S_3, k) → lIntersect(l, Σ_3, 2) → S_0Sphere(S_0, S_3) → Σ_0Intersect(l, p) → IOrthogonalLine(I, p) → mIntersect(m, q) → JSegment(I, J) → j_3Plane(J, p) → q_1Intersect(h, q_1) → P_4Plane(S_3, r) → r_1Sphere(S_3, z(P_4)) → dIntersect(l, d) → L, P_0Intersect(n, r) → NPlane(N, p) → p_2IntersectPath(p_2, r) → sPlane(s, n) → r_2Plane(P_0, s) → q_2IntersectPath(q_2, Σ_0) → k_0Intersect(p_1, k_0) → P, QLine(P, l) → tCenter(k_0) → C_0Line(C_0, l) → f_1Intersect(f_1, n) → C_3Intersect(t, n) → TOrthogonalLine(C_0, p_1) → g_1Intersect(f_1, k_0) → U,Intersect(g_1, k_0) → V, WLine(V, l) → h_1Intersect(h_1, r_2) → ZLine(P, C_0) → i_1AngularBisector(i_1, t) → j_1, k_1Intersect(k_1, f_1) → A_1OrthogonalLine(A_1, q_2) → l_1Distance(C_3, Z) → aCircle(T, a, t) → c_1Line(C_3, Z) → m_1Intersect(m_1, c_1) → B_1, C_1Ellipse(C_1, B_1, T) → k_3OrthogonalLine(N, p) → b_3Intersect(b_3, p) → HIntersectPath(p, r_2) → c_5Point(c_5) → D_1OrthogonalLine(D_1, p) → eIntersect(e, q) → E_1Line(E_1, c_5) → n_1Plane(H, n_1) → p_3Line(C_3, h) → s_1Line(T, wdir) → t_1Line(Z, wdir) → a_1Intersect(a_1, p_3) → F_1Intersect(s_1, p_3) → C_4Intersect(t_1, p_3) → H_1Line(C_4, H_1) → b_1Line(C_4, F_1) → d_1OrthogonalLine(H_1, p_3) → e_1Circle(H_1, a, e_1) → c_2Intersect(d_1, c_2) → I_1, J_1Ellipse(J_1, I_1, H_1) → k_4Plane(C_4, p) → q_3IntersectPath(q_3, Σ_4) → e_2Radius(e_2) → oSphere(S_3, o) → uIntersect(f_1, q_3) → K_1Intersect(f_1, u) → L_1, M_1Plane(M_1, m_1) → r_3OrthogonalLine(M_1, r_3) → f_2Circle(n, Z) → l_3OrthogonalLine(T, p_1) → h_2Circle(T, a, h_2) → k_2Intersect(r_3, k_2) → N_1, O_1Ellipse(N_1, O_1, T) → m_3IntersectPath(p_1, q_3) → i_2OrthogonalLine(M_1, p) → m_2OrthogonalLine(L_1, p) → n_2Intersect(n_2, q_3) → P_1Intersect(m_2, q_3) → Q_1Segment(P_1, Q_1) → g_2OrthogonalLine(C_4, p_3) → j_2Circle(d_1, H_1) → t_2Intersect(j_2, t_2) → R_1, S_1Line(R_1, P_1) → l_2Midpoint(R_1, P_1) → T_1OrthogonalLine(T_1, p_1) → a_2Circle(a_2, C_4) → c_3Intersect(l_2, c_3) → U_1, V_1Line(C_4, U_1) → b_2Line(C_4, V_1) → f_3Distance(V_1, P_1) → e1Distance(R_1, V_1) → e2Circle(C_4, e1, p_3) → d_3Circle(C_4, e2, d_1) → e_3Intersect(b_2, t_2) → W_1, Z_1Intersect(f_3, e_3) → A_2, B_2OrthogonalLine(A_2, p_1) → g_3Circle(A_2, a, g_3) → h_3Intersect(b_2, h_3) → C_2, D_2Distance(F_1, C_4) → c_6Plane(F_1, f_3) → p_4OrthogonalLine(A_2, p_4) → i_3Circle(A_2, a, i_3) → t_3Intersect(d_1, t_3) → E_2, F_2Ellipse(E_2, F_2, A_2) → c_4Circle(C_4, a, f_3) → d_4Distance(C_3, T) → bEllipse(C_2, D_2, A_2) → b_4Surface(((a * cos(u)) * sin(v)), ((a * sin(u)) * sin(v)), (b * cos(v)), u, 0, (2 * π), v, 0, π) → vVector(O, C_3) → wTranslate(v, w) → v'Angle(r, p) → αRotate(v', (-α), m_1) → σ_3Distance(C_4, A_2) → cSurface(((a * cos(u)) * sin(v)), ((a * sin(u)) * sin(v)), (c * cos(v)), u, 0, (2 * π), v, 0, π) → o_1Vector(O, C_4) → u_1Translate(o_1, u_1) → v_1Angle(q, p) → βRotate(v_1, β, d_1) → σ_4Intersect(s_1, p) → KDistance(K, C_3) → zcCircle(C_4, zc, f_3) → d_2Intersect(b_2, d_2) → M, RIntersect(f_3, q) → SOrthogonalLine(S, p_1) → s_2Circle(s_2, R) → s_3Intersect(f_3, s_3) → C_r, G_2Sphere(C_r, a) → σ_r