
三角形面积证明(与矩形相关)
几何画板及绘图内容加载中,请稍等……
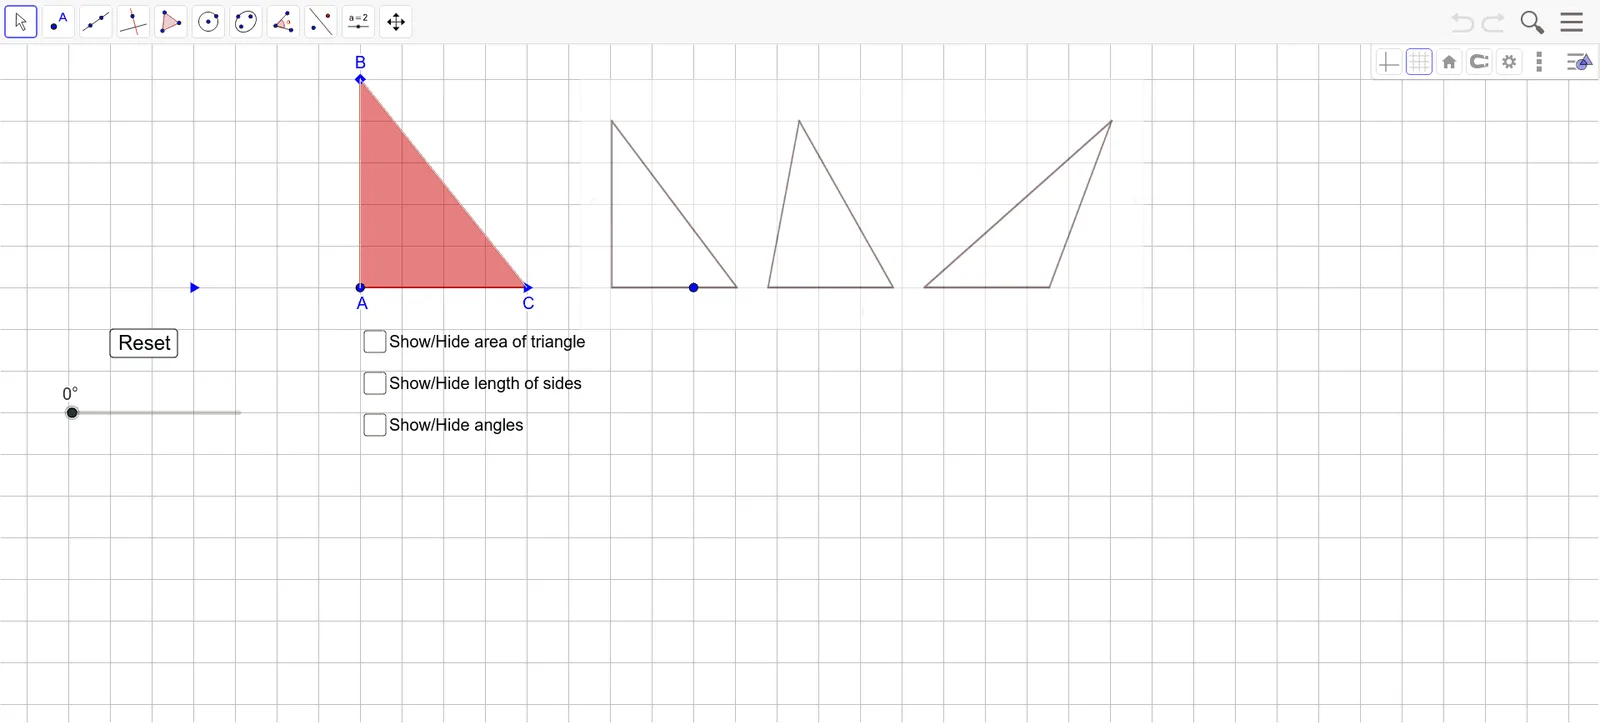
这个范例演示了如何通过构造矩形来证明三角形的面积公式。核心数学概念包括三角形面积公式、矩形面积公式以及几何变换。通过使用GeoGebra命令如Line、Point、Polygon等,可以直观地展示三角形与矩形之间的关系。适合初中及以上学生学习几何证明和面积计算。
GeoGebra 命令及参数
Line(A, xAxis) → f_1Point(f_1) → MRay(A, M) → h_1Point(h_1) → CVector(C, A) → vMidpoint(B, C) → M_{BC}Rotate(A, (-ζ), M_{BC}) → ISegment(C, A) → iOrthogonalLine(I, i) → qIntersect(q, i) → G_1Vector(A, C) → uMidpoint(B, A) → M_{AB}Rotate(C, ε, M_{AB}) → JOrthogonalLine(J, i) → kIntersect(k, i) → E_1Polygon(A, B, C) → Area, c, a, bAngle(C, A, B) → αAngle(A, B, C) → βAngle(B, C, A) → γSegment(A, B) → gSegment(B, C) → hPolygon(A, B, C) → poly1, c_1, a_1, b_1OrthogonalLine(B, i) → jIntersect(j, i) → DPolygon(B, D, C) → poly2, c_2, b_2, d_1Polygon(B, A, D) → poly3, d_2, b_3, a_2Rotate(B, (-δ), M_{BC}) → B'Rotate(D, (-δ), M_{BC}) → LRotate(C, (-δ), M_{BC}) → C'Polygon(B', L, C') → poly2', c', b', d'Rotate(B, δ, M_{AB}) → B'_1Rotate(A, δ, M_{AB}) → A'Rotate(D, δ, M_{AB}) → KPolygon(B'_1, A', K) → poly3', d'_1, b'_1, a'Segment(B, D) → dRotate(A, ε, M_{AB}) → A'_1Rotate(B, ε, M_{AB}) → B'_2Polygon(A'_1, B'_2, J) → poly1', c'_1, a'_1, b'_2Polygon(Translate[J, Vector[(l * u)]], Translate[E_1, Vector[(l * u)]], Translate[A, Vector[(l * u)]]) → poly5, m, n, pPolygon(J, E_1, A) → poly4, a_3, c'_2, e_1Intersect(m, n) → F_1Rotate(B, (-ζ), M_{BC}) → B'_3Rotate(C, (-ζ), M_{BC}) → C'_2Polygon(I, B'_3, C'_2) → poly1'_1, c'_3, a'_2, b'_3Polygon(Translate[I, Vector[(o * v)]], Translate[G_1, Vector[(o * v)]], Translate[C, Vector[(o * v)]]) → poly7, r, s, tPolygon(I, G_1, C) → poly6, c_3, a'_3, g_1Intersect(r, s) → H_1Polygon(J, A, E_1) → poly8, e_2, c'_4, a_4Polygon(I, G_1, C) → poly9, c_4, a'_4, g_2Intersect(e_2, a_4) → I_1Intersect(e_2, c'_4) → J_1Point(a_4) → K_1Polygon(I_1, J_1, K_1) → poly10, k_1, i_1, j_1Mirror(C, A) → C'_1Mirror(A, C) → A'_2OrthogonalLine(C, b'_2) → l_1Intersect(l_1, b'_2) → EPolygon(E, C, B) → poly11, b_4, n_1, c_5Vector(B, J) → wTranslate(E, w) → N'Translate(C, w) → C'_3Translate(B, w) → B'_4Polygon(Translate[E, Vector[(l * w)]], Translate[C, Vector[(l * w)]], Translate[B, Vector[(l * w)]]) → poly11', m_1, p_1, q_1Intersect(q_1, m_1) → FOrthogonalLine(A, b'_3) → r_1Intersect(b'_3, r_1) → GPolygon(B, G, A) → poly12, s_1, t_1, f_2Vector(B, I) → u_1Translate(B, u_1) → B'_5Translate(G, u_1) → HTranslate(A, u_1) → A'_3Polygon(Translate[B, Vector[(o * u_1)]], Translate[G, Vector[(o * u_1)]], Translate[A, Vector[(o * u_1)]]) → poly12', h_2, i_2, j_2Intersect(h_2, i_2) → N