
Spherical Section of a 3-Sphere
Loading the math board and drawing, please wait…
In collections
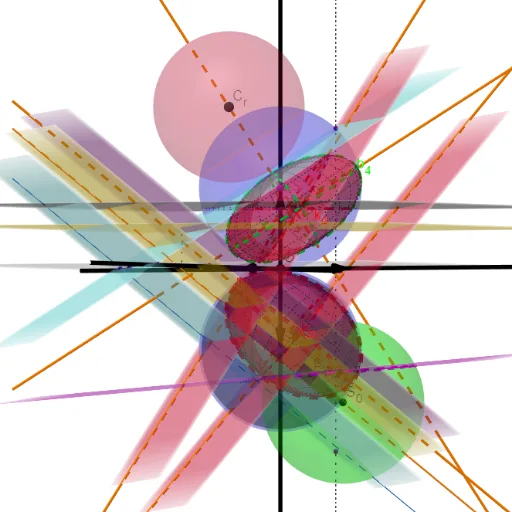
Spherical sections of a 3-Sphere
This example demonstrates the cross-section of a 3-Sphere, showcasing its geometric properties and transformations. Key mathematical concepts include solid geometry, spherical geometry, vectors, and coordinate geometry. GeoGebra commands and objects used in construction are Point, Intersect, Sphere, Line, Vector, Rotate, Translate, etc. Suitable for high school students and math enthusiasts exploring spatial geometry and parametric equations.
GeoGebra Commands & Parameters
Point(zAxis) → S_4Intersect(zAxis, yAxis) → OSphere(S_4, 1) → Σ_4Point(zAxis) → S_3Sphere(S_3, 1) → Σ_3Point(xAxis) → DLine(O, D) → fPoint(yAxis) → ELine(O, E) → gLine(O, S_4) → hVector(O, D) → xdirVector(O, E) → ydirVector(O, S_4) → wdirVector(O, S_3) → zdirPointIn(p) → APointIn(p) → BLine(A, B) → iPointIn(p) → COrthogonalLine(C, p) → jPoint(j) → FPoint(j) → GPlane(F, i) → qPlane(G, i) → rOrthogonalPlane(S_3, i) → p_1OrthogonalLine(S_3, r) → nIntersectPath(r, p_1) → kLine(S_3, k) → lIntersect(l, Σ_3, 2) → S_0Sphere(S_0, S_3) → Σ_0Intersect(l, p) → IOrthogonalLine(I, p) → mIntersect(m, q) → JSegment(I, J) → j_3Plane(J, p) → q_1Intersect(h, q_1) → P_4Plane(S_3, r) → r_1Sphere(S_3, z(P_4)) → dIntersect(l, d) → L, P_0Intersect(n, r) → NPlane(N, p) → p_2IntersectPath(p_2, r) → sPlane(s, n) → r_2Plane(P_0, s) → q_2IntersectPath(q_2, Σ_0) → k_0Intersect(p_1, k_0) → P, QLine(P, l) → tCenter(k_0) → C_0Line(C_0, l) → f_1Intersect(f_1, n) → C_3Intersect(t, n) → TOrthogonalLine(C_0, p_1) → g_1Intersect(f_1, k_0) → U,Intersect(g_1, k_0) → V, WLine(V, l) → h_1Intersect(h_1, r_2) → ZLine(P, C_0) → i_1AngularBisector(i_1, t) → j_1, k_1Intersect(k_1, f_1) → A_1OrthogonalLine(A_1, q_2) → l_1Distance(C_3, Z) → aCircle(T, a, t) → c_1Line(C_3, Z) → m_1Intersect(m_1, c_1) → B_1, C_1Ellipse(C_1, B_1, T) → k_3OrthogonalLine(N, p) → b_3Intersect(b_3, p) → HIntersectPath(p, r_2) → c_5Point(c_5) → D_1OrthogonalLine(D_1, p) → eIntersect(e, q) → E_1Line(E_1, c_5) → n_1Plane(H, n_1) → p_3Line(C_3, h) → s_1Line(T, wdir) → t_1Line(Z, wdir) → a_1Intersect(a_1, p_3) → F_1Intersect(s_1, p_3) → C_4Intersect(t_1, p_3) → H_1Line(C_4, H_1) → b_1Line(C_4, F_1) → d_1OrthogonalLine(H_1, p_3) → e_1Circle(H_1, a, e_1) → c_2Intersect(d_1, c_2) → I_1, J_1Ellipse(J_1, I_1, H_1) → k_4Plane(C_4, p) → q_3IntersectPath(q_3, Σ_4) → e_2Radius(e_2) → oSphere(S_3, o) → uIntersect(f_1, q_3) → K_1Intersect(f_1, u) → L_1, M_1Plane(M_1, m_1) → r_3OrthogonalLine(M_1, r_3) → f_2Circle(n, Z) → l_3OrthogonalLine(T, p_1) → h_2Circle(T, a, h_2) → k_2Intersect(r_3, k_2) → N_1, O_1Ellipse(N_1, O_1, T) → m_3IntersectPath(p_1, q_3) → i_2OrthogonalLine(M_1, p) → m_2OrthogonalLine(L_1, p) → n_2Intersect(n_2, q_3) → P_1Intersect(m_2, q_3) → Q_1Segment(P_1, Q_1) → g_2OrthogonalLine(C_4, p_3) → j_2Circle(d_1, H_1) → t_2Intersect(j_2, t_2) → R_1, S_1Line(R_1, P_1) → l_2Midpoint(R_1, P_1) → T_1OrthogonalLine(T_1, p_1) → a_2Circle(a_2, C_4) → c_3Intersect(l_2, c_3) → U_1, V_1Line(C_4, U_1) → b_2Line(C_4, V_1) → f_3Distance(V_1, P_1) → e1Distance(R_1, V_1) → e2Circle(C_4, e1, p_3) → d_3Circle(C_4, e2, d_1) → e_3Intersect(b_2, t_2) → W_1, Z_1Intersect(f_3, e_3) → A_2, B_2OrthogonalLine(A_2, p_1) → g_3Circle(A_2, a, g_3) → h_3Intersect(b_2, h_3) → C_2, D_2Distance(F_1, C_4) → c_6Plane(F_1, f_3) → p_4OrthogonalLine(A_2, p_4) → i_3Circle(A_2, a, i_3) → t_3Intersect(d_1, t_3) → E_2, F_2Ellipse(E_2, F_2, A_2) → c_4Circle(C_4, a, f_3) → d_4Distance(C_3, T) → bEllipse(C_2, D_2, A_2) → b_4Surface(((a * cos(u)) * sin(v)), ((a * sin(u)) * sin(v)), (b * cos(v)), u, 0, (2 * π), v, 0, π) → vVector(O, C_3) → wTranslate(v, w) → v'Angle(r, p) → αRotate(v', (-α), m_1) → σ_3Distance(C_4, A_2) → cSurface(((a * cos(u)) * sin(v)), ((a * sin(u)) * sin(v)), (c * cos(v)), u, 0, (2 * π), v, 0, π) → o_1Vector(O, C_4) → u_1Translate(o_1, u_1) → v_1Angle(q, p) → βRotate(v_1, β, d_1) → σ_4Intersect(s_1, p) → KDistance(K, C_3) → zcCircle(C_4, zc, f_3) → d_2Intersect(b_2, d_2) → M, RIntersect(f_3, q) → SOrthogonalLine(S, p_1) → s_2Circle(s_2, R) → s_3Intersect(f_3, s_3) → C_r, G_2Sphere(C_r, a) → σ_r