
Solve System of Linear Inequalities in 2 Unknowns
Loading the math board and drawing, please wait…
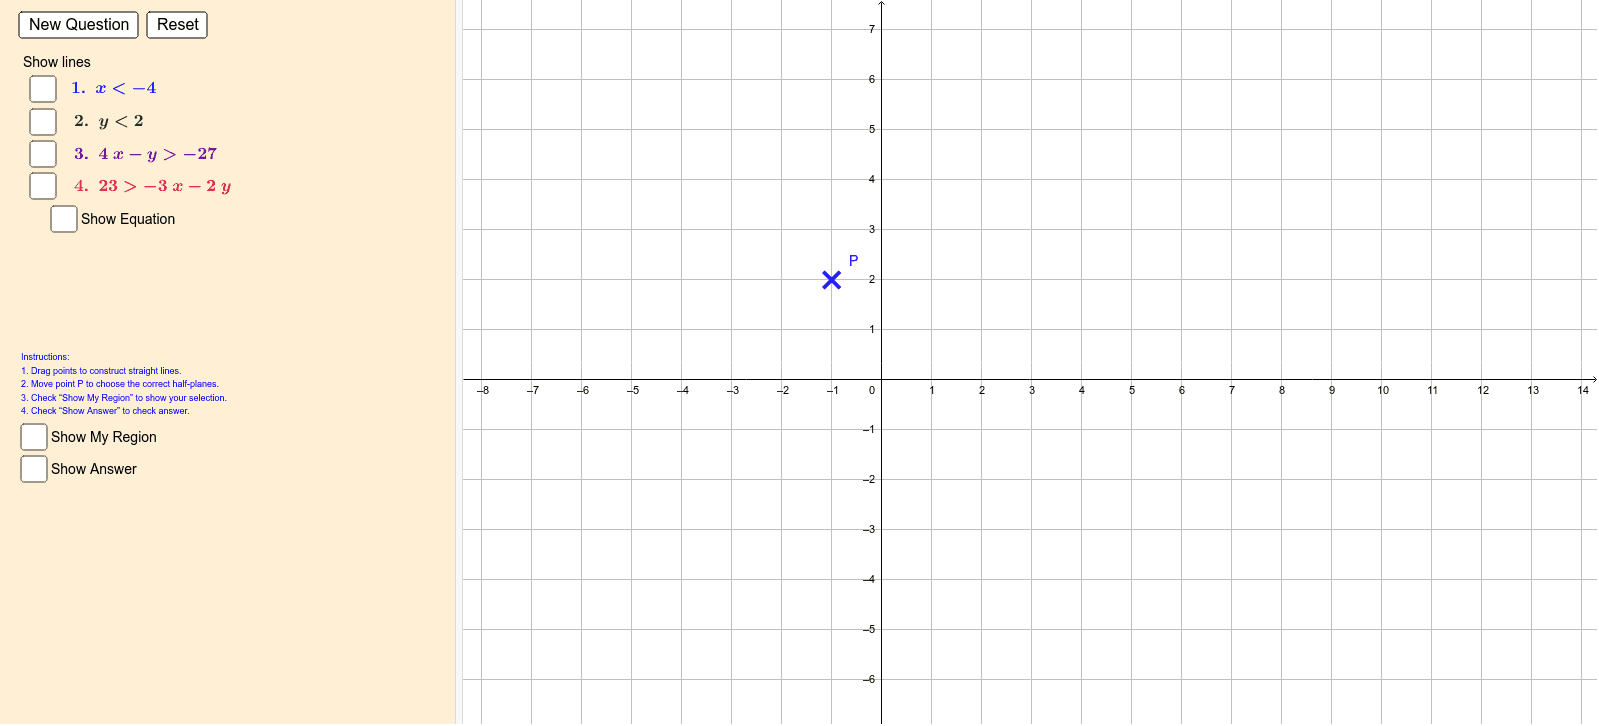
This example demonstrates how to graph and solve systems of linear inequalities in a 2D coordinate plane. Key math concepts include linear inequalities, region representation, and boundary lines. Construction highlights the use of GeoGebra commands and objects like RandomElement, If, Simplify, Line to generate random inequalities, draw lines, and display solution regions. Suitable for high school mathematics education to understand the geometric meaning of inequality solution sets.
GeoGebra Commands & Parameters
RandomElement({1, 2, 3, 4}) → s4RandomElement({-4, -3, -2, -1, 1, 2, 3, 4}) → m3aRandomElement({1, 2, 3}) → m3bRandomElement({1, 2, 3} \ {m3b}) → m4bRandomElement({-4, -3, -2, -1, 0, 1, 2, 3, 4}) → x1RandomElement({1, 2, 3, 4}) → s1If(s1 ≟ 1, -1, 1) → k1RandomElement({x1 + k1, x1 + (k1 * 2), x1 + (k1 * 3), x1 + (k1 * 4)}) → x2RandomElement({-4, -3, -2, -1, 0, 1, 2, 3, 4}) → y1RandomElement({1, 2, 3, 4}) → s2If(s2 ≟ 1, -1, 1) → k2RandomElement({y1 + k2, y1 + (k2 * 2), y1 + (k2 * 3), y1 + (k2 * 4)}) → y2RandomElement({-4, -3, -2, -1, 1, 2, 3, 4}) → m4aIf(s4 ≟ 1, (m4a * x) - (m4b * y) < (m4a * x2) - (m4b * y2), If[s4 ≟ 2, (m4a * x) - (m4b * y) ≤ (m4a * x2) - (m4b * y2), If[s4 ≟ 3, (m4a * x) - (m4b * y) > (m4a * x2) - (m4b * y2), (m4a * x) - (m4b * y) ≥ (m4a * x2) - (m4b * y2)]]) → h_1RandomElement({1, 2, 3, 4}) → s3If(s3 ≟ 1, (m3a * x) - (m3b * y) < (m3a * x2) - (m3b * y2), If[s3 ≟ 2, (m3a * x) - (m3b * y) ≤ (m3a * x2) - (m3b * y2), If[s3 ≟ 3, (m3a * x) - (m3b * y) > (m3a * x2) - (m3b * y2), (m3a * x) - (m3b * y) ≥ (m3a * x2) - (m3b * y2)]]) → g_1Simplify(g_1) → gSimplify(h_1) → hIf(s1 ≟ 1, x < x1, If[s1 ≟ 2, x ≤ x1, If[s1 ≟ 3, x > x1, x ≥ x1]]) → eLine(A, B) → L1Line(C, D) → L2Line(E, F) → L3Line(G, H) → L4If(x(C) ≟ x(D), x > x(C), ((y - y(C)) * (x(C) - x(D))) - ((x - x(C)) * (y(C) - y(D))) > 0) → L2aIf(x(C) ≟ x(D), x < x(C), ((y - y(C)) * (x(C) - x(D))) - ((x - x(C)) * (y(C) - y(D))) < 0) → L2bIf(x(A) ≟ x(B), x > x(A), ((y - y(A)) * (x(A) - x(B))) - ((x - x(A)) * (y(A) - y(B))) > 0) → L1aIf(x(A) ≟ x(B), x < x(A), ((y - y(A)) * (x(A) - x(B))) - ((x - x(A)) * (y(A) - y(B))) < 0) → L1bIf(x(E) ≟ x(F), x > x(E), ((y - y(E)) * (x(E) - x(F))) - ((x - x(E)) * (y(E) - y(F))) > 0) → L3aIf(x(E) ≟ x(F), x < x(E), ((y - y(E)) * (x(E) - x(F))) - ((x - x(E)) * (y(E) - y(F))) < 0) → L3bIf(x(G) ≟ x(H), x > x(G), ((y - y(G)) * (x(G) - x(H))) - ((x - x(G)) * (y(G) - y(H))) > 0) → L4aIf(x(G) ≟ x(H), x < x(G), ((y - y(G)) * (x(G) - x(H))) - ((x - x(G)) * (y(G) - y(H))) < 0) → L4bIf(c1a ∧ c2a ∧ c3a ∧ c4a, L1a(x, y) ∧ L2a(x, y) ∧ L3a(x, y) ∧ L4a(x, y), If[c1a ∧ c2a ∧ c3a ∧ c4b, L1a(x, y) ∧ L2a(x, y) ∧ L3a(x, y) ∧ L4b(x, y), If[c1a ∧ c2a ∧ c3b ∧ c4a, L1a(x, y) ∧ L2a(x, y) ∧ L3b(x, y) ∧ L4a(x, y), If[c1a ∧ c2b ∧ c3a ∧ c4a, L1a(x, y) ∧ L2b(x, y) ∧ L3a(x, y) ∧ L4a(x, y), If[c1b ∧ c2a ∧ c3a ∧ c4a, L1b(x, y) ∧ L2a(x, y) ∧ L3a(x, y) ∧ L4a(x, y), If[c1b ∧ c2b ∧ c3a ∧ c4a, L1b(x, y) ∧ L2b(x, y) ∧ L3a(x, y) ∧ L4a(x, y), If[c1b ∧ c2a ∧ c3b ∧ c4a, L1b(x, y) ∧ L2a(x, y) ∧ L3b(x, y) ∧ L4a(x, y), If[c1b ∧ c2a ∧ c3a ∧ c4b, L1b(x, y) ∧ L2a(x, y) ∧ L3a(x, y) ∧ L4b(x, y), If[c1a ∧ c2b ∧ c3b ∧ c4a, L1a(x, y) ∧ L2b(x, y) ∧ L3b(x, y) ∧ L4a(x, y), If[c1a ∧ c2b ∧ c3a ∧ c4b, L1a(x, y) ∧ L2b(x, y) ∧ L3a(x, y) ∧ L4b(x, y), If[c1a ∧ c2a ∧ c3b ∧ c4b, L1a(x, y) ∧ L2a(x, y) ∧ L3b(x, y) ∧ L4b(x, y), If[c1b ∧ c2b ∧ c3b ∧ c4a, L1b(x, y) ∧ L2b(x, y) ∧ L3b(x, y) ∧ L4a(x, y), If[c1b ∧ c2b ∧ c3a ∧ c4b, L1b(x, y) ∧ L2b(x, y) ∧ L3a(x, y) ∧ L4b(x, y), If[c1b ∧ c2a ∧ c3b ∧ c4b, L1b(x, y) ∧ L2a(x, y) ∧ L3b(x, y) ∧ L4b(x, y), If[c1a ∧ c2b ∧ c3b ∧ c4b, L1a(x, y) ∧ L2b(x, y) ∧ L3b(x, y) ∧ L4b(x, y), If[c1b ∧ c2b ∧ c3b ∧ c4b, L1b(x, y) ∧ L2b(x, y) ∧ L3b(x, y) ∧ L4b(x, y)]]]]]]]]]]]]]]]) → checkSolSimplify((m3a * (x - x2)) + (y2 * m3b)) → g_2Simplify((m4a * (x - x2)) + (y2 * m4b)) → h_2If(s2 ≟ 1, (0 * x) + y < y1, If[s2 ≟ 2, (0 * x) + y ≤ y1, If[s2 ≟ 3, (0 * x) + y > y1, (0 * x) + y ≥ y1]]) → f_1Simplify(f_1) → fLine(A, B) → L1solidLine(C, D) → L2solidLine(E, F) → L3solidLine(G, H) → L4solidIf(caly ≟ 3, y2 + (m3a / m3b * (tempx - x2)), If[caly ≟ 4, y2 + (m4a / m4b * (tempx - x2))]) → tempy