
Russian Football Geometry Construction
Loading the math board and drawing, please wait…
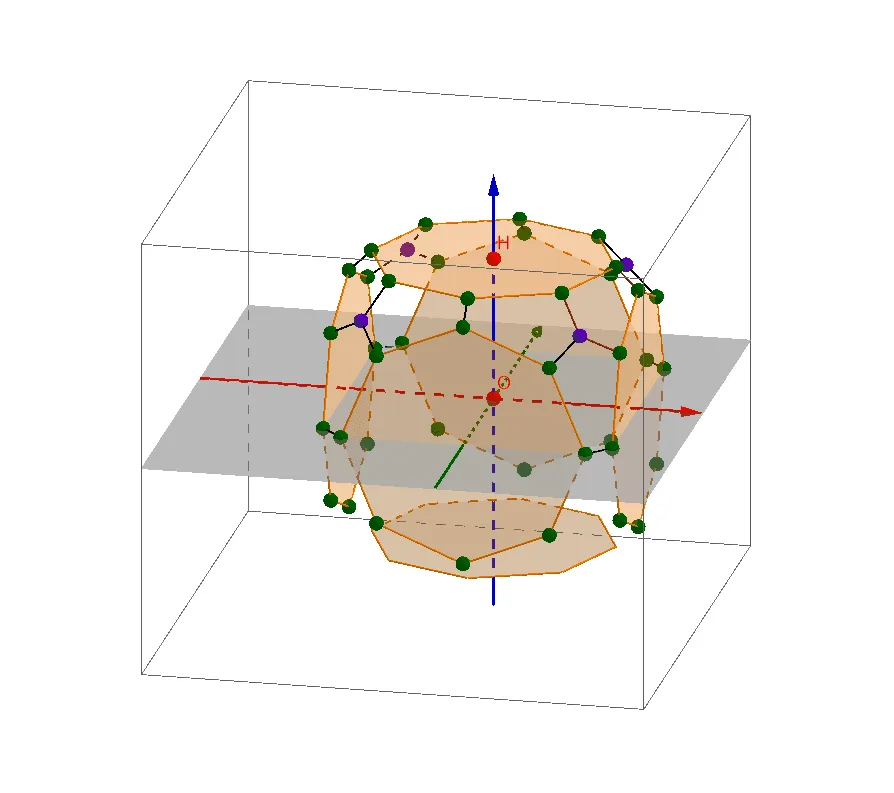
This example dynamically demonstrates the geometric construction of a Russian football, revealing its complex symmetry and spatial relationships. It involves core mathematical concepts like vectors, matrix transformations, rotations, reflections, polygon construction, and orthocenters. The construction uses commands and objects such as Point, Vector, Mirror, Polygon, Rotate, Segment, Sphere, OrthogonalPlane, Circle, Center, Ray, Intersect, Distance from GeoGebra. Suitable for high school and above learners to understand the practical applications of spatial geometry, linear algebra, and transformation theory.
GeoGebra Commands & Parameters
Point(zAxis) → HVector(O, H) → uMirror(A, yAxis) → A'Polygon(A, A', 8) → poly1, f, C, D, E, F, G, g, h, i, j, k, l, m, BRotate(Translate[Lo, u], 22.5°, zAxis) → Lo'Point(Lo') → IPoint(Lo') → JPoint(Lo') → KRotate(Lo', 90°, xAxis) → Lo''Rotate(Rotate[Lo', 90°, xAxis], 22.5°, yAxis) → liste1Rotate(Translate[Lo, u], 45°, zAxis) → poly1'Point(Lo') → LPoint(Lo'') → MSegment(L, M) → nRotate(Lo'', 90°, zAxis) → LbRotate(Lb, 90°, zAxis) → LcRotate(Lc, 90°, zAxis) → LdPoint(Lo') → NSphere(O, N) → aPoint(Lo') → PPoint(Lb) → QSegment(P, Q) → pPoint(Lo'') → RPoint(Lo'') → SOrthogonalPlane(O, xAxis) → dPoint(Lb) → UCircle(N, S, U) → eCenter(e) → VSphere(O, N) → bPoint(Lo'') → TPoint(Lb) → WSegment(T, W) → tRay(O, V) → cIntersect(c, b) → Z,Polygon(P, Q, U, Z, N) → poly2, p_1, q, u_1, z_1, n_1Segment(S, Z) → rRotate(Z, 90°, zAxis) → Z'Rotate(Z', 90°, zAxis) → Z''Rotate(Z'', 90°, zAxis) → Z'''Point(Lo') → A_1Segment(A_1, Z''') → sSegment(R, Z''') → f_1Point(Ld) → B_1Segment(Z''', B_1) → g_1Point(Ld) → C_1Point(Lo') → D_1Segment(C_1, D_1) → h_1Point(Lo') → E_1Segment(E_1, Z'') → i_1Point(Ld) → F_1Segment(Z'', F_1) → j_1Point(Lc) → G_1Segment(Z'', G_1) → k_1Point(Lo') → H_1Segment(H_1, Z') → l_1Point(Lc) → I_1Segment(Z', I_1) → m_1Point(Lb) → J_1Segment(Z', J_1) → q_1Point(Lb) → K_1Point(Lc) → L_1Segment(K_1, L_1) → r_1Point(Lc) → M_1Point(Ld) → N_1Segment(M_1, N_1) → s_1Point(Ld) → O_1Point(Lo'') → P_1Segment(O_1, P_1) → t_1Point(Lc) → R_1Point(Lo') → S_1Segment(R_1, S_1) → a_1Point(Lo'') → Q_1Point(Lo'') → T_1Point(Lo'') → U_1Point(Lo'') → V_1Point(Lo'') → W_1Point(Lo'') → Z_1Point(Lo'') → A_2Point(Lo'') → B_2Rotate(Translate[poly1, u], 22.5°, zAxis) → poly4Rotate(poly4, 90°, xAxis) → poly4'Rotate(poly4', 90°, zAxis) → poly4''Rotate(poly4'', 90°, zAxis) → poly4'''Rotate(poly4', -90°, zAxis) → poly4''_1Mirror(poly4, O) → poly4'_1Distance(O, H) → distanceOH