
Properties of Conic Sections: Geometric Construction and Visualization
Loading the math board and drawing, please wait…
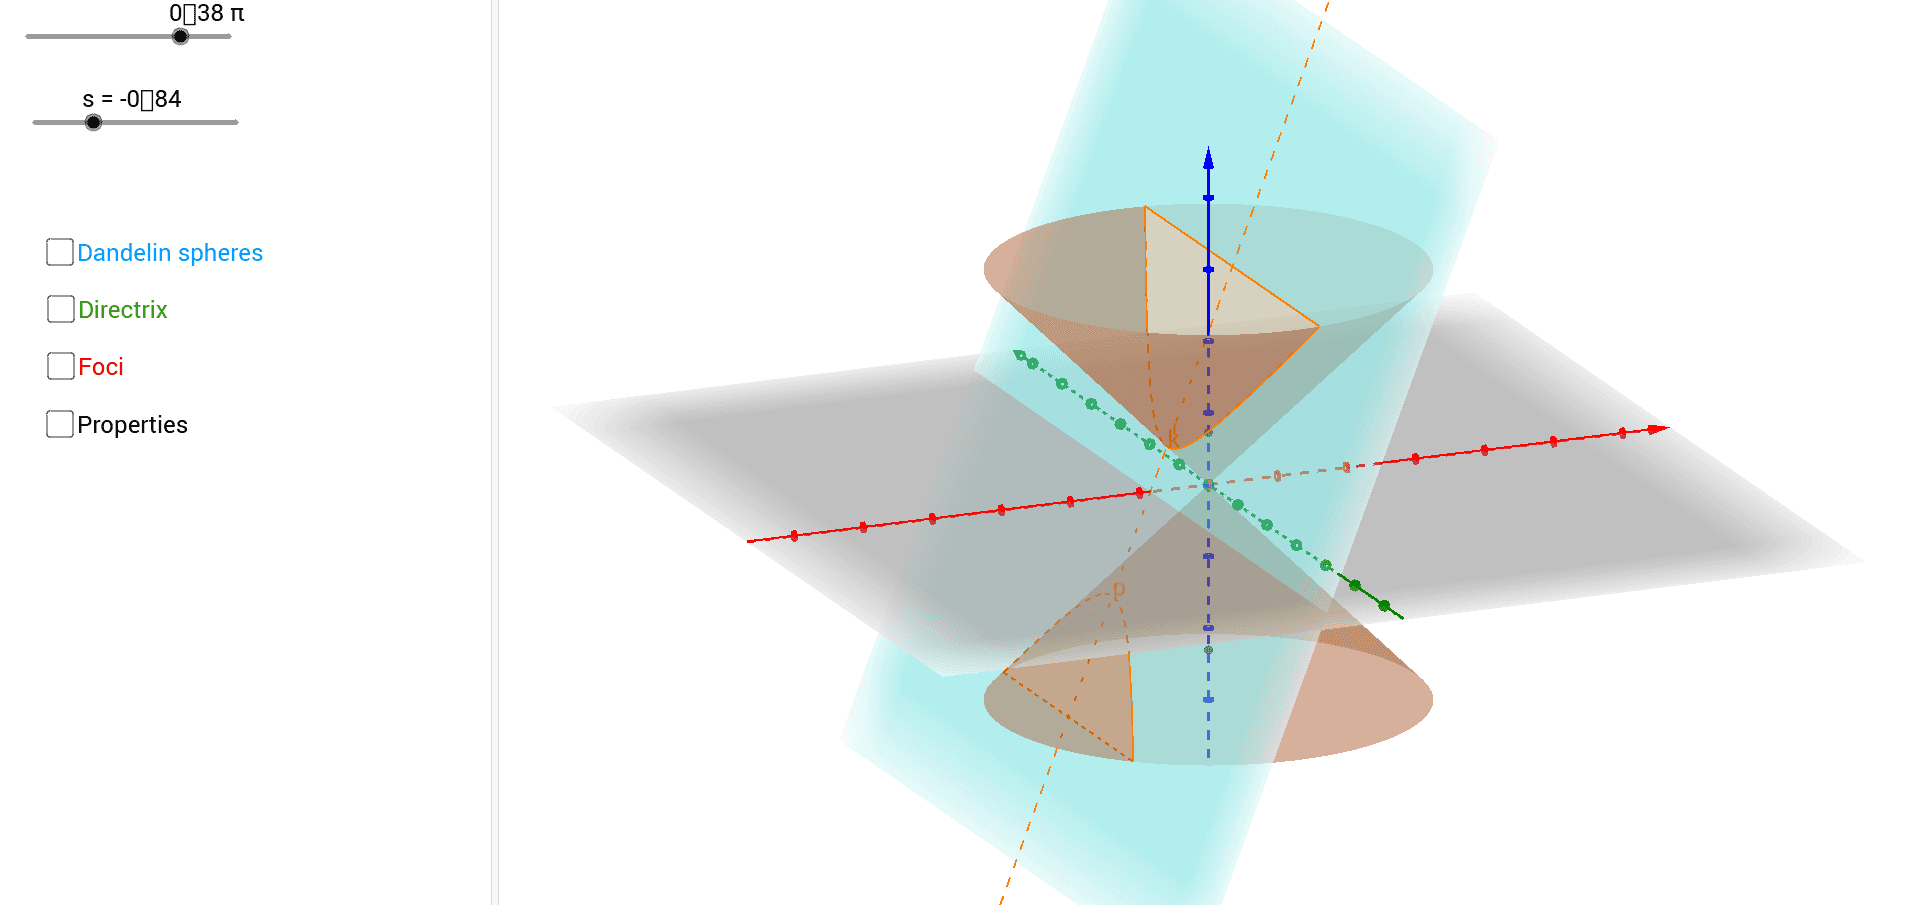
This example demonstrates the geometric properties of conic sections generated by intersecting a cone with a plane, highlighting ellipses, parabolas, and hyperbolas together with their foci, directrices, axes of symmetry, and cross-sectional forms. Core mathematical concepts include conic sections, analytic geometry, solid geometry (cones, spheres, orthogonal planes), angle bisectors, rigid transformations (rotation and translation), and trigonometric functions for auxiliary positioning. The construction relies on GeoGebra commands such as Circle, Intersect, Cone, OrthogonalPlane, IntersectPath, AngularBisector, Line, OrthogonalLine, Sphere, Point, Segment, Rotate, and Translate, involving objects like cones, cutting planes, spheres, foci (focus1, focus2), centers (center1, center2), intersection points, segments, and rotated/translated image elements. It is suitable for high school analytic and solid geometry instruction, as well as pre-calculus or introductory university conic sections study, supporting classroom demonstration and independent student exploration.
GeoGebra Commands & Parameters
Circle((0, 0, 3), 3, Vector[(0, 0, 1)]) → cCircle((0, 0, -3), 3, Vector[(0, 0, 1)]) → dIntersect(zAxis, xAxis) → ACone(c, -3) → a, e, bCone(d, 3) → f, g, hOrthogonalPlane((s, 0, 0), Vector[(sin((t * π)), 0, (-cos((t * π))))]) → cutplaneIntersectPath(cutplane, l) → mIntersect(m, j) → BIntersectPath(cutplane, n) → qIntersect(q, j) → CIntersectPath(cutplane, j) → rIntersectPath(j, l) → a_1IntersectPath(j, n) → b_1AngularBisector(r, a_1) → cc, d_1AngularBisector(r, b_1) → ee, f_1Line((0, 0, 0), Vector[(0, 0, 1)]) → yyIntersect(cc, yy) → center1Intersect(ee, yy) → center2OrthogonalLine(center1, r, space) → c_1Intersect(c_1, r) → focus1OrthogonalLine(center2, r, space) → e_1Intersect(r, e_1) → focus2Sphere(center1, focus1) → sphere1Sphere(center2, focus2) → sphere2OrthogonalLine(center1, a_1, space) → g_1OrthogonalLine(center2, a_1, space) → h_1Intersect(h_1, a_1) → DIntersect(a_1, g_1) → EOrthogonalPlane(D, Vector[(0, 0, 1)]) → plane2OrthogonalPlane(E, Vector[(0, 0, 1)]) → plane1IntersectPath(cutplane, plane1) → directrix1IntersectPath(cutplane, plane2) → directrix2IntersectPath(plane1, sphere1) → circle1IntersectPath(plane2, sphere2) → circle2IntersectPath(cutplane, b) → kIntersectPath(cutplane, h) → pPoint(k) → PSegment(P, focus1) → iSegment(P, focus2) → i_1Line(P, (0, 0, 0)) → j_1Intersect(j_1, circle2) → F,Segment(P, F) → k_1Intersect(j_1, circle1) → G,IntersectPath(o, cutplane) → l_1Rotate(k, (t * π), l_1) → k'Translate(k', Vector[((-s), 0, 0)]) → k''Segment(G, P) → m_1