
Proof Without Words by Steve Phelps (4)
Loading the math board and drawing, please wait…
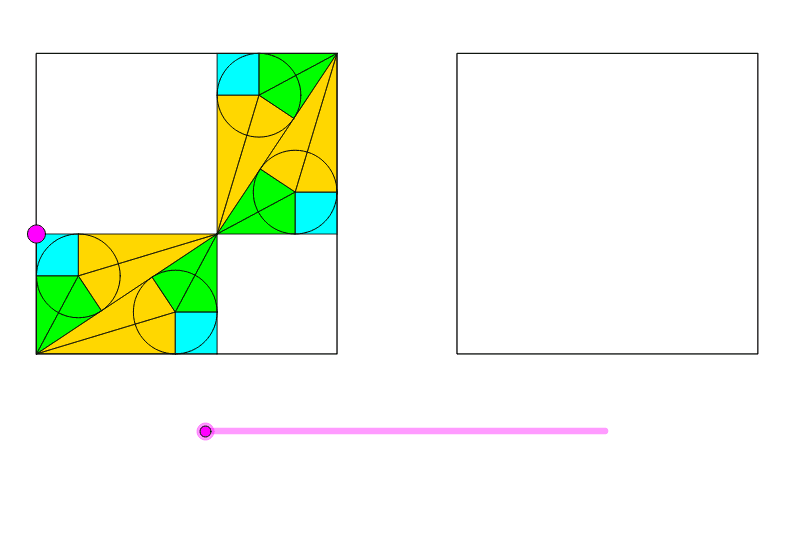
Drag points and sliders to observe changes and explore geometric proofs. This example demonstrates proving geometric properties through geometric transformations. It uses commands like constructing polygons, circles, vectors, and transformations in GeoGebra. Suitable for middle school and above students learning geometric proofs.
GeoGebra Commands & Parameters
Intersect(xAxis, yAxis) → APoint(xAxis) → BPolygon(A, B, 4) → poly1, a, b, c, d, C, DPoint(xAxis) → EPolygon(E, F, 4) → poly2, e, f, g, h, G, HPoint(d) → IOrthogonalLine(I, d) → iCircle(C, Segment[A, I]) → kIntersect(k, c, 1) → JOrthogonalLine(J, c) → jIntersect(i, j) → KSegment(A, K) → lSegment(K, C) → mIntersect(j, a) → LIntersect(i, b) → MIncircle(J, C, K) → pIncircle(C, M, K) → qIncircle(K, L, A) → rIncircle(I, K, A) → sCenter(s) → NCenter(p) → OCenter(q) → PCenter(r) → QIntersect(s, i, 1) → RIntersect(s, d, 1) → SIntersect(s, l, 1) → TIntersect(r, l, 1) → UIntersect(r, j, 1) → VIntersect(r, a, 1) → WIntersect(q, m, 1) → ZIntersect(q, i, 1) → A_1Intersect(q, b, 1) → B_1Intersect(p, m, 1) → C_1Intersect(p, j, 1) → D_1Segment(D_1, O) → tSegment(O, C_1) → a_1Segment(Z, P) → b_1Segment(P, B_1) → c_1Segment(P, A_1) → d_1Segment(U, Q) → e_1Segment(Q, V) → f_1Segment(Q, W) → g_1Segment(T, N) → h_1Segment(N, S) → i_1Segment(N, R) → j_1Intersect(p, c) → E_1, F_1Segment(O, E_1) → nSegment(J, K) → k_1Segment(K, L) → l_1Segment(K, M) → m_1Segment(K, I) → n_1Polygon(I, S, N, R) → poly3, i_2, s_1, n_2, r_1Polygon(Q, W, L, V) → poly4, q_1, w, l_2, vPolygon(D_1, J, E_1, O) → poly5, d_2, j_2, e_2, oPolygon(P, A_1, M, B_1) → poly6, p_1, a_2, m_2, b_2If(0 ≤ zz ≤ 1, 1 - zz, If[zz > 1, 0, 1]) → d1Dilate(M, d1, F) → M'Vector(M, M') → uTranslate(P, u) → P'Translate(A_1, u) → G_1Translate(M, u) → M'_1Translate(B_1, u) → H_1Polygon(P', G_1, M'_1, H_1) → poly6', p', g_2, m'_1, h_2Dilate(O, d1, H_1) → O'Dilate(L, d1, G_1) → L'Dilate(N, d1, P') → N'Vector(O, O') → u_1Vector(L, L') → v_1Vector(N, N') → w_1Translate(D_1, u_1) → I_1Translate(J, u_1) → J'Translate(E_1, u_1) → J_1Translate(O, u_1) → O'_1Polygon(I_1, J', J_1, O'_1) → poly5', i_3, j', j_3, o'_1Translate(Q, v_1) → Q'Translate(W, v_1) → W'Translate(L, v_1) → L'_1Translate(V, v_1) → V'Polygon(Q', W', L'_1, V') → poly4', q', w', l'_1, v'Translate(I, w_1) → I'Translate(S, w_1) → S'Translate(N, w_1) → N'_1Translate(R, w_1) → R'Polygon(I', S', N'_1, R') → poly3', i', s', n'_1, r'Segment(P, C) → t_1Segment(O, K) → c_2Segment(K, P) → f_2Segment(Q, K) → k_2Segment(Q, A) → p_2Segment(N, A) → q_2Segment(N, K) → r_2Polygon(B_1, C, P) → poly7, p_3, b_3, c_3If(1 ≤ zz ≤ 2, 2 - zz, If[zz > 2, 0, 1]) → d2Dilate(B_1, d2, J_1) → K_1Vector(B_1, K_1) → u_2Translate(B_1, u_2) → L_1Translate(C, u_2) → C'Translate(P, u_2) → P'_1Polygon(L_1, C', P'_1) → poly7', p'_1, l_3, c'Polygon(K, D_1, O) → poly8, o_1, k_3, d_3Dilate(O, d2, C') → O'_2Vector(O, O'_2) → v_2Translate(K, v_2) → K'Translate(D_1, v_2) → M_1Translate(O, v_2) → O'_3Polygon(K', M_1, O'_3) → poly8', o'_3, k', m_3Dilate(W, d2, W') → W'_1Vector(W, W'_1) → w_2Polygon(A, Q, W) → poly9, w_3, a_3, q_3Translate(A, w_2) → A'Translate(Q, w_2) → Q'_1Translate(W, w_2) → W'_2Polygon(A', Q'_1, W'_2) → poly9', w'_2, a', q'_1Polygon(N, R, K) → poly10, k_4, n_3, r_3Dilate(K, d2, Q'_1) → K'_1Vector(K, K'_1) → s_2Translate(N, s_2) → N'_2Translate(R, s_2) → R'_1Translate(K, s_2) → K'_2Polygon(N'_2, R'_1, K'_2) → poly10', k'_2, n'_2, r'_1Angle(W, A, T) → αPolygon(T, N, K) → poly11, k_5, t_2, n_4Translate(T, s_2) → T'Translate(N, s_2) → N'_3Translate(K, s_2) → K'_3Polygon(T', N'_3, K'_3) → poly11', k'_3, t', n'_3If(1 ≤ zz ≤ 2, zz - 1, If[zz > 2, 1, 0]) → r1Rotate(T', (-((α * r1))), K'_1) → T''Rotate(N'_3, (-((α * r1))), K'_1) → N_1Rotate(K'_3, (-((α * r1))), K'_1) → O_1Polygon(T'', N_1, O_1) → poly11'', o_2, t'', n_5Polygon(A, U, Q) → poly12, q_4, a_4, u_3Dilate(Q, d2, Q') → Q'_2Vector(Q, K'_1) → v_3Translate(A, v_3) → A'_1Translate(U, v_3) → U'Translate(Q, v_3) → Q'_3Rotate(A'_1, (-((α * r1))), K'_1) → P_1Rotate(U', (-((α * r1))), K'_1) → U''Rotate(Q'_3, (-((α * r1))), K'_1) → Q_1Dilate(Q, d2, Q') → Q'_4Vector(Q, Q'_1) → e_3Translate(A, e_3) → A'_2Translate(U, e_3) → U'_1Translate(Q, e_3) → Q'_5Polygon(A'_2, U'_1, Q'_5) → poly12', q'_5, a'_2, u'_1Rotate(A'_2, (-((α * r1))), Q'_1) → R_1Rotate(U'_1, (-((α * r1))), Q'_1) → S_1Rotate(Q'_5, (-((α * r1))), Q'_1) → T_1Polygon(R_1, S_1, T_1) → poly12'', t_3, r_4, s_3Polygon(K, O, C_1) → poly13, c_4, k_6, o_3Dilate(K, d2, K') → K'_4Vector(K, K'_4) → f_3Translate(K, f_3) → K'_5Translate(O, f_3) → O'_4Translate(C_1, f_3) → U_1Polygon(K'_5, O'_4, U_1) → poly13', u_4, k'_5, o'_4Rotate(K'_5, (α * r1), K'_4) → V_1Rotate(O'_4, (α * r1), K'_4) → W_1Rotate(U_1, (α * r1), K'_4) → Z_1Polygon(V_1, W_1, Z_1) → poly13'', z_1, v_4, w_4Polygon(C, Z, P) → poly14, p_4, c_5, z_2Dilate(P, d2, K'_4) → P'_2Vector(P, P'_2) → g_3Translate(C, g_3) → C'_1Translate(Z, g_3) → Z'Translate(P, g_3) → P'_3Polygon(C'_1, Z', P'_3) → poly14', p'_3, c'_1, z'Rotate(C'_1, (α * r1), P'_2) → A_2Rotate(Z', (α * r1), P'_2) → Z''Rotate(P'_3, (α * r1), P'_2) → B_2Polygon(A_2, Z'', B_2) → poly14'', b_4, a_5, z''Segment(O, C) → h_3Polygon(A, S, N) → poly15, n_6, a_6, s_4Polygon(A, T, N) → poly16, n_7, a_7, t_4Polygon(Q, U, K) → poly17, k_7, q_5, u_5Polygon(Q, V, K) → poly18, k_8, q_6, v_5If(2 ≤ zz ≤ 3, 3 - zz, If[zz > 2, 0, 1]) → d3If(2 ≤ zz ≤ 3, zz - 2, If[zz > 3, 1, 0]) → r2Dilate(V, d3, E) → V'_1Vector(V, V'_1) → d_4Translate(Q, d_4) → Q'_6Translate(V, d_4) → V'_2Translate(K, d_4) → K'_6Polygon(Q'_6, V'_2, K'_6) → poly18', k'_6, q'_6, v'_2Rotate(Q'_6, (-((90° * r2))), V'_1) → C_2Rotate(V'_2, (-((90° * r2))), V'_1) → D_2Rotate(K'_6, (-((90° * r2))), V'_1) → E_2Polygon(C_2, D_2, E_2) → poly18'', e_4, c_6, d_5Dilate(N, d3, A') → N'_4Vector(N, N'_4) → f_4Translate(A, f_4) → A'_3Translate(S, f_4) → S'_1Translate(N, f_4) → N'_5Polygon(A'_3, S'_1, N'_5) → poly15', n'_5, a'_3, s'_1Rotate(A'_3, (-(((r2 * 90))°)), N'_4) → F_2Rotate(S'_1, (-(((r2 * 90))°)), N'_4) → G_2Rotate(N'_5, (-(((r2 * 90))°)), N'_4) → H_2Polygon(F_2, G_2, H_2) → poly15'', h_4, f_5, g_4Dilate(T, d3, R'_1) → T'_1Vector(T, T'_1) → i_4Translate(A, i_4) → A'_4Translate(T, i_4) → T'_2Translate(N, i_4) → N'_6Polygon(A'_4, T'_2, N'_6) → poly16', n'_6, a'_4, t'_2Rotate(A'_4, (-((r2 * α))), T'_1) → I_2Rotate(T'_2, (-((r2 * α))), T'_1) → J_2Rotate(N'_6, (-((r2 * α))), T'_1) → K_2Polygon(I_2, J_2, K_2) → poly16'', k_9, i_5, j_4Dilate(K, d3, N_1) → K'_7Vector(K, K'_7) → l_4Translate(Q, l_4) → Q'_7Translate(U, l_4) → U'_2Translate(K, l_4) → K'_8Polygon(Q'_7, U'_2, K'_8) → poly17', k'_8, q'_7, u'_2Rotate(Q'_7, (-((r2 * α))), K'_7) → L_2Rotate(U'_2, (-((r2 * α))), K'_7) → M_2Rotate(K'_8, (-((r2 * α))), K'_7) → N_2Polygon(L_2, M_2, N_2) → poly17'', n_8, l_5, m_4Polygon(O, C, C_1) → poly19, c_7, o_4, c_8Polygon(O, E_1, C) → poly20, c_9, o_5, e_5Polygon(K, Z, P) → poly21, p_5, k_{10}, z_3Polygon(K, A_1, P) → poly22, p_6, k_{11}, a_8Dilate(C, d3, G) → C'_2Vector(C, C'_2) → w_5Translate(O, w_5) → O'_5Translate(C, w_5) → C'_3Translate(C_1, w_5) → O_2Polygon(O'_5, C'_3, O_2) → poly19', o_6, o'_5, c'_3Rotate(O'_5, (r2 * α), C'_2) → P_2Rotate(C'_3, (r2 * α), C'_2) → Q_2Rotate(O_2, (r2 * α), C'_2) → R_2Polygon(P_2, Q_2, R_2) → poly19'', r_5, p_7, q_7Dilate(P, d3, G) → P'_4Vector(P, P'_4) → b_5Translate(K, b_5) → K'_9Translate(Z, b_5) → Z'_1Translate(P, b_5) → P'_5Polygon(K'_9, Z'_1, P'_5) → poly21', p'_5, k'_9, z'_1Rotate(K'_9, (r2 * α), P'_4) → S_2Rotate(Z'_1, (r2 * α), P'_4) → T_2Rotate(P'_5, (r2 * α), P'_4) → U_2Polygon(S_2, T_2, U_2) → poly21'', u_6, s_5, t_5Dilate(P, d3, M_1) → P'_6Vector(P, P'_6) → g_5Translate(K, g_5) → K'_{10}Translate(A_1, g_5) → V_2Translate(P, g_5) → P'_7Polygon(K'_{10}, V_2, P'_7) → poly22', p'_7, k'_{10}, v_6Rotate(K'_{10}, (-(((r2 * 90))°)), P'_6) → W_2Rotate(V_2, (-(((r2 * 90))°)), P'_6) → Z_2Rotate(P'_7, (-(((r2 * 90))°)), P'_6) → A_3Polygon(W_2, Z_2, A_3) → poly22'', a_9, w_6, z_4Dilate(C, d3, M_1) → C'_4Vector(C, C'_4) → h_5Translate(O, h_5) → O'_6Translate(E_1, h_5) → B_3Translate(C, h_5) → C'_5Polygon(O'_6, B_3, C'_5) → poly20', c'_5, o'_6, b_6Rotate(O'_6, (-(((r2 * 90))°)), C'_4) → C_3Rotate(B_3, (-(((r2 * 90))°)), C'_4) → D_3Rotate(C'_5, (-(((r2 * 90))°)), C'_4) → E_3Polygon(C_3, D_3, E_3) → poly20'', e_6, c_{10}, d_6
AI Drawing Prompt Reference
Draw a quadrilateral and two squares, observing geometric transformations by dragging points and sliders. Start by constructing a quadrilateral and two squares, then connect the diagonals and draw perpendicular lines. Next, draw circles centered at one vertex and the diagonals, intersecting to form incircles. Finally, connect key intersection points to create multiple small triangles and quadrilaterals, demonstrating geometric properties.
The prompt above was compiled from the original drawing commands and is for reference only.