
Parameterized Rigid Cube
Loading the math board and drawing, please wait…
In collections
Linkages
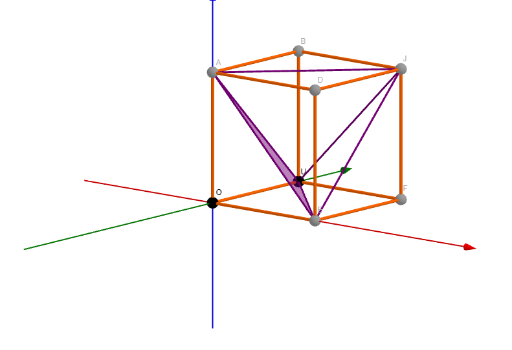
This example demonstrates the dynamic construction of a parameterized rigid cube using linkages, showcasing geometric transformations such as rotation and translation. It involves core mathematical concepts like geometry, quadratic equations, integral calculus, and parametric equations. The construction utilizes GeoGebra commands/objects including O, U, e, a, j, f, b, d, E, A, J, F, B, D, Tetraedro, l1, texto1, LongitudBarras, coorE, coorA, coorJ, coorF, coorB, coorD, l2, texto2 for parameterized movement and locus visualization. Suitable for high school and advanced mathematics education.
GeoGebra Commands & Parameters
(0, 0, 0)(0, 1, 0)Boolean e(true)Boolean a(false)Boolean j(false)Boolean f(false)Boolean b(false)Boolean d(false)((2 * e) - 1, 0, 0)(0, 0, 1 - (2 * a))((((2 * e) - 1) * (3 - (4 * j))), 3 - (4 * j), ((1 - (2 * a)) * (3 - (4 * j)))) / 3(((((2 * e) - 1) * (3 - (2 * f))) * (3 - (2 * j))), ((3 - (2 * f)) * (3 - (2 * j))), ((1 - (2 * a)) * ((6 * f) + ((4 * f) * j) - (6 * j)))) / 9((((2 * e) - 1) * ((6 * b) + ((4 * b) * j) - (6 * j))), ((3 - (2 * b)) * (3 - (2 * j))), (((1 - (2 * a)) * (3 - (2 * b))) * (3 - (2 * j)))) / 9(((((2 * e) - 1) * (3 - (2 * d))) * (3 - (2 * j))), (6 * d) + ((4 * d) * j) - (6 * j), (((1 - (2 * a)) * (3 - (2 * d))) * (3 - (2 * j)))) / 9{Segment[A, J], Segment[A, U], Segment[U, J], Segment[A, E], Segment[E, J], Segment[E, U]}Tetraedro^(2){Segment[O, U], Segment[O, E], Segment[O, A], Segment[U, B], Segment[U, F], Segment[A, B], Segment[E, F], Segment[D, E], Segment[A, D], Segment[B, J], Segment[D, J], Segment[F, J]}{Polygon[U, E, A]}
AI Drawing Prompt Reference
Draw a parameterized rigid cube demonstrating dynamic construction via linkages, showcasing geometric transformations like rotation and translation. The cube's vertices are defined by parametric equations, with their motion paths visualized. The cube consists of multiple segments connecting key points and tetrahedra filling certain spaces, illustrating parameterized movement and locus.
The prompt above was compiled from the original drawing commands and is for reference only.