
Net of a Cylinder (Animated)
Loading the math board and drawing, please wait…
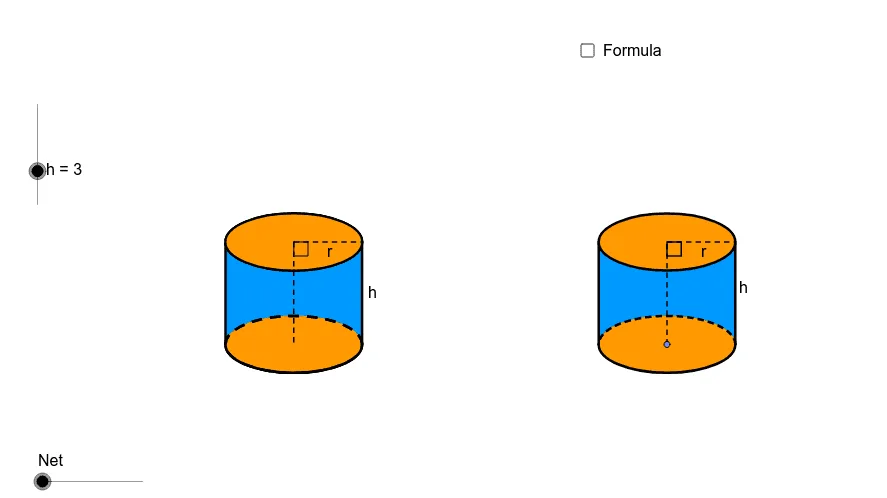
① This GeoGebra example demonstrates the unfolding of a cylinder into its net, showing how the 3D surface transforms into a 2D pattern. ② Core math concepts include solid geometry, nets of solids, and the relationship between circles, rectangles, and curved surfaces. ③ Construction uses commands such as Point, Circle, Intersect, Ellipse, Vector, Translate, Polygon, Arc, Segment, Angle, Line, Midpoint, If, Conic, OrthogonalLine, Center, Rotate, and Mirror to build the cylinder's bases, lateral surface, and the unfolded net, with sliders or animation controlling the unfolding. ④ Suitable for middle and high school geometry classes, especially for teaching surface area formulas and spatial visualization.
GeoGebra Commands & Parameters
Point(xAxis) → ACircle(A, r) → cIntersect(c, xAxis) → B, CEllipse(E, D, C) → eIntersect(xAxis, yAxis) → FVector(F, G) → uTranslate(B, Vector[u * h]) → B'_1Translate(C, Vector[u * h]) → C'_1Translate(A, Vector[u * h]) → A'Translate(e, Vector[u * h]) → e'_1Polygon(B'_1, B, C, C'_1) → poly1, b', b, c_1, c'Arc(e'_1, C'_1, B'_1) → fArc(e, B, C) → gArc(e, C, B) → kArc(e'_1, C'_1, B'_1) → p_5Arc(e'_1, B'_1, C'_1) → qArc(e, B, C) → sSegment(A', A) → h_6Segment(A', C'_1) → pAngle(A, A', C'_1) → αLine(A, A') → jIntersect(e'_1, j) → H, IIntersect(k, j) → J,Circle(I, r) → tIntersect(t, j, 2.0) → KCircle(K, I) → d_1Circle(J, r) → e_1Intersect(e_1, j, 1.0) → LCircle(L, J) → f_1Intersect(f_1, j, 2.0) → MIntersect(d_1, j, 2.0) → NIntersect(s, j) → O,Vector(H, N) → vVector(O, M) → wTranslate(H, Vector[v * n]) → H'_1Translate(D, Vector[u * h]) → D'Translate(E, Vector[u * h]) → E'Line(B, B'_1) → lLine(C, C'_1) → mIntersect(d_1, l, 1.0) → PIntersect(d_1, m, 1.0) → QVector(B'_1, P) → zVector(C'_1, Q) → u_1Translate(B'_1, Vector[z * n]) → B''Translate(C'_1, Vector[u_1 * n]) → C''Midpoint(B'_1, A') → RMidpoint(B, A) → SLine(R, S) → a_1Intersect(q, a_1) → T,Intersect(d_1, a_1, 1.0) → UVector(T, U) → v_1Translate(T, Vector[v_1 * n]) → T'Intersect(f_1, l, 1.0) → VIntersect(f_1, m, 1.0) → WIntersect(f_1, a_1, 2.0) → ZIntersect(s, a_1) → A_1,Vector(B, V) → w_1Vector(A_1, Z) → z_1Vector(C, W) → b_1Translate(B, Vector[w_1 * (n - 1.0)]) → B'Translate(A_1, Vector[z_1 * (n - 1.0)]) → C_1Translate(O, Vector[w * (n - 1.0)]) → O'Translate(C, Vector[b_1 * (n - 1.0)]) → C'If(n < 1.0, B'', P) → B_1If(n < 1.0, T', U) → D_1If(n < 1.0, H'_1, N) → E_1If(n < 1.0, C'', Q) → F_1Conic(B_1, D_1, E_1, F_1, I) → g_1Conic(I, B_1, D_1, E_1, F_1) → h_1If(n < 1.0, B, If[n < 2.0, B', V]) → G_1If(n < 1.0, A_1, If[n < 2.0, C_1, Z]) → H_1If(n < 1.0, O, If[n < 2.0, O', M]) → I_1If(n < 1.0, C, If[n < 2.0, C', W]) → J_1Conic(G_1, H_1, I_1, J_1, J) → k_1Vector(H, O) → i_1Translate(H, Vector[i_1 * (n - 2.0)]) → H'If(n < 2.0, H, If[n < 3.0, H', O]) → K_1Segment(H, K_1) → j_1Arc(e, B, C) → q_1Intersect(g, k_1) → M_1, N_1, R_1, S_1Arc(k_1, M_1, N_1) → r_1Arc(k_1, N_1, M_1) → p_1Arc(e, C, B) → s_1OrthogonalLine(I, j) → l_1OrthogonalLine(J, l) → m_1Circle(I, w_2) → t_1Intersect(t_1, l_1, 1.0) → L_1Intersect(t_1, l_1, 2.0) → O_1OrthogonalLine(O_1, l_1) → n_1OrthogonalLine(L_1, m_1) → a_2Intersect(m_1, n_1) → P_1Intersect(m_1, a_2) → Q_1Circle(H, r) → c_2Intersect(c_2, j, 2.0) → T_1Circle(T_1, H) → d_2OrthogonalLine(H, j) → b_2Intersect(d_2, l_1, 1.0) → U_1OrthogonalLine(T_1, j) → e_2Intersect(d_2, e_2, 1.0) → V_1Angle(U_1, T_1, V_1) → βCircle(L_1, r) → f_2Intersect(f_2, l_1, 2.0) → W_1Vector(I, W_1) → u_2Translate(d_2, Vector[u_2 * (n - 3.0)]) → g_2Center(g_2) → Z_1Intersect(g_2, b_2) → A_2, B_3Rotate(A_2, w_3, Z_1) → B_2If(n < 3.0, H, If[n < 4.0, B_2, L_1]) → C_2Mirror(C_2, j) → D_2Mirror(E_2, j) → F_2Midpoint(I, L_1) → G_2Intersect(m, l_1) → H_2Midpoint(H_2, C'_1) → I_2Vector(H_2, G_2) → v_2OrthogonalLine(C'_1, m) → i_2Polygon(D_2, F_2, E_2, C_2) → poly2, d_3, f_3, e_3, c_3Vector(C'_1, W_1) → z_2Translate(C'_1, Vector[z_2 * (n - 3.0)]) → J_2If(n < 3.0, C'_1, If[n < 4.0, J_2, W_1]) → K_2Mirror(K_2, j) → L_2Conic(D_2, L_2, I, K_2, C_2) → h_2Arc(h_2, B_2, D_2) → k_2Arc(h_2, B_2, D_2) → p_2Conic(F_2, N_2, J, M_2, E_2) → q_2Intersect(q_2, k_1) → O_2, P_2, Q_2, R_2Center(h_2) → S_2Center(q_2) → T_2OrthogonalLine(T_2, j) → j_2OrthogonalLine(S_2, j) → m_2Intersect(h_2, m_2) → U_2, V_2Intersect(q_2, j_2) → W_2, Z_2Polygon(U_2, D_2, F_2, W_2) → poly3, u_3, d_4, f_4, w_5Polygon(V_2, C_2, E_2, Z_2) → poly4, v_3, c_4, e_4, z_3Intersect(q_2, d_3, 2.0) → A_3Intersect(q_2, e_3, 2.0) → C_3Polygon(F_2, A_3, C_3, E_2) → poly5, f_5, a_3, c_5, e_5Arc(q_2, C_3, A_3) → s_2Arc(q_2, E_2, F_2) → t_2Arc(q_2, E_2, F_2) → g_3Segment(A_3, C_3) → l_2Intersect(k_1, l_2) → D_3, E_3Segment(E_3, A_3) → n_2Segment(D_3, C_3) → b_3Segment(F_2, E_2) → h_3Arc(k_1, D_3, E_3) → k_3Segment(E_3, D_3) → i_3Segment(D_2, C_2) → j_3Segment(L_2, K_2) → l_3Arc(q_2, W_2, F_2) → p_3Arc(q_2, E_2, Z_2) → q_3Arc(q_2, E_2, Z_2) → r_3Arc(q_2, W_2, F_2) → s_3Intersect(k_1, d_3) → F_3, J_3Intersect(k_1, e_3) → G_3, K_3Arc(k_1, G_3, F_3) → t_3Arc(k_1, F_3, R_2) → g_4Arc(k_1, O_2, G_3) → h_4Segment(F_2, E_2) → r_2Intersect(k_1, r_2) → H_3, I_3Segment(F_2, I_3) → m_3Segment(E_2, H_3) → n_3Arc(q_2, E_2, F_2) → k_4Arc(k_1, H_3, I_3) → p_4Segment(I_3, H_3) → a_4Segment(F_2, E_2) → b_4Segment(E_2, Z_2) → i_4Segment(D_2, F_2) → j_4Segment(C_2, E_2) → l_4Arc(k_1, N_1, M_1) → q_4Arc(k_1, N_1, M_1) → r_4Midpoint(j_4) → L_3Translate(e, Vector[u * h]) → e'Arc(k_1, M_1, N_1) → s_4Arc(k_1, R_2, N_1) → t_4Arc(k_1, R_2, O_2) → d_5Arc(k_1, P_2, Q_2) → g_5Center(h_1) → M_3Segment(M_3, F_1) → aMidpoint(c_1) → N_3Point(xAxis) → O_3Circle(O_3, r) → h_5Intersect(h_5, xAxis) → P_3, Q_3Ellipse(R_3, S_3, Q_3) → k_5OrthogonalLine(S_3, i_2) → iOrthogonalLine(Q_3, i_2) → m_4OrthogonalLine(P_3, i_2) → n_4OrthogonalLine(R_3, i_2) → a_5Intersect(i_2, a_5) → T_3Intersect(n_4, i_2) → U_3Intersect(i, i_2) → V_3Intersect(m_4, i_2) → W_3Ellipse(T_3, V_3, W_3) → q_5Polygon(U_3, W_3, Q_3, P_3) → poly6, u_4, w_6, q_6, p_6Ellipse(T_3, V_3, W_3) → r_5Arc(k_5, Q_3, P_3) → s_5Arc(k_5, P_3, Q_3) → t_5Center(q_5) → Z_3Segment(O_3, Z_3) → b_5Segment(Z_3, W_3) → i_5Angle(W_3, Z_3, O_3) → γIntersect(k_1, f_4) → A_4,Intersect(k_1, e_4) → B_4,Intersect(g_3, k_1) → C_4, D_4, E_4, F_4Polygon(Z_2, C_4, B_4) → poly7, b_6, z_4, c_6Polygon(F_4, A_4, W_2) → poly8, w_7, f_6, a_6Arc(q_2, W_2, F_4) → d_6Arc(q_2, C_4, Z_2) → e_6Arc(q_2, W_2, F_4) → g_6Arc(q_2, C_4, Z_2) → k_6Arc(k_1, G_3, J_3) → r_6Intersect(k_1, b) → G_4, H_4Segment(N_2, H_4) → j_5Segment(M_2, G_4) → l_5Segment(E_3, D_3) → m_5Segment(H_3, I_3) → n_5
AI Drawing Prompt Reference
Draw a cylinder's net, which consists of two circular bases and a rectangular side. Start by drawing a circle, then draw two points tangent to the circle, and use an ellipse to represent the side. Through translation and rotation, create the net, including the two circular bases and the rectangular side.
The prompt above was compiled from the original drawing commands and is for reference only.