
Motion Control
Loading the math board and drawing, please wait…
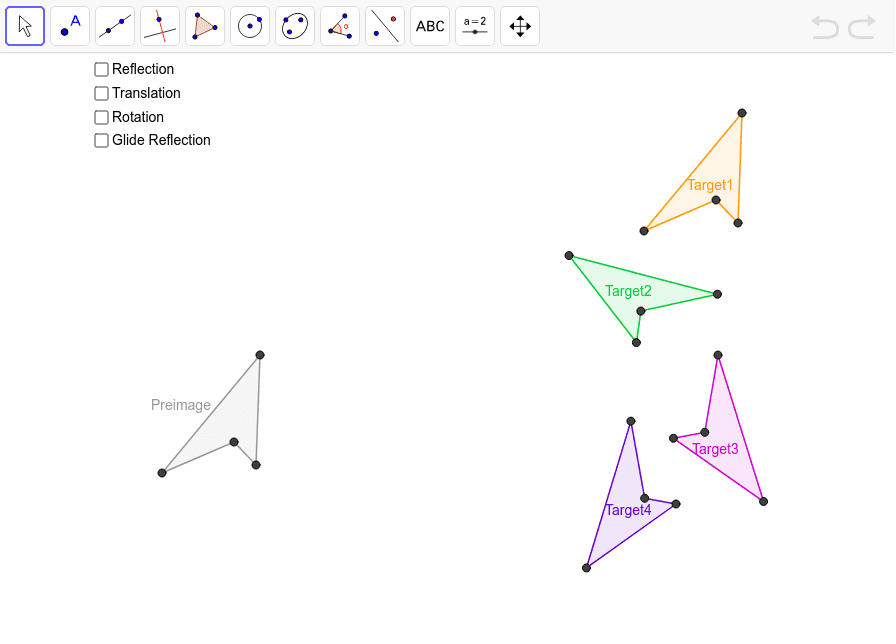
This example demonstrates how to recognize motions and the information needed for each using geometric transformations. It involves transformations, vectors, and point movements. Using GeoGebra commands such as Polygon, Translate, and Rotate, it dynamically shows the movement and transformation of points. Suitable for middle school and above students to learn about geometric transformations and motion control.
GeoGebra Commands & Parameters
Polygon(A, B, C, D) → poly1, a, b, c, dLine(E, F) → eMirror(A, e) → A'Mirror(B, e) → B'Mirror(C, e) → C'Mirror(D, e) → D'Polygon(A', B', C', D') → Preimage, a', b', c', d'Vector(G, H) → uTranslate(A', u) → A''Translate(B', u) → B''Translate(C', u) → C''Translate(D', u) → D''Polygon(A'', B'', C'', D'') → Target1, a'', b'', c'', d''Line(I, J) → fMirror(A', f) → A''_1Mirror(B', f) → B''_1Mirror(C', f) → C''_1Mirror(D', f) → D''_1Polygon(A''_1, B''_1, C''_1, D''_1) → Target2, a''_1, b''_1, c''_1, d''_1Circle(K, 2) → gPoint(g) → LSegment(K, L) → hPoint(g) → MSegment(K, M) → iAngle(L, K, M) → αRotate(A', α, K) → A''_2Rotate(B', α, K) → B''_2Rotate(C', α, K) → C''_2Rotate(D', α, K) → D''_2Polygon(A''_2, B''_2, C''_2, D''_2) → Target3, a''_2, b''_2, c''_2, d''_2Vector(N, O) → vTranslate(A', v) → A''_3Translate(B', v) → B''_3Translate(C', v) → C''_3Translate(D', v) → D''_3Polygon(A''_3, B''_3, C''_3, D''_3) → poly1''_3, a''_3, b''_3, c''_3, d''_3Line(N, O) → jMirror(A''_3, j) → PMirror(B''_3, j) → QMirror(C''_3, j) → RMirror(D''_3, j) → SPolygon(P, Q, R, S) → Target4, p, q, r, sVector(T, U) → wTranslate(A', w) → A''_4Translate(B', w) → B''_4Translate(C', w) → C''_4Translate(D', w) → D''_4Polygon(A''_4, B''_4, C''_4, D''_4) → Translated, a''_4, b''_4, c''_4, d''_4Circle(Center, 2) → tPoint(t) → WSegment(Center, W) → lPoint(t) → ZSegment(Center, Z) → mAngle(W, Center, Z) → AngleRotate(A', Angle, Center) → A''_5Rotate(B', Angle, Center) → B''_5Rotate(C', Angle, Center) → C''_5Rotate(D', Angle, Center) → D''_5Polygon(A''_5, B''_5, C''_5, D''_5) → Rotation, a''_5, b''_5, c''_5, d''_5Line(V, A_1) → LineMirror(A', Line) → A''_6Mirror(B', Line) → B''_6Mirror(C', Line) → C''_6Mirror(D', Line) → D''_6Polygon(A''_6, B''_6, C''_6, D''_6) → Reflection, a''_6, b''_6, c''_6, d''_6Vector(B_1, C_1) → zTranslate(A', z) → A''_7Translate(B', z) → B''_7Translate(C', z) → C''_7Translate(D', z) → D''_7Polygon(A''_7, B''_7, C''_7, D''_7) → Preimage', a''_7, b''_7, c''_7, d''_7Line(B_1, C_1) → a_1Mirror(A''_7, a_1) → D_1Mirror(B''_7, a_1) → E_1Mirror(C''_7, a_1) → F_1Mirror(D''_7, a_1) → G_1Polygon(D_1, E_1, F_1, G_1) → GlideReflection, d_1, e_1, f_1, g_1