
Heptagon Angle Sum Theorems Demo
Loading the math board and drawing, please wait…
In collections
Polygons & Angles
Polygons & Angles
Polygons & Angles ( s n attar)
Polygons & Angles
Polygons & Angles
Polygons & Angles
Polygons & Angles
Geometry: Polygons & Angles
Geometry: Polygons & Angles
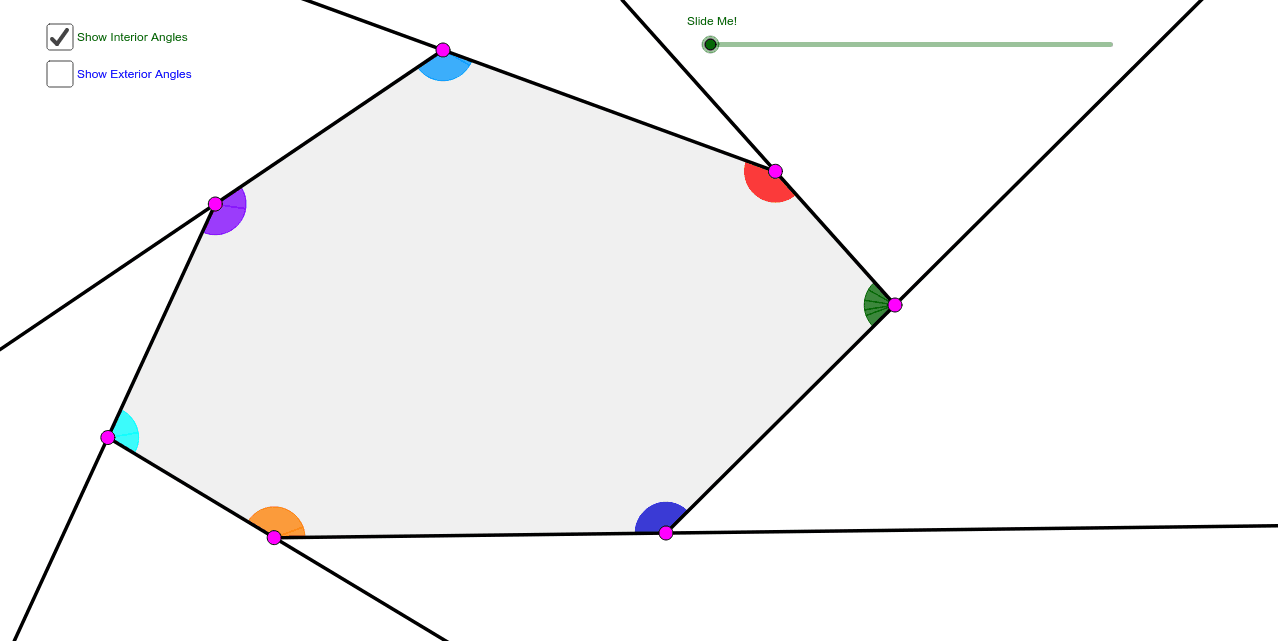
This applet informally illustrates to students that the sum of the measures of the interior angles of any heptagon is 180*5=900 degrees, and that the sum of the exterior angles is always 360 degrees. It covers core math concepts like polygon angle sum theorems, exterior angle properties, and angle calculations. The construction uses GeoGebra commands such as Ray, Circle, Intersect, Segment, CircleSector, Vector, Translate, Mirror, Dilate, If, Rotate, Polygon, and Point. Suitable for high school students learning polygon geometry and for classroom demonstrations.
GeoGebra Commands & Parameters
Ray(N_1, D) → l_4Circle(D, 1.5) → kIntersect(k, l_4) → W_1, Z_1Ray(D, A_1) → a_3Intersect(k, a_3, 1) → D_1Segment(C, A_1) → i_3Circle(C, 1.5) → hIntersect(h, i_3) → L,Ray(C, D) → cIntersect(h, c, 1) → PRay(A, B) → aRay(B, C) → bRay(E, A) → eCircle(A, 1.5) → fCircle(B, 1.5) → gCircle(E, 1.5) → pSegment(C, A) → iSegment(C, E) → jIntersect(f, a, 1) → FIntersect(f, i, 1) → GIntersect(f, e, 1) → HIntersect(f, e, 2) → IIntersect(p, e) → J,Intersect(p, j) → K,Intersect(k, c, 2) → OIntersect(h, j, 1) → QIntersect(h, i, 1) → RIntersect(h, b, 1) → SIntersect(g, a, 2) → TIntersect(g, b, 1) → UIntersect(g, a, 1) → VCircleSector(A, F, G) → qCircleSector(A, G, H) → rCircleSector(B, U, V) → sCircleSector(C, Q, R) → c_1CircleSector(C, R, S) → d_1Intersect(k, c, 1) → WCircleSector(E, J, K) → h_1CircleSector(A, I, F) → p_1CircleSector(B, T, U) → q_1Intersect(h, b, 2) → ZVector(A, B) → uVector(C, B) → vVector(E, D) → wVector(C, D) → u_1Vector(C, E) → v_1Vector(A, E) → w_1Translate(q, u) → q'Translate(d_1, v) → s_1Mirror(s_1, B) → t_1Dilate(A, If[0 < l ≤ 1, 1 - l, 0], B) → A'Dilate(C, If[0 < l ≤ 1, 1 - l, 0], B) → C'Dilate(A, If[1 < l ≤ 2, 2 - l, 0], E) → A'_1Dilate(C, If[1 < l ≤ 2, 2 - l, 0], E) → C'_1Dilate(C, If[2 < l ≤ 3, 3 - l, 0], D) → C'_2Dilate(E, If[2 < l ≤ 3, 3 - l, 0], D) → E'Vector(A, B) → a_1Vector(C, C') → b_1Vector(A, A'_1) → i_1Vector(E, E') → j_1Vector(C, C'_2) → l_1Vector(C, C'_1) → m_1Translate(d_1, b_1) → c_2Translate(r, i_1) → r'_1Translate(r, w_1) → r'_2Translate(c_1, v_1) → f_2Translate(c_1, m_1) → g_2CircleSector(C, P, L) → tTranslate(t, u_1) → t'Translate(t, l_1) → t'_1Translate(q, a_1) → r'Translate(d_1, b_1) → h_2If(0 < l < 1, Rotate[h_2, ((l * 180))°, C']) → k_2Vector(A, A') → n_1Translate(q, n_1) → q'_1Mirror(r'_2, E) → p_2If(1 < l < 2, Rotate[r'_1, (((l - 1) * 180))°, A'_1]) → q_2Ray(C, E) → i_2Vector(D, C) → u_2Vector(E, C) → v_2Vector(A, C) → w_2Vector(B, C) → l_2Dilate(B, If[0 < o < 1, 1 - o, 0], C) → B'Dilate(A, If[1 < o < 2, 2 - o, 0], C) → A'_2Dilate(E, If[2 < o < 3, 3 - o, 0], C) → E'_1Dilate(D, If[3 < o < 4, 4 - o, 0], C) → D'Vector(B, B') → m_2Vector(A, A'_2) → n_2Vector(E, E'_1) → s_2Vector(D, D') → t_2Translate(q_1, m_2) → c_3Translate(q_1, l_2) → d_3Translate(p_1, w_2) → e_3If(1 < o < 2, Translate[p_1, n_2]) → h_3Ray(A_1, E) → b_3Circle(A_1, 1.5) → q_3Intersect(q_3, i_3) → M,Intersect(q_3, b_3, 1) → NIntersect(q_3, a_3, 2) → B_1Intersect(k, c, 2) → C_1Intersect(k, c, 1) → E_1CircleSector(C, L, Q) → dIntersect(p, b_3, 1) → F_1Intersect(p, i_2) → G_1, H_2CircleSector(E, G_1, N) → e_1Dilate(E, If[2 < l < 3, 3 - l, 0], A_1) → E'_2Dilate(C, If[2 < l < 3, 3 - l, 0], A_1) → C'_3Dilate(C, If[3 < l < 4, 4 - l, 0], D) → C'_4Dilate(A_1, If[3 < l < 4, 4 - l, 0], D) → H_1Vector(E, A_1) → f_1Vector(C, A_1) → g_1Translate(e_1, f_1) → k_1Translate(d, g_1) → d'Vector(E, E'_2) → a_2Vector(C, C'_3) → b_2Translate(e_1, a_2) → d_2Translate(d, b_2) → d'_1Rotate(d_2, If[2 < l < 3, (((l - 2) * 180))°, 0], E'_2) → e_2Mirror(k_1, A_1) → r_2CircleSector(A_1, N, M) → f_3Intersect(q_3, a_3, 1) → I_1CircleSector(A_1, M, I_1) → g_3CircleSector(D, D_1, E_1) → k_3Vector(C, D) → j_2Vector(A_1, D) → u_3Translate(g_3, u_3) → p_3Translate(t, j_2) → t'_2Mirror(p_3, D) → r_3Vector(A_1, H_1) → v_3Vector(C, C'_4) → w_3Translate(g_3, v_3) → s_3Translate(t, w_3) → t'_3Rotate(s_3, If[3 < l < 4, (((l - 3) * 180))°, 0], H_1) → t_3Intersect(p, b_3, 2) → J_1Polygon(A, B, C) → poly1, c_4, a_4, b_4Polygon(A, C, E) → poly2, e_4, a_5, c_5Polygon(E, C, A_1) → poly3, a_6, e_5, c_6Polygon(A_1, C, D) → poly4, d_4, a_7, c_7Intersect(p, e, 1) → L_1CircleSector(E, J_1, L_1) → f_4CircleSector(A_1, B_1, N) → g_4Vector(E, C) → j_3Vector(A_1, C) → l_3Vector(D, C) → m_3Translate(f_4, j_3) → k_4Translate(g_4, l_3) → p_4CircleSector(D, Z_1, D_1) → h_4Translate(h_4, m_3) → q_4Dilate(E, If[2 < o < 3, 3 - o, 0], C) → E'_3Dilate(A_1, If[3 < o < 4, 4 - o, 0], C) → M_1Dilate(D, If[4 < o < 5, 5 - o, 0], C) → D'_1Vector(E, E'_3) → n_3Vector(A_1, M_1) → u_4Vector(D, D'_1) → v_4If(2 < o < 3, Translate[f_4, n_3]) → r_4If(3 < o < 4, Translate[g_4, u_4]) → s_4If(4 < o < 5, Translate[h_4, v_4]) → t_4Ray(C, N_1) → i_4Circle(N_1, 1.5) → d_5Intersect(d_5, i_4, 2) → K_1Intersect(d_5, l_4, 1) → O_1Intersect(d_5, i_4, 1) → P_1Intersect(h, i_4, 1) → Q_1CircleSector(C, Q_1, P) → f_5CircleSector(N_1, O_1, P_1) → g_5Intersect(k, l_4, 1) → R_1CircleSector(D, E_1, R_1) → h_5Dilate(D, If[4 < l < 5, 5 - l, 0], N_1) → D'_2Dilate(C, If[4 < l < 5, 5 - l, 0], N_1) → C'_5Vector(C, N_1) → w_4Vector(D, N_1) → j_4Translate(f_5, w_4) → k_5Translate(h_5, j_4) → p_5Mirror(p_5, N_1) → q_5Vector(D, D'_2) → m_4Vector(C, C'_5) → n_4Translate(h_5, m_4) → r_5Translate(f_5, n_4) → s_5Rotate(r_5, If[4 < l < 5, (((l - 4) * 180))°, 0], D'_2) → t_5Polygon(D, C, N_1) → poly5, n_5, d_6, c_8Segment(D, C) → b_5Ray(C, E) → i_5Ray(C, A_1) → j_5Ray(C, D) → l_5Point(j_5) → T_1Point(l_5) → U_1Ray(A_1, T_1) → m_5Ray(D, U_1) → b_6Polygon(A_1, E, A, B, C, N_1, D) → poly6, a_8, e_6, a_9, b_7, c_9, n_6, d_7Intersect(d_5, l_4, 1) → S_1Intersect(d_5, i_4, 2) → V_1CircleSector(N_1, V_1, S_1) → f_6CircleSector(C, Z, Q_1) → r_1Vector(N_1, C) → u_5Translate(f_6, u_5) → g_6Dilate(N_1, If[5 < o < 6, 6 - o, 0], C) → A_2Vector(N_1, A_2) → v_5Translate(f_6, v_5) → h_6Vector(D, C) → w_5Translate(h_4, w_5) → k_6