
Graphs of Motion
Loading the math board and drawing, please wait…
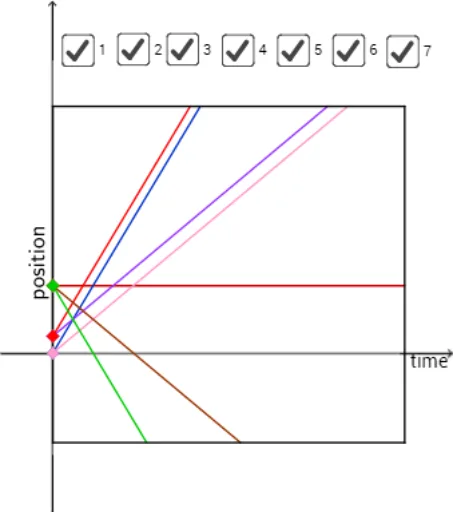
This example demonstrates the graphical representation of motion, including trajectories and velocity changes, through dynamic graphs. Key mathematical concepts involve functions, inequalities, parametric equations, and coordinate geometry. Construction highlights GeoGebra commands like Line, Point, OrthogonalLine, Intersect, Polygon, Segment, and RotateText. Ideal for high school students and enthusiasts exploring kinematics and graphical methods in mathematics.
GeoGebra Commands & Parameters
Line(C, xAxis) → iLine(D, i) → jPoint(i) → EOrthogonalLine(E, i) → kIntersect(j, k) → FPoint(i) → HOrthogonalLine(H, i) → lPoint(l) → IOrthogonalLine(I, l) → qPoint(l) → JOrthogonalLine(J, l) → rPoint(q) → LOrthogonalLine(L, q) → sIntersect(s, r) → MPolygon(I, L, M, J) → poly1, i_1, l_1, m_1, j_1Intersect(i, l_1) → NIntersect(j, l_1) → OIntersect(j_1, j) → PSegment(H, N) → t_1Segment(P, O) → cIntersect(d, i_1) → QIntersect(m_1, d) → RSegment(Q, R) → eLine(e_2, xAxis) → bLine(c_1, xAxis) → k_1Line(g_4, xAxis) → n_1Line(a_3, xAxis) → i_2Line(b_5, xAxis) → j_2Line(f_4, xAxis) → k_2Point(yAxis) → A_1OrthogonalLine(A_1, yAxis) → l_2Point(yAxis) → B_1OrthogonalLine(B_1, yAxis) → m_2Point(m_2) → C_1OrthogonalLine(C_1, m_2) → n_2Point(m_2) → D_1OrthogonalLine(D_1, m_2) → p_2Intersect(n_2, l_2) → E_1Intersect(p_2, l_2) → F_1Polygon(D_1, C_1, E_1, F_1) → poly2, d_5, c_2, e_3, f_5Intersect(i_2, n_2) → G_1Intersect(j_2, n_2) → H_1Intersect(b, n_2) → I_1Intersect(xAxis, n_2) → J_1Intersect(k_1, n_2) → K_1Intersect(k_2, n_2) → L_1Intersect(n_1, n_2) → M_1Intersect(n_1, p_2) → N_1Intersect(k_2, p_2) → O_1Intersect(k_1, p_2) → P_1Intersect(xAxis, b) → Q_1Intersect(xAxis, p_2) → R_1Intersect(b, j_2) → S_1Intersect(j_2, p_2) → T_1Intersect(b, p_2) → U_1Intersect(i_2, p_2) → V_1Segment(V_1, G_1) → q_2Segment(T_1, H_1) → r_2Segment(U_1, I_1) → s_2Segment(R_1, J_1) → t_2Segment(P_1, K_1) → a_2Segment(O_1, L_1) → b_2Segment(N_1, M_1) → h_3Segment(F_1, E_1) → i_3RotateText("position", 90°) → text4Intersect(d_5, yAxis) → TIntersect(e_3, i_3) → W_1Intersect(yAxis, e_3) → Z_1Polygon((0, -8), (21, -8), (21, 22), (0, 22)) → q1, k_3, l_3, m_3, n_3Segment(T, Z_1) → j_3
AI Drawing Prompt Reference
Draw a dynamic graph showing motion with trajectories and velocity changes. Start by plotting the x and y axes, then create a line segment on the x-axis and draw perpendicular lines to it. Find the intersections of these lines and connect the points to form polygons. Also, draw some horizontal line segments and locate their intersections. Finally, connect these intersection points to complete the graph.
The prompt above was compiled from the original drawing commands and is for reference only.