
Dynamic and Modifiable Composite Solid
Loading the math board and drawing, please wait…
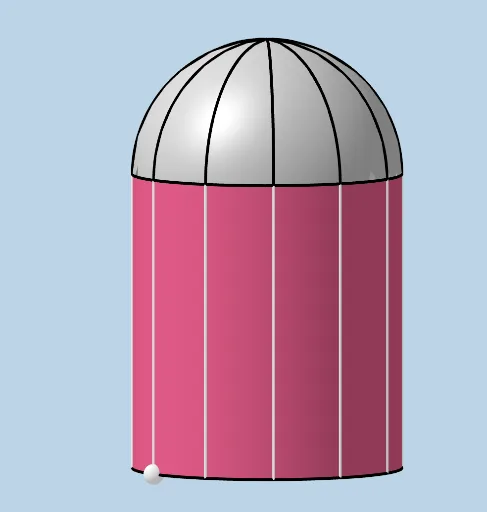
This example demonstrates a dynamic and modifiable composite solid, showcasing the combination of different geometric shapes through parameter adjustments. Core mathematical concepts include solid geometry, similar triangles, piecewise functions, histograms, difference and slope, and trigonometry. The construction leverages GeoGebra commands and objects such as Ray, Point, Cylinder, Circle, CircleArc, Intersect, Vector, Translate, and Segment. Suitable for high school and above, it serves as a comprehensive teaching tool for solid geometry, functions, and geometric integrations.
GeoGebra Commands & Parameters
Ray((0, 0, 0), (0, 0, 1)) → fPoint(f) → BCylinder(C, B, r) → a, d, e, bCircle(f, D) → gCircle(f, A) → kCircleArc(B, D, R) → qIntersect(f, q, 1) → SCircleArc(B, S, K) → sCircleArc(B, F, S) → pCircleArc(B, S, L) → tCircleArc(B, G, S) → c_1CircleArc(B, S, M) → d_1CircleArc(B, H, S) → e_1CircleArc(B, S, N) → f_1Intersect(f_1, p, 2) → QCircleArc(B, I, Q) → g_1CircleArc(B, Q, O) → h_1Intersect(h_1, p, 2) → TCircleArc(B, J, T) → k_1CircleArc(B, T, P) → p_1Vector(D, A) → uTranslate(F, u) → F'Translate(G, u) → G'Translate(H, u) → H'Translate(H, u) → H'_1Translate(I, u) → I'Translate(J, u) → J'Translate(K, u) → K'Translate(L, u) → L'Translate(M, u) → M'Translate(g, u) → g'Translate(O, u) → O'Translate(N, u) → N'Translate(P, u) → P'Translate(D, u) → D'Segment(G, G') → hSegment(H, H'_1) → mSegment(I, I') → nSegment(J, J') → i_1Segment(K, K') → j_1Segment(L, L') → l_1Segment(M, M') → m_1Segment(N, N') → n_1Segment(O, O') → q_1Segment(P, P') → r_1Segment(D, A) → s_1Segment(F, F') → t_1