
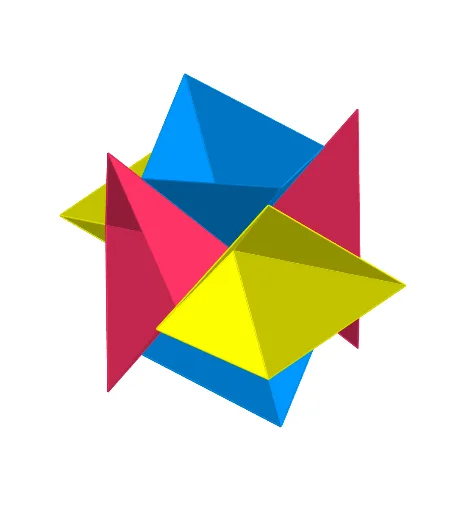
BeakUnit: Skeletal Cuboctahedron (6 units)
Loading the math board and drawing, please wait…
In collections
Action Modular Origami
① This example demonstrates an animated rotating model of a skeletal cuboctahedron folded from six beak units, showcasing the spatial structure of a polyhedral framework. ② Core mathematical concepts include solid geometry of Archimedean solids—specifically the cuboctahedron with 8 triangular and 6 square faces—and the geometric connections between origami units. ③ Construction highlights: based on the construction summary, GeoGebra commands such as Intersect, Point, Cube, Midpoint, Polygon, Line, Rotate, Plane, Mirror, Translate, Angle, and OrthogonalLine are used to build a cube and its faces, edges, midpoints, then generate the skeletal polyhedron via rotations and translations. ④ Suitable for high school or early college students for spatial visualization training in solid geometry, and as a visual aid for origami mathematics and polyhedra education.
GeoGebra Commands & Parameters
Intersect(zAxis, yAxis) → APoint(xAxis) → BPoint(Circle[B, Distance[A, B], Segment[A, B]]) → CCube(A, B, C) → a, D, faceCDHG, faceEFGH, edgeAD, edgeAB, edgeBC, edgeCD, edgeAE, edgeDH, edgeEH, edgeEF, E, edgeBF, edgeFG, edgeCG, edgeGH, F, G, H, faceABCD, faceADHE, faceABFE, faceBCGFMidpoint(E, F) → IMidpoint(F, G) → JMidpoint(F, B) → KPolygon(I, K, J) → poly1, j, i, kMidpoint(A, G) → OOPolygon(K, I, 4, faceABFE) → poly2, f, g, h, l, L, MLine(OO, F) → mRotate(poly2, 120°, m) → poly2'Line(N, I) → nPlane(I, N, M) → bPoint(n) → ORotate(O, (-rot), N, b) → O'Polygon(O', OO, K) → poly3, p, q, rPlane(L, K, OO) → cMirror(poly3, c) → poly3'Mirror(poly3, b) → poly3'_1Mirror(poly3', b) → poly3''Midpoint(B, C) → PPlane(OO, J, P) → dTranslate({poly3, poly3', poly3'', poly3'_1}, Vector[OO, OO]) → polyList1Mirror(polyList1, d) → polyList1'Translate({polyList1, polyList1'}, Vector[OO, OO]) → polyList11Angle(O, K, OO) → αOrthogonalLine(N, xOyPlane) → sRotate(polyList11, β, s) → polyList11'_2Rotate(Rotate[polyList11, 240°, m], β, s) → polyList11'_1Rotate(Rotate[polyList11, 120°, m], β, s) → polyList11'
AI Drawing Prompt Reference
Draw an animated rotating model of a skeletal cuboctahedron folded from six beak units, showcasing its spatial structure. The model should include a cube with its faces, edges, and midpoints, then generate the skeletal polyhedron via rotations and reflections to highlight geometric connections. The model should rotate around a central axis to observe its solid geometry structure.
The prompt above was compiled from the original drawing commands and is for reference only.