
Animation Demonstrating Polygon and Circle Relationships
Loading the math board and drawing, please wait…
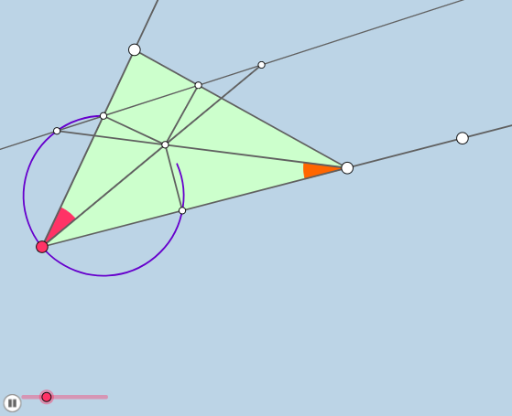
This example demonstrates the construction and properties of circumcircles and incircles of polygons through animation. It involves core mathematical concepts like circumcircle, incircle, polygon, angle, vector, etc. Key GeoGebra commands and objects used include Rotate, Circle, Intersect, Polygon, etc., as listed in the construction summary. Suitable for high school and above students to understand geometric relationships between polygons and circles, as well as animation techniques.
GeoGebra Commands & Parameters
Rotate(B_2, (a * π / 180), A) → B'Ray(A, B') → gPoint(g) → BSegment(A, B) → jRay(A, B_2) → fPoint(f) → CSegment(B, C) → hSegment(A, C) → iMin({i, j, h}) → bAngle(B_2, A, B') → αCircle(C, (0.2 * b)) → dCircle(B, 4) → cIntersect(c, g, 2) → E_2Intersect(d, f, 2) → F_2Ray(C, F_2) → kRay(B, E_2) → lCircle(B, (0.2 * b)) → eCircle(C, (0.15 * b)) → pAngle(F_2, C, B) → βAngle(C, B, E_2) → γRotate(F_2, β / 2, C) → F'Angle(F_2, C, F') → δRotate(C, γ / 2, B) → D'Angle(C, B, D') → εRay(B, D') → mRay(C, F') → nIntersect(e, m, 1) → G_2Intersect(e, h, 1) → H_2Intersect(p, h, 1) → IPolygon(A, C, B) → poly1, c_2, a_1, d_2Dilate(A, If[0 < o ≤ 1, 1 - o, 0], C) → A'Dilate(A, If[0 < o ≤ 1, 1 - o, 0], B) → A'_1Segment(A, A') → k_1Segment(A, A'_1) → l_1Min(c_2, d_2) → wCircle(A, (0.15 * w)) → e_2Segment(A, B) → m_2Intersect(e_2, m_2) → S,Segment(A, C) → n_2Intersect(e_2, n_2) → T,Min({h, k_1, l_1}) → b_1Intersect(d, h, 1) → UIntersect(e, h) → W,Angle(A, B, C) → λAngle(B, C, A) → κRotate(A, λ / 2, B) → A'_2Angle(A, B, A'_2) → ιRay(B, A'_2) → t_1Rotate(B, κ / 2, C) → C'_1Angle(B, C, C'_1) → μ_1Ray(C, C'_1) → f_2Intersect(d, f_2) → A_1,CircleSector(C, U, A_1) → r_2Intersect(t_1, f_2) → OOrthogonalLine(O, k_1) → s_2OrthogonalLine(O, l_1) → t_2Intersect(s_2, k_1) → EIntersect(t_2, l_1) → FIntersect(k_1, t_1) → D_1Circle(A, (0.2 * b)) → q_2Angle(C, A, B) → μRotate(C, μ / 2, A) → D'_2Angle(C, A, D'_2) → νRay(A, D'_2) → a_2Intersect(q_2, a_2) → V,Intersect(q_2, k_1) → E_1,CircleSector(A, E_1, V) → p_2Dilate(C, If[1 < o ≤ 2, 2 - o, 0], O) → D'_3Dilate(A, If[1 < o ≤ 2, 2 - o, 0], O) → A'_3Segment(A, A'_3) → b_2Segment(C, D'_3) → f_3Rotate(r_2, If[2.5 < o ≤ 3.5, ((o - 2.5) * κ / 2), κ / 2], C) → c_3Rotate(p_2, If[3.5 < o ≤ 4.5, ((o - 3.5) * μ / 2), μ / 2], A) → d_3Dilate(O, If[5 < o ≤ 6, 6 - o, 0], F) → Z'Dilate(O, If[5 < o ≤ 6, 6 - o, 0], E) → Z'_1Segment(O, Z') → g_3Segment(O, Z'_1) → h_3Angle(O, E, A) → ξAngle(A, F, O) → οCircle(O, Z') → e_3Rotate(F, If[6 < o ≤ 9, (((o - 6) * 2) * π / 3), (2 * π)], O) → F_1Segment(B, D_1) → i_3Intersect(e, i_3) → G_1,Intersect(e, l_1) → H_1,Dilate(B, If[9.5 < o ≤ 10.5, 10.5 - o, 0], O) → C'_2Polygon(A, O, B) → poly2, c_4, a_3, z_1CircleArc(O, Z', F_1) → k_3OrthogonalLine(O, h) → qIntersect(q, h) → DLine(A, O) → rLine(F, D) → sIntersect(r, s) → HLine(C, O) → tIntersect(s, t) → GDilate(O, If[5 < o ≤ 6, 6 - o, 0], D) → O'Segment(O, O') → f_1Angle(O, D, C) → ζCircle(A, G, F) → c_1Circle(C, H, D) → d_1Ray(D, H) → g_1Ray(F, G) → h_1Dilate(F, If[9 < o ≤ 10, 10 - o, 0], D) → F'_1Segment(F, F'_1) → i_1Dilate(O, If[10 < o ≤ 11, 11 - o, 0], H) → O'_1Segment(O, O'_1) → j_1Dilate(O, If[10 < o ≤ 11, 11 - o, 0], G) → O'_2Segment(O, O'_2) → m_1Center(c_1) → JRotate(F, If[11 < o ≤ 13, ((o - 11) * π), (2 * π)], J) → F'_2CircleArc(J, F, F'_2) → e_1Center(d_1) → KRotate(D, If[13 < o ≤ 15, ((o - 13) * π), (2 * π)], K) → D'_1CircleArc(K, D, D'_1) → p_1Dilate(E, If[15 < o ≤ 16, 16 - o, 0], H) → F'_3Dilate(E, If[15 < o ≤ 16, 16 - o, 0], G) → E'Segment(E, F'_3) → n_1Segment(E, J) → q_1Segment(E, E') → r_1Angle(G, H, E) → τAngle(H, G, E) → θLine(A, h_1) → s_1Intersect(d_1, s_1, 1) → LLine(B, A) → g_2Point(g_2) → MPolygon(E, H, G) → poly3, g_4, e_4, h_2Angle(L, A, B) → ρDilate(A, If[16 < o ≤ 17, 17 - o, 0], G) → A'_4Vector(A, A'_4) → uTranslate(d_3, u) → k_2Rotate(k_2, If[17 < o ≤ 18, ((-(o - 17)) * ρ), (-ρ)], G) → p_3Midpoint(A, G) → NDilate(A, If[18 < o ≤ 19, 19 - o, 0], N) → A'_5Vector(A, A'_5) → vTranslate(d_3, v) → q_3Rotate(q_3, If[19 < o ≤ 20, ((-(o - 19)) * (ρ + θ / 2)), (-(ρ + θ / 2))], N) → r_3Dilate(N, If[20 < o ≤ 21, 21 - o, 0], G) → N'Vector(N, N') → u_1Translate(r_3, u_1) → s_3Line(C, g_1) → i_2Intersect(d_1, i_2, 2) → PMidpoint(C, H) → QAngle(O, C, P) → σDilate(C, If[21 < o ≤ 22, 22 - o, 0], H) → C'Vector(C, C') → v_1Translate(c_3, v_1) → t_3Rotate(t_3, If[22 < o ≤ 23, ((o - 22) * σ), σ], H) → d_4Dilate(C, If[23 < o ≤ 24, 24 - o, 0], Q) → C'_3Vector(C, C'_3) → w_1Translate(c_3, w_1) → f_4Rotate(f_4, If[24 < o ≤ 25, ((o - 24) * (σ + τ / 2)), σ + τ / 2], Q) → h_4Dilate(Q, If[25 < o ≤ 26, 26 - o, 0], H) → Q'Vector(Q, Q') → u_2Translate(h_4, u_2) → k_4Circle(A, G, H) → p_4Center(p_4) → RRotate(H, If[26 < o ≤ 28, ((o - 26) * π), (2 * π)], R) → H'CircleArc(R, H, H') → q_4Distance(A, R) → distanceARDistance(R, C) → distanceRC