
Animation Demonstrating Geometric Transformations and Function Graphs
Loading the math board and drawing, please wait…
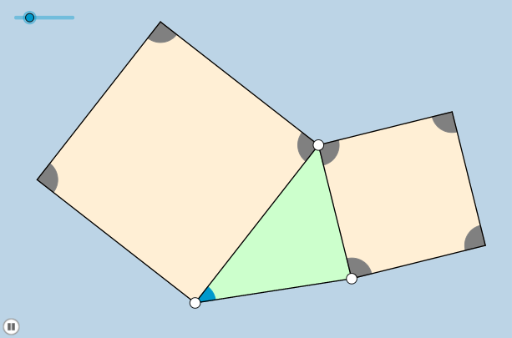
This example demonstrates geometric transformations such as rotation, translation, and dilation through animations, integrating function graphs and trigonometric relationships. Core mathematical concepts include angles, vectors, geometric transformations, trigonometry, and analytical geometry. The construction utilizes commands and objects like Rotate, Ray, Point, Segment, Midpoint, Polygon, Angle, Circle, Intersect, Line, CircleSector, Dilate, Vector, Translate in GeoGebra. Suitable for high school and above learners to understand the connection between geometric transformations and function graphs, enhancing spatial reasoning and logical thinking.
GeoGebra Commands & Parameters
Rotate(A, (a * π / 180), B) → A'Ray(B, A') → gPoint(g) → CRotate(A, If[0 < u ≤ 1, (u * π / 2), π / 2], C) → A'_1Rotate(C, If[0 < u ≤ 1, (u * π / 2), π / 2], C) → C'Segment(C', A'_1) → i'Midpoint(i') → VPolygon(C, A, 4) → poly1, j, k, l, m, D, EAngle(A, B, A') → αSegment(A, B) → fSegment(B, C) → hSegment(C, A) → iPolygon(B, C, 4) → poly2, n, p, q, r, F, GAngle(poly2) → β, γ, δ, εAngle(poly1) → ζ, η, θ, ιSegment(C, E) → sSegment(E, D) → tSegment(D, A) → bSegment(B, G) → cSegment(G, F) → dSegment(F, C) → eMin(i, h) → oCircle(E, (0.15 * o)) → c_1Polygon(B, A, C) → poly3, c_2, b_1, a_1Intersect(c_1, s, 1) → HIntersect(c_1, t, 1) → ILine(B, E) → f_1Line(A, F) → g_1Line(G, D) → h_1Intersect(g_1, f_1) → JCircle(A, (0.15 * o)) → d_1Intersect(d_1, b, 1) → KIntersect(d_1, i, 1) → LCircleSector(A, K, L) → e_1Rotate(B, If[0 < u ≤ 1, (u * π / 2), π / 2], B) → B'Rotate(C, If[0 < u ≤ 1, (u * π / 2), π / 2], B) → C'_1Segment(B', C'_1) → h'Rotate(B', If[1 < u ≤ 2, ((u - 1) * π / 2), π / 2], G) → B''Rotate(C'_1, If[1 < u ≤ 2, ((u - 1) * π / 2), π / 2], G) → MSegment(B'', M) → h''Rotate(C', If[1 < u ≤ 2, ((u - 1) * π / 2), π / 2], E) → C''Rotate(A'_1, If[1 < u ≤ 2, ((u - 1) * π / 2), π / 2], E) → NSegment(C'', N) → i''Rotate(C'', If[2 < u ≤ 3, ((u - 2) * π / 2), π / 2], D) → C'''Rotate(N, If[2 < u ≤ 3, ((u - 2) * π / 2), π / 2], D) → N'Segment(C''', N') → i'''Rotate(B'', If[2 < u ≤ 3, ((u - 2) * π / 2), π / 2], F) → B'''Rotate(M, If[2 < u ≤ 3, ((u - 2) * π / 2), π / 2], F) → M'Segment(B''', M') → h'''Dilate(A, If[3.5 < u ≤ 4.5, 4.5 - u, 0], D) → A'_2Vector(A, A'_2) → vTranslate(e_1, v) → k_1Dilate(A, If[3.5 < u ≤ 4.5, 4.5 - u, 0], C) → A'_3Vector(A, A'_3) → wTranslate(e_1, w) → p_1Line(C, A) → i_1Point(i_1) → OAngle(O, C, F) → κRotate(p_1, If[4.5 < u ≤ 5.5, ((u - 4.5) * (π / 2 + κ)), π / 2 + κ], C) → q_1Rotate(k_1, If[4.5 < u ≤ 5.5, ((u - 4.5) * π / 2), π / 2], D) → r_1Dilate(D, If[5.5 < u ≤ 6.5, 6.5 - u, 0], E) → D'Dilate(C, If[5.5 < u ≤ 6.5, 6.5 - u, 0], F) → C'_2Vector(C, C'_2) → u_1Vector(D, D') → v_1Translate(r_1, v_1) → s_1Translate(q_1, u_1) → t_1Rotate(s_1, If[6.5 < u ≤ 7.5, ((u - 6.5) * π / 2), π / 2], E) → d_2Rotate(t_1, If[6.5 < u ≤ 7.5, ((u - 6.5) * π / 2), π / 2], F) → e_2Dilate(F, If[7.5 < u ≤ 8.5, 8.5 - u, 0], G) → F'Dilate(E, If[7.5 < u ≤ 8.5, 8.5 - u, 0], V) → E'Vector(E, E') → w_1Vector(F, F') → j_1Translate(d_2, w_1) → f_2Translate(e_2, j_1) → g_2Rotate(g_2, If[8.5 < u ≤ 9.5, ((u - 8.5) * π / 2), π / 2], G) → h_2Circle(G, 2) → p_2Circle(D, 2) → q_2Circle(F, 2) → r_2Intersect(r_2, g_1, 2) → PIntersect(p_2, h_1, 1) → QIntersect(d_1, g_1, 1) → RIntersect(q_2, h_1, 2) → SRay(D, S) → l_1Ray(G, Q) → m_1Ray(F, P) → n_1Ray(A, R) → i_2Circle(B, 2) → s_2Intersect(s_2, f_1, 1) → TIntersect(c_1, f_1, 2) → URay(B, T) → j_2Ray(E, U) → l_2Rotate(f_2, If[8.5 < u ≤ 9.5, ((u - 8.5) * π / 2), π / 2], V) → k_2Dilate(V, If[9.5 < u ≤ 10.5, 10.5 - u, 0], C) → V'Vector(V, V') → u_2Translate(k_2, u_2) → t_2Dilate(B, If[11 < u ≤ 12, 12 - u, 0], E) → B'_1Segment(B, B'_1) → m_2Dilate(A, If[12 < u ≤ 13, 13 - u, 0], J) → A'_4Segment(A, A'_4) → n_2Dilate(J, If[13 < u ≤ 14, 14 - u, 0], F) → J'Segment(J, J') → a_2Dilate(G, If[14 < u ≤ 15, 15 - u, 0], J) → G'Segment(G, G') → b_2Circle(J, (0.15 * o)) → c_3Intersect(c_3, g_1, 1) → WIntersect(c_3, h_1, 2) → ZSector(c_3, W, Z) → d_3Dilate(JJ, If[15 < u ≤ 16, 16 - u, 0], D) → JJ'Segment(JJ, JJ') → f_3Line(G, n_2) → g_3Point(g_3) → A_1Line(G, j_2) → h_3Angle(F, G, A_1) → λRotate(h_2, If[16 < u ≤ 17, ((u - 16) * λ), λ], G) → e_3Dilate(G, If[17 < u ≤ 18, 18 - u, 0], JJ) → G'_1Vector(G, G'_1) → v_2Translate(e_3, v_2) → k_3Angle(A, JJ, D) → μRotate(W, If[18 < u ≤ 19, ((u - 18) * π / 4), π / 4], JJ) → W'CircleSector(JJ, W, W') → p_3Rotate(p_3, If[19.5 < u ≤ 20.5, ((u - 19.5) * π / 4), π / 4], JJ) → q_3Circle(B, (0.15 * o)) → r_3Intersect(r_3, f, 1) → B_1Intersect(r_3, h, 1) → C_1CircleSector(B, B_1, C_1) → s_3