
Animated Cube Net by GeoGebra Materials Team
Loading the math board and drawing, please wait…
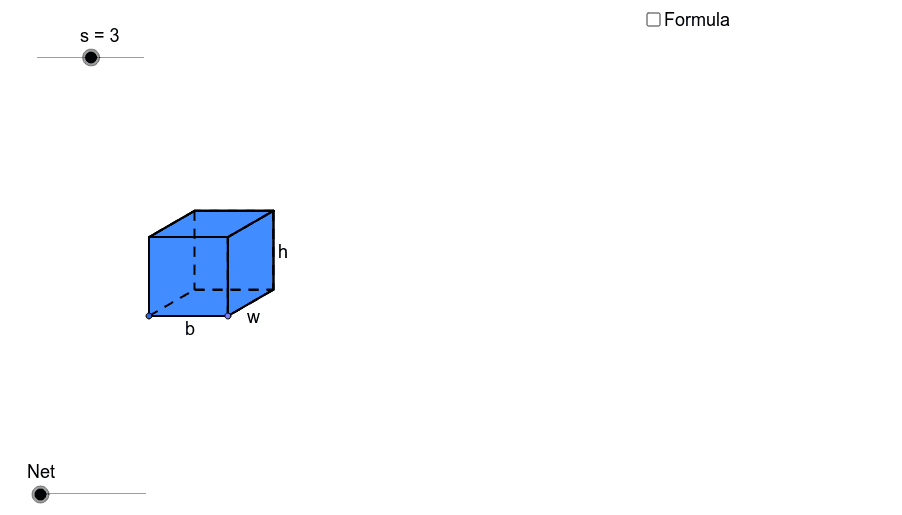
This example demonstrates the dynamic transformation of a cube's net, illustrating geometric principles. It involves core concepts like solid geometry, polygon construction, and spatial transformations. The construction utilizes GeoGebra commands such as Point, Segment, Polygon, Circle, Line, Intersect, Rotate, OrthogonalLine, CircleArc, Vector, Translate, Ray, LineBisector, If, and Midpoint. Ideal for high school mathematics education or geometric learning, it provides an intuitive understanding of cube structures and net properties.
GeoGebra Commands & Parameters
Point(Circle[A, s]) → BSegment(A, B) → aPolygon(A, B, 4.0) → poly1, a_1, b, c, d, C, DCircle(B, e) → fLine(A, B) → gIntersect(f, g, 2.0) → ERotate(E, 30.0*°, B) → E'OrthogonalLine(E', g) → hSegment(B, E') → iLine(C, i) → jIntersect(h, j) → FPolygon(E', F, 4.0) → poly2, e', f_1, k, l, G, HPolygon(A, H, G, D) → poly3, a_2, h_1, g_1, d_1Polygon(C, F, E', B) → poly4, c_1, f_2, e'_1, b_1Circle(B, A) → pCircle(A, B) → qIntersect(q, g, 2.0) → IIntersect(p, g, 2.0) → JCircle(J, B) → rIntersect(r, g, 2.0) → KLine(J, e'_1) → mLine(K, e'_1) → nLine(I, a_2) → tLine(H, E') → e_1Intersect(t, e_1) → LIntersect(m, e_1) → MIntersect(n, e_1) → NLine(B, E') → i_1Line(A, H) → j_1Intersect(f, i_1, 2.0) → OLine(O, g) → k_1Circle(E', B) → p_1Intersect(p_1, i_1, 2.0) → PLine(P, e_1) → l_1Intersect(j_1, l_1) → QLine(C, B) → m_1Circle(C, B) → q_1Intersect(q_1, m_1, 2.0) → RLine(R, c_1) → n_1Intersect(h, n_1) → SIntersect(j_1, k_1) → TCircleArc(C, R, D) → r_1CircleArc(B, K, R) → s_1CircleArc(E', N, S) → t_1CircleArc(E', M, F) → c_2CircleArc(B, J, C) → d_2CircleArc(A, B, I) → e_2CircleArc(H, G, L) → g_2CircleArc(F, S, G) → h_2Vector(F, P) → uVector(C, O) → vVector(D, R) → wVector(S, N) → u_1Vector(D, I) → v_1Translate(D, Vector[o * w]) → D'_1Ray(C, D'_1) → b_2Intersect(r_1, b_2, 1.0) → UTranslate(G, Vector[o * w]) → G'_1Ray(F, G'_1) → i_2Intersect(h_2, i_2, 1.0) → VLineBisector(F, P) → j_2Intersect(f, j_2, 2.0) → WCircleArc(W, P, F) → k_2Line(W, l_1) → l_2LineBisector(G, Q) → m_2Intersect(l_2, m_2) → ZCircleArc(Z, Q, G) → p_2Translate(C, Vector[(o - 1.0) * v]) → C'Translate(D, Vector[(o - 1.0) * v]) → D'_2If(o < 1.0, C, If[o < 2.0, C', O]) → A_1If(o < 1.0, D, If[o < 2.0, D'_2, T]) → B_1Translate(D, Vector[(o - 2.0) * v_1]) → D'Translate(G, Vector[(o - 2.0) * v_1]) → G'_2Ray(A, D') → n_2Ray(H, G'_2) → q_2Intersect(e_2, n_2, 1.0) → C_1Intersect(g_2, q_2) → D_1,If(o < 2.0, G, If[o < 3.0, D_1, L]) → E_1If(o < 2.0, D, If[o < 3.0, C_1, I]) → F_1Translate(G, Vector[(o - 3.0) * u]) → G'Translate(F, Vector[(o - 3.0) * u]) → F'Ray(H, G') → r_2Ray(E', F') → s_2Intersect(p_2, r_2, 1.0) → G_1Intersect(k_2, s_2, 1.0) → H_1If(o < 3.0, G, If[o < 4.0, G_1, Q]) → I_1If(o < 3.0, F, If[o < 4.0, H_1, P]) → J_1Translate(S, Vector[(o - 4.0) * u_1]) → S'Ray(E', S') → t_2Intersect(t_1, t_2, 1.0) → K_1Intersect(c_2, t_2, 1.0) → L_1Translate(R, Vector[(o - 4.0) * u_1]) → R'Ray(B, R') → a_3Intersect(s_1, a_3, 1.0) → M_1Intersect(d_2, a_3, 1.0) → N_1If(o < 1.0, U, If[o < 4.0, R, If[o < 5.0, M_1, K]]) → O_1If(o < 1.0, V, If[o < 4.0, S, If[o < 5.0, K_1, N]]) → P_1If(o < 4.0, C, If[o < 5.0, N_1, J]) → Q_1If(o < 4.0, F, If[o < 5.0, L_1, M]) → R_1Midpoint(B, E') → S_1Midpoint(A, H) → T_1Line(T_1, S_1) → c_3Circle(S_1, a / 2.0) → d_3OrthogonalLine(S_1, c_3) → g_3Intersect(d_3, g_3) → U_1, V_1Polygon(U_1, V_1, 4.0) → poly11, u_2, v_2, k_3, l_3, W_1, Z_1Polygon(Z_1, W_1, 4.0) → poly12, z_1, w_1, m_3, n_3, A_2, B_2Polygon(U_1, Z_1, 4.0) → poly13, u_3, z_2, s_3, t_3, C_2, D_2Polygon(W_1, V_1, 4.0) → poly14, w_2, v_3, c_4, d_4, E_2, F_2Polygon(V_1, U_1, 4.0) → poly15, v_4, u_4, e_4, f_4, G_2, H_2Polygon(H_2, G_2, 4.0) → poly16, h_6, g_4, i_4, j_4, I_2, J_2Segment(B, U_1) → m_4LineBisector(m_4) → n_4Vector(B, U_1) → zVector(T, C_2) → z_4Vector(L, A_2) → u_5Vector(P, E_2) → w_5Translate(I, Vector[z * (o - 5.0)]) → I'Translate(A, Vector[z * (o - 5.0)]) → A'Translate(B, Vector[z * (o - 5.0)]) → B'Translate(J, Vector[z * (o - 5.0)]) → J'Translate(K, Vector[z * (o - 5.0)]) → K'Translate(L, Vector[u_5 * (o - 5.0)]) → L'Translate(H, Vector[u_5 * (o - 5.0)]) → H'Translate(E', Vector[u_5 * (o - 5.0)]) → E''Translate(M, Vector[u_5 * (o - 5.0)]) → M'Translate(N, Vector[u_5 * (o - 5.0)]) → N'Translate(T, Vector[z_4 * (o - 5.0)]) → T'Translate(O, Vector[z_4 * (o - 5.0)]) → O'Translate(P, Vector[w_5 * (o - 5.0)]) → P'Translate(Q, Vector[w_5 * (o - 5.0)]) → Q'If(o < 5.0, O_1, If[o < 6.0, K', I_2]) → K_2If(o < 5.0, P_1, If[o < 6.0, N', J_2]) → L_2If(o < 5.0, Q_1, If[o < 6.0, J', G_2]) → M_2If(o < 5.0, R_1, If[o < 6.0, M', H_2]) → N_2If(o < 5.0, E', If[o < 6.0, E'', V_1]) → O_2If(o < 5.0, H, If[o < 6.0, H', W_1]) → P_2If(o < 5.0, E_1, If[o < 6.0, L', A_2]) → Q_2If(o < 5.0, J_1, If[o < 6.0, P', E_2]) → R_2If(o < 5.0, I_1, If[o < 6.0, Q', F_2]) → S_2If(o < 5.0, B, If[o < 6.0, B', U_1]) → T_2If(o < 5.0, A, If[o < 6.0, A', Z_1]) → U_2If(o < 5.0, A_1, If[o < 6.0, O', D_2]) → V_2If(o < 5.0, B_1, If[o < 6.0, T', C_2]) → W_2If(o < 5.0, F_1, If[o < 6.0, I', B_2]) → Z_2Polygon(Z_2, Q_2, P_2, U_2) → poly5, z_3, q_3, p_3, u_6Polygon(U_2, T_2, V_2, W_2) → poly6, u_7, t_4, v_5, w_3Polygon(U_2, P_2, O_2, T_2) → poly7, u_8, p_4, o_2, t_5Polygon(O_2, N_2, M_2, T_2) → poly8, o_1, n_5, m_5, t_6Polygon(N_2, L_2, K_2, M_2) → poly9, n_6, l_4, k_4, m_6Polygon(O_2, R_2, S_2, P_2) → poly10, o_3, r_3, s_4, p_5Intersect(k, v_5) → B_3Segment(G, B_3) → b_3Intersect(v_5, a_2) → A_3Segment(P_2, A_3) → e_3Intersect(t_4, p_5) → C_3Intersect(m_5, p_5) → D_3Segment(D_3, C_3) → f_3Segment(D_3, P_2) → h_3Point(Circle[E_3, s]) → F_3Segment(E_3, F_3) → j_3Line(E_3, F_3) → a_4Circle(F_3, e) → h_4Intersect(h_4, a_4, 2.0) → G_3Rotate(G_3, 30.0*°, F_3) → H_3Segment(F_3, H_3) → b_4Line(H_3, j_3) → q_4Line(E_3, b_4) → r_4Intersect(q_4, r_4) → I_3OrthogonalLine(H_3, q_4) → a_5OrthogonalLine(F_3, j_3) → b_5OrthogonalLine(E_3, a_4) → c_5OrthogonalLine(I_3, q_4) → d_5Circle(E_3, s) → e_5Intersect(e_5, c_5, 2.0) → J_3OrthogonalLine(J_3, c_5) → f_5Circle(I_3, s) → g_5Intersect(g_5, d_5, 2.0) → K_3OrthogonalLine(K_3, d_5) → h_5Intersect(a_5, h_5) → L_3Intersect(b_5, f_5) → M_3Polygon(J_3, M_3, L_3, K_3) → poly17, j_5, m_7, l_5, k_5Polygon(J_3, E_3, F_3, M_3) → poly18, j_6, e_6, f_6, m_8Polygon(F_3, M_3, L_3, H_3) → poly19, f_7, m_9, l_6, h_7Polygon(I_3, K_3, L_3, H_3) → poly20, i_5, k_6, l_7, h_8Polygon(E_3, J_3, K_3, I_3) → poly21, e_7, j_7, k_7, i_6Polygon(E_3, I_3, H_3, F_3) → poly22, e_8, i_7, h_9, f_8
AI Drawing Prompt Reference
Draw a cube net and dynamically show its folding process. Start by drawing the six square faces of the cube, then use rotations and translations to demonstrate the net's folding and unfolding. Key objects include six square faces connected by segments and arcs, forming a foldable cube net.
The prompt above was compiled from the original drawing commands and is for reference only.